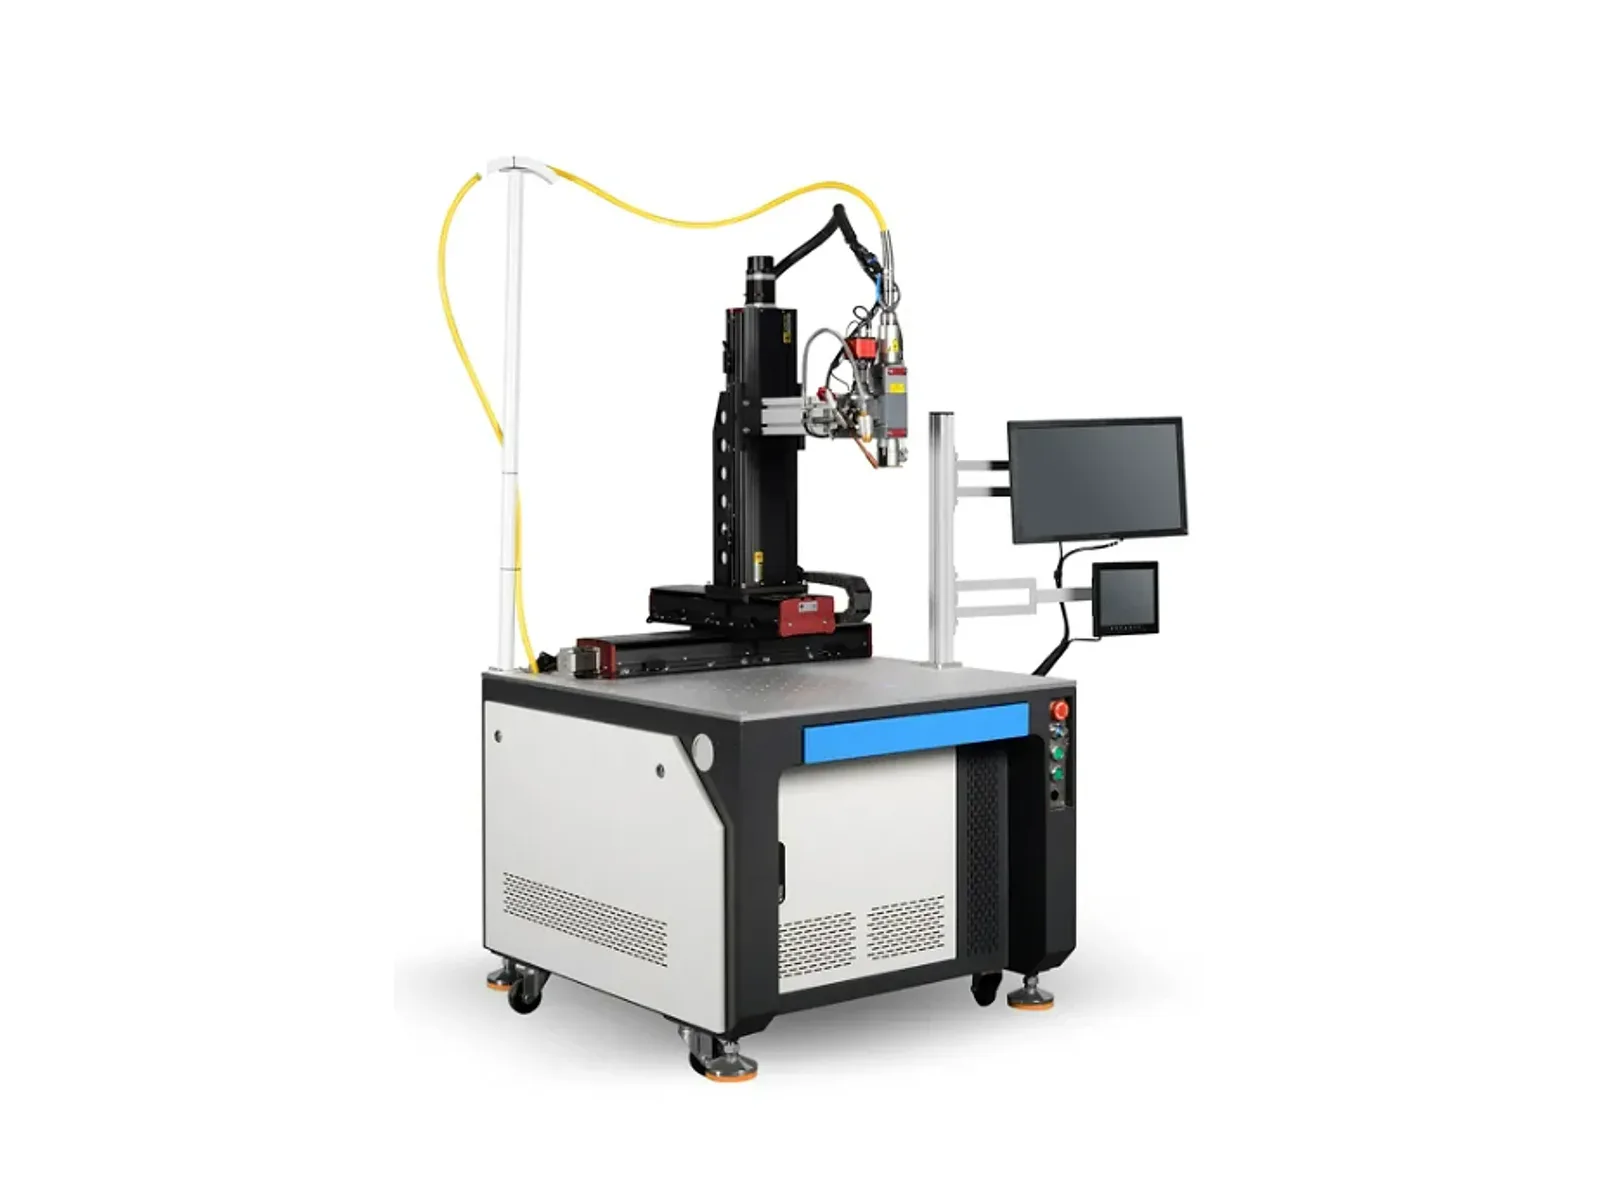
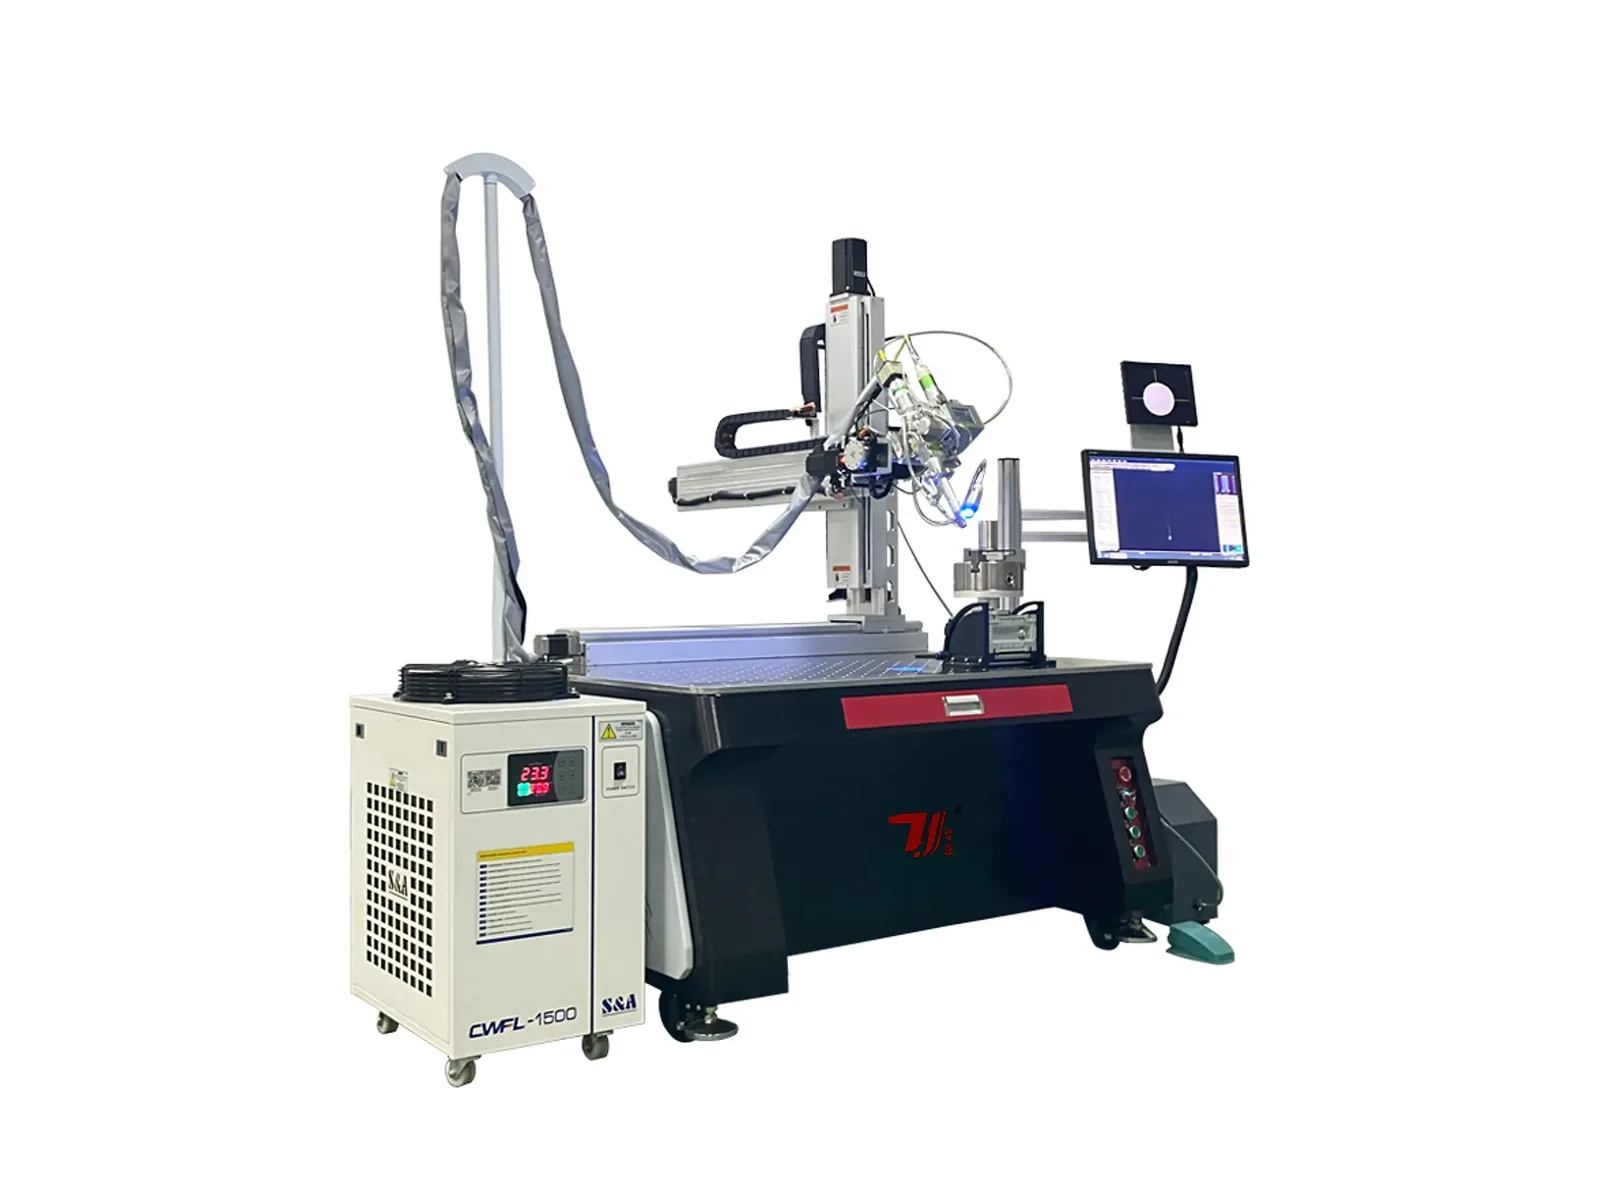
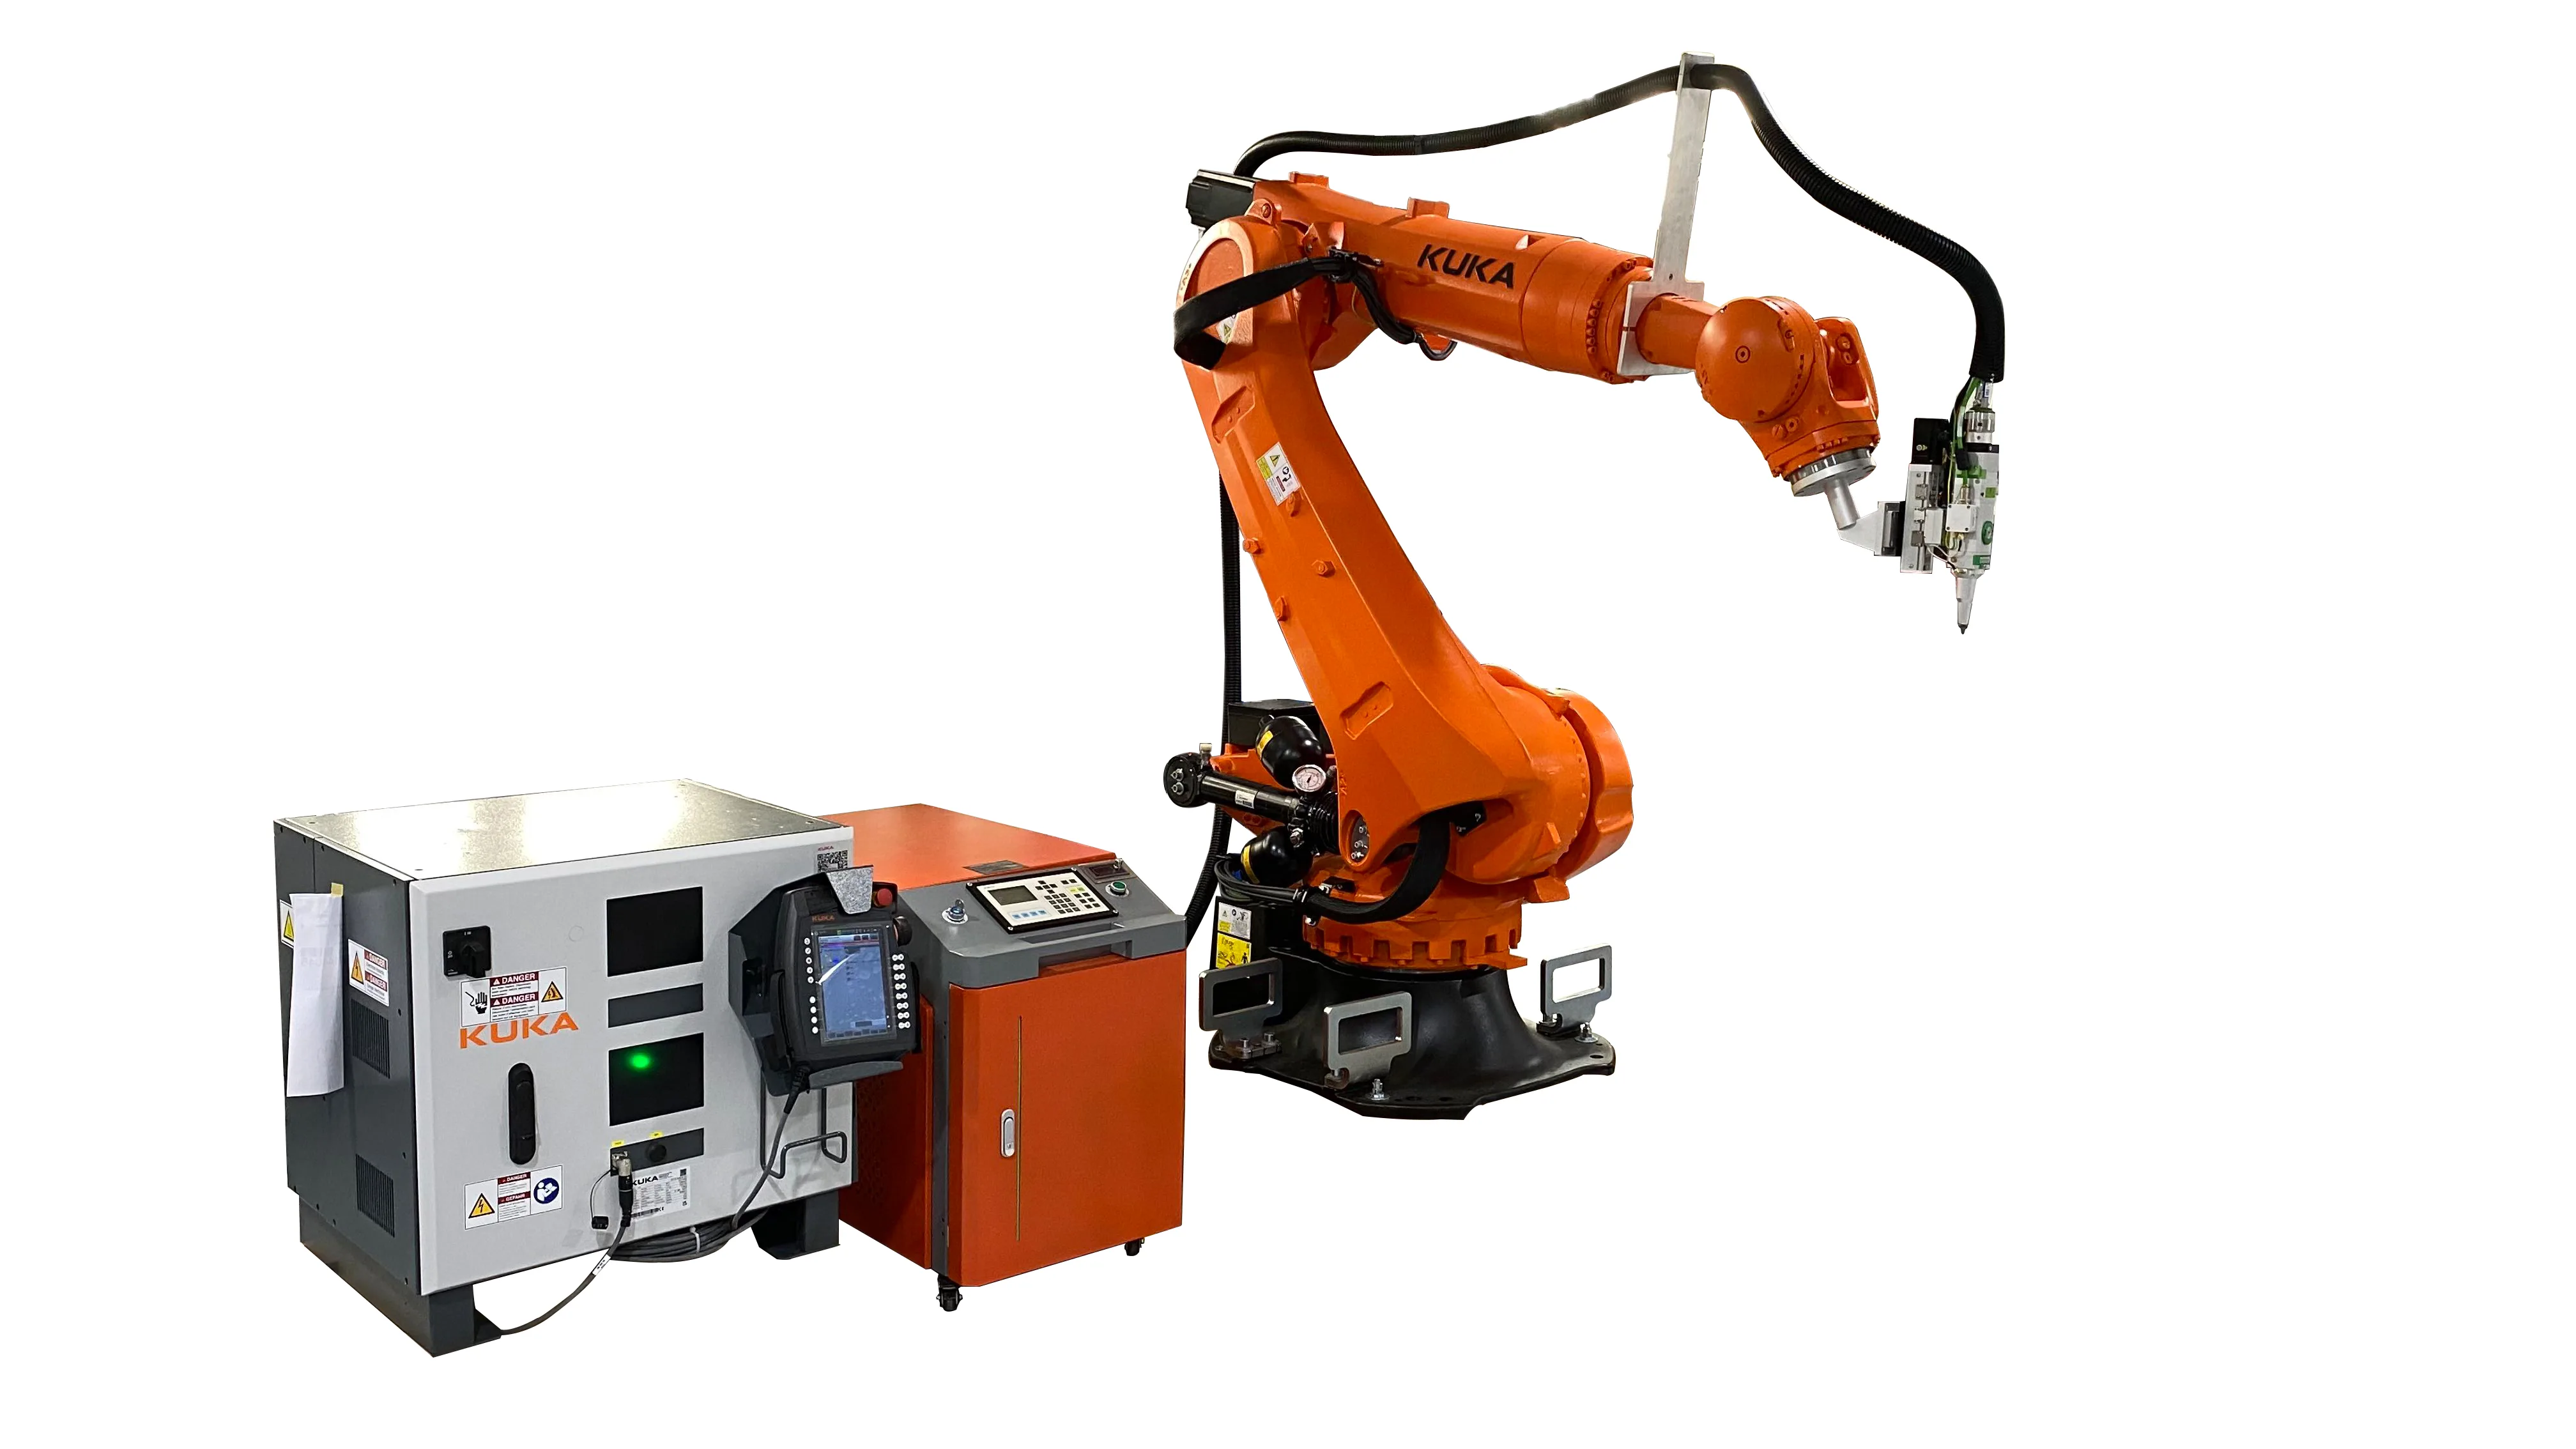
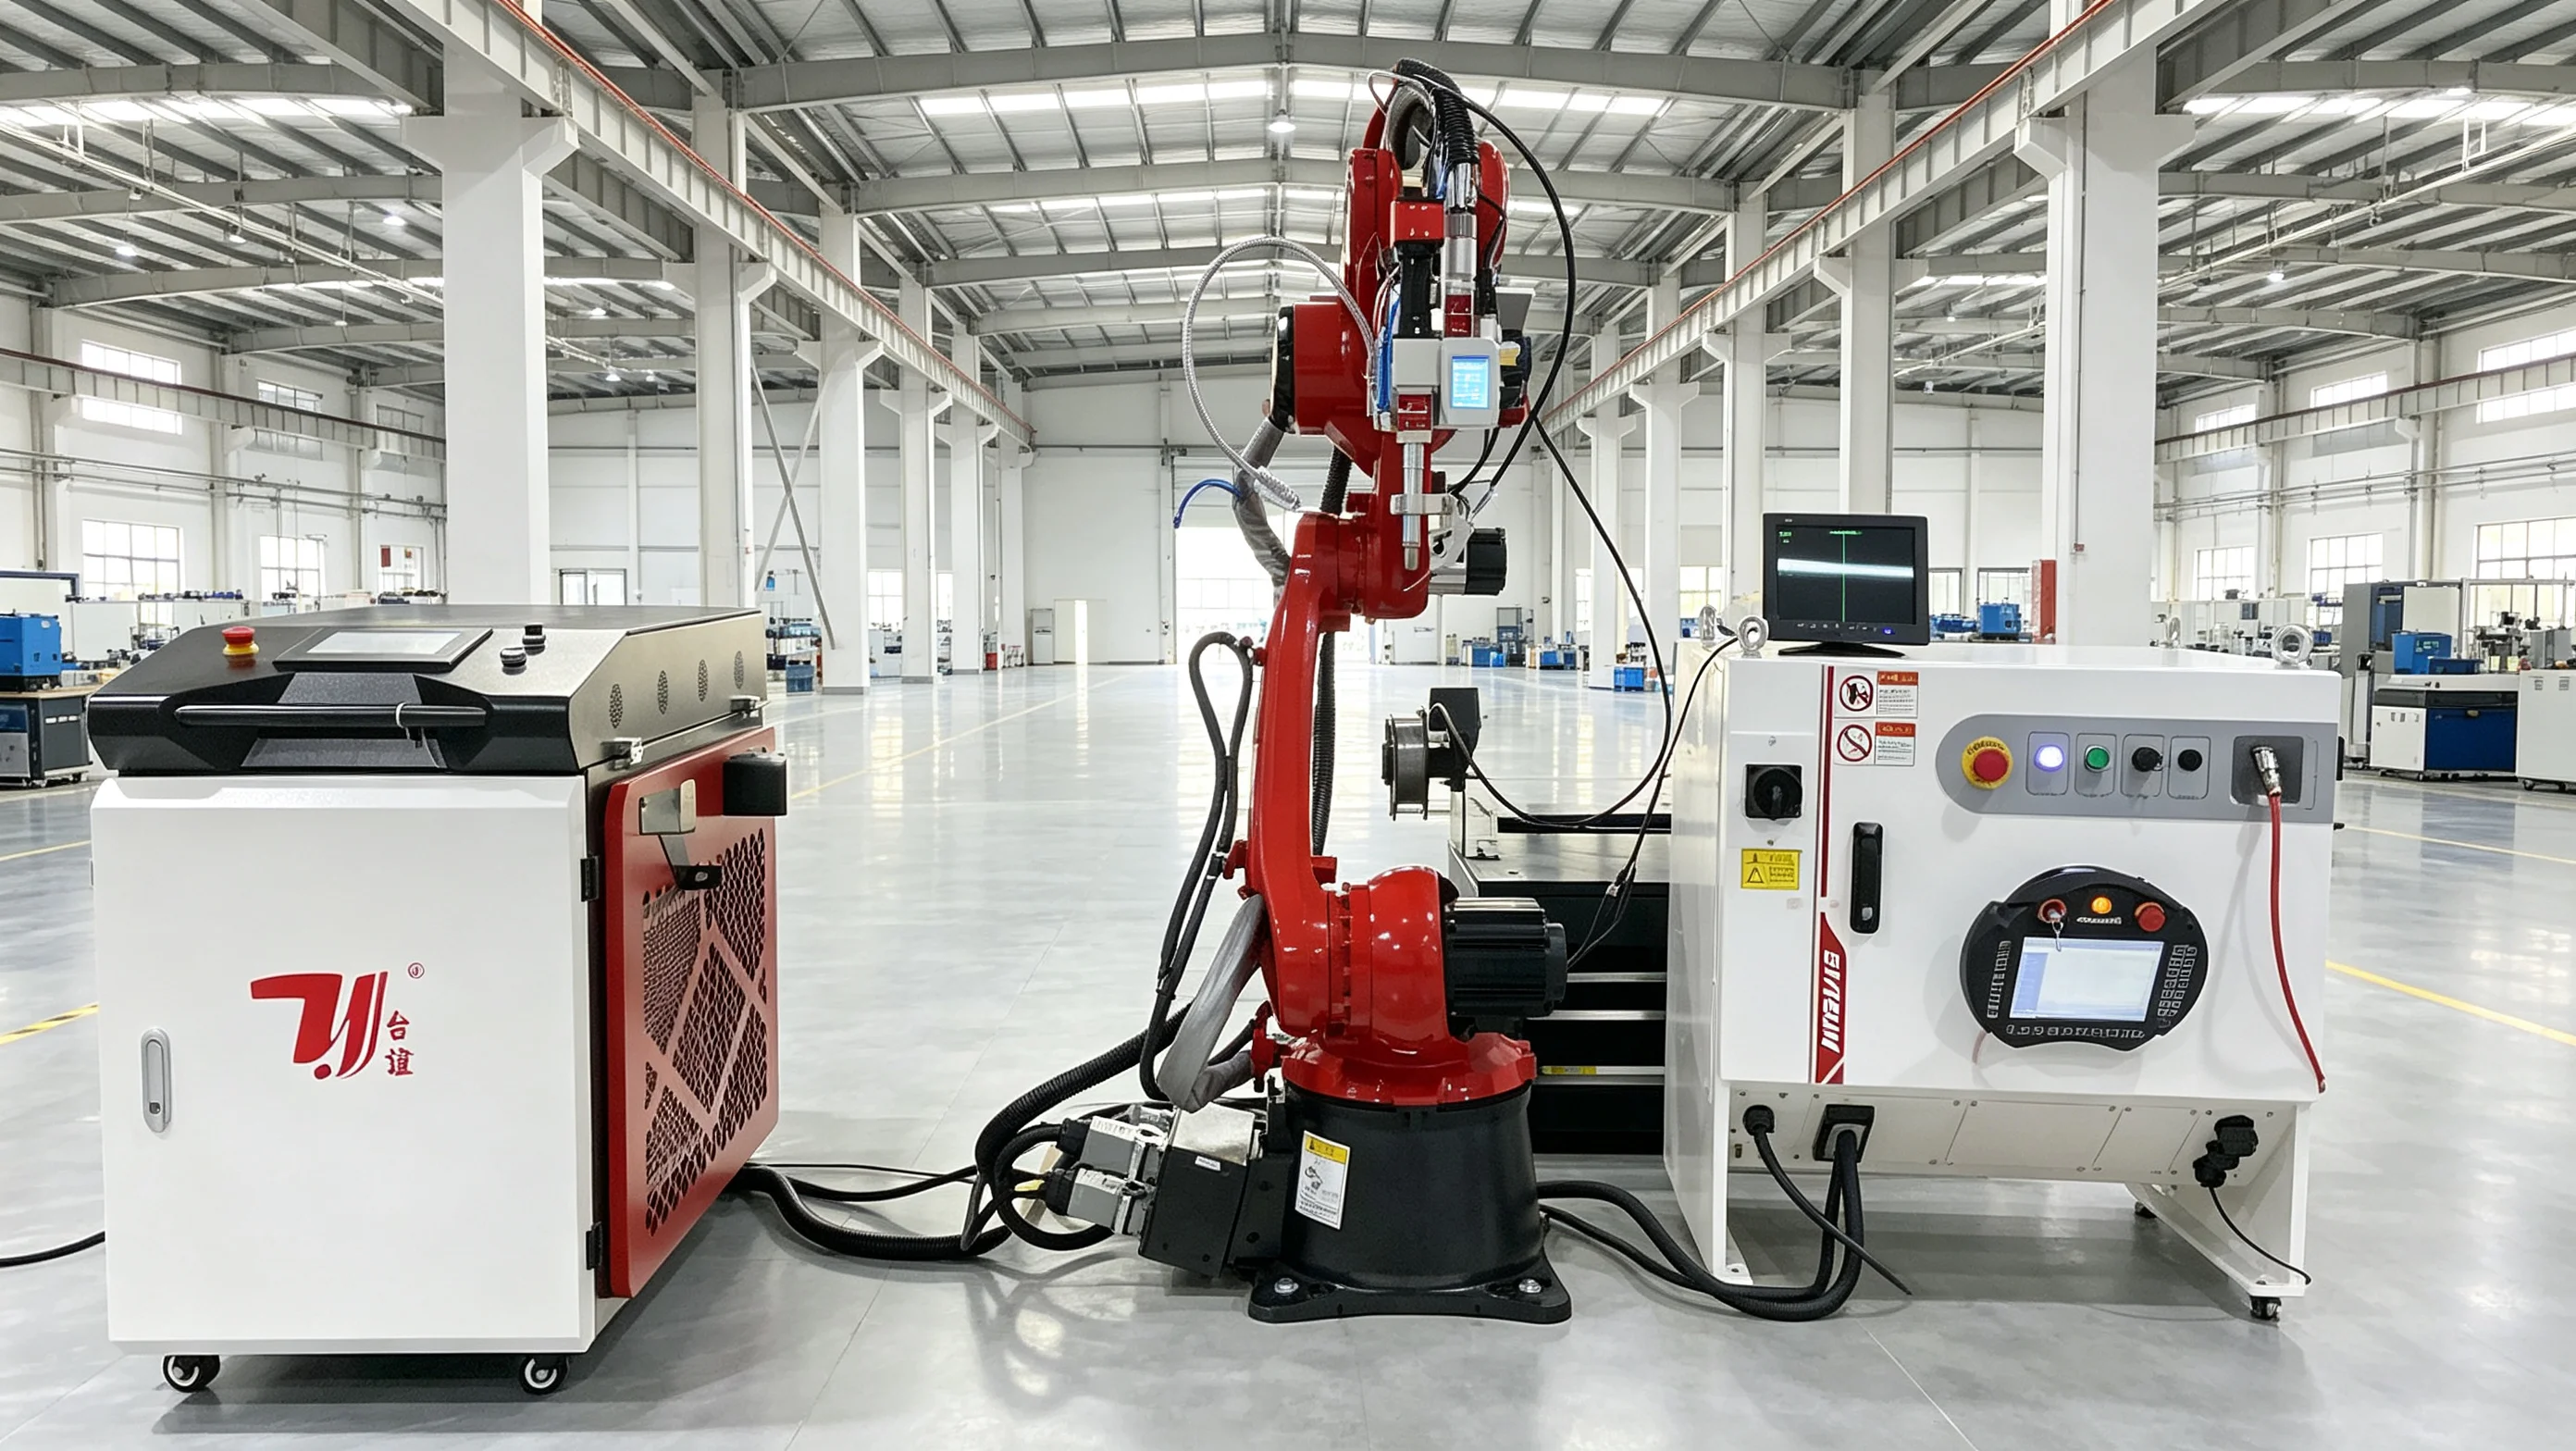
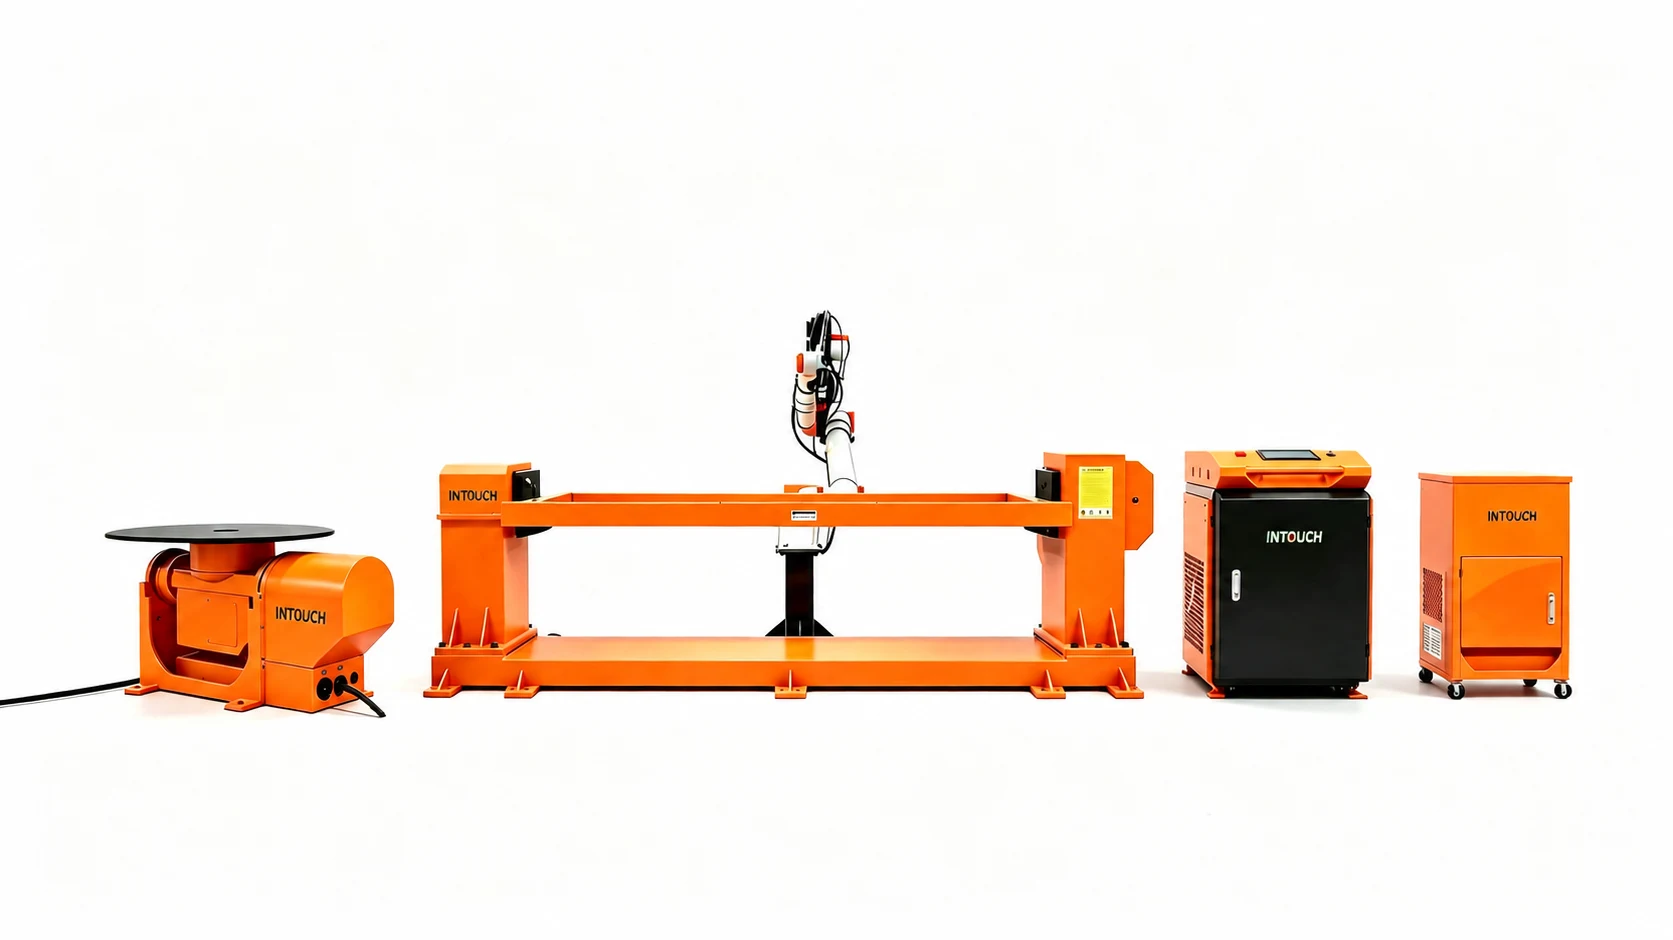
Collaborative robot welding systems
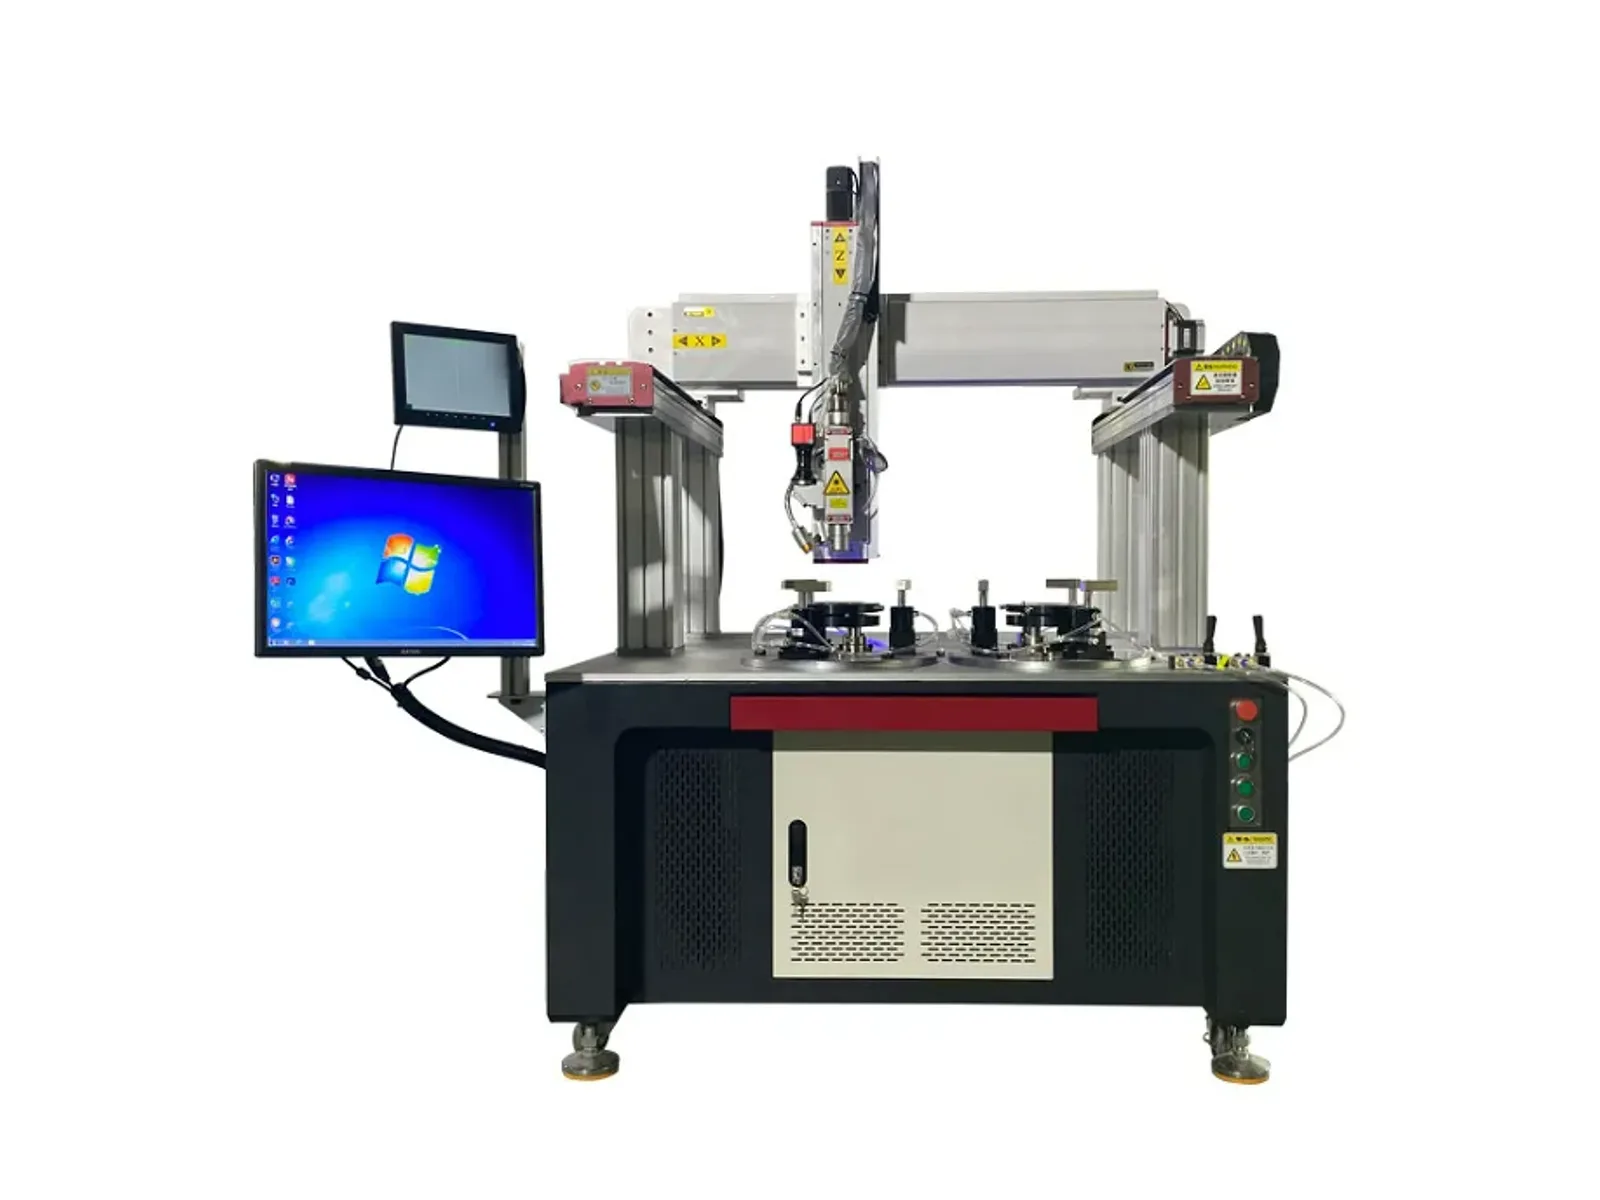
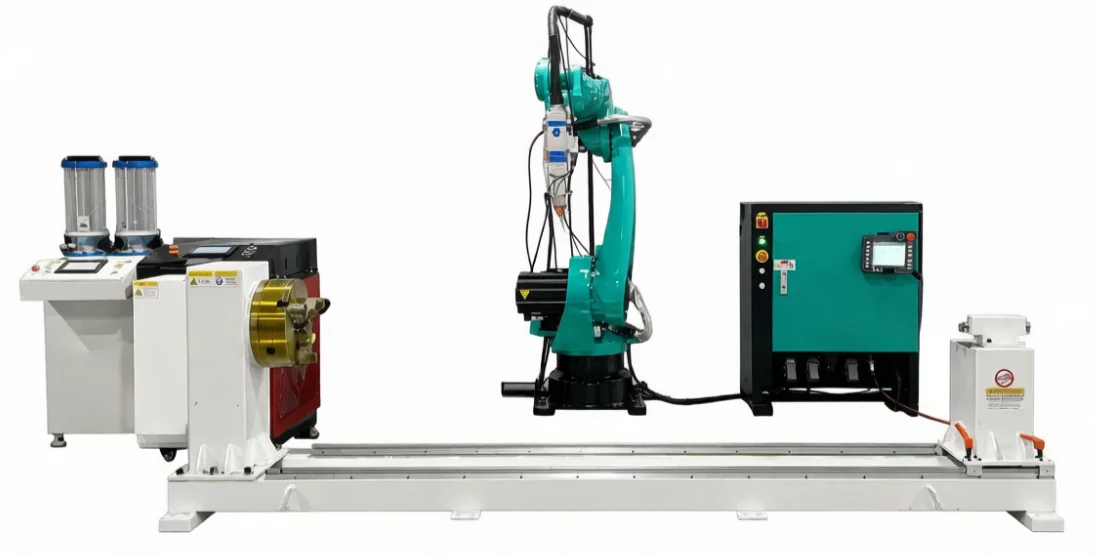
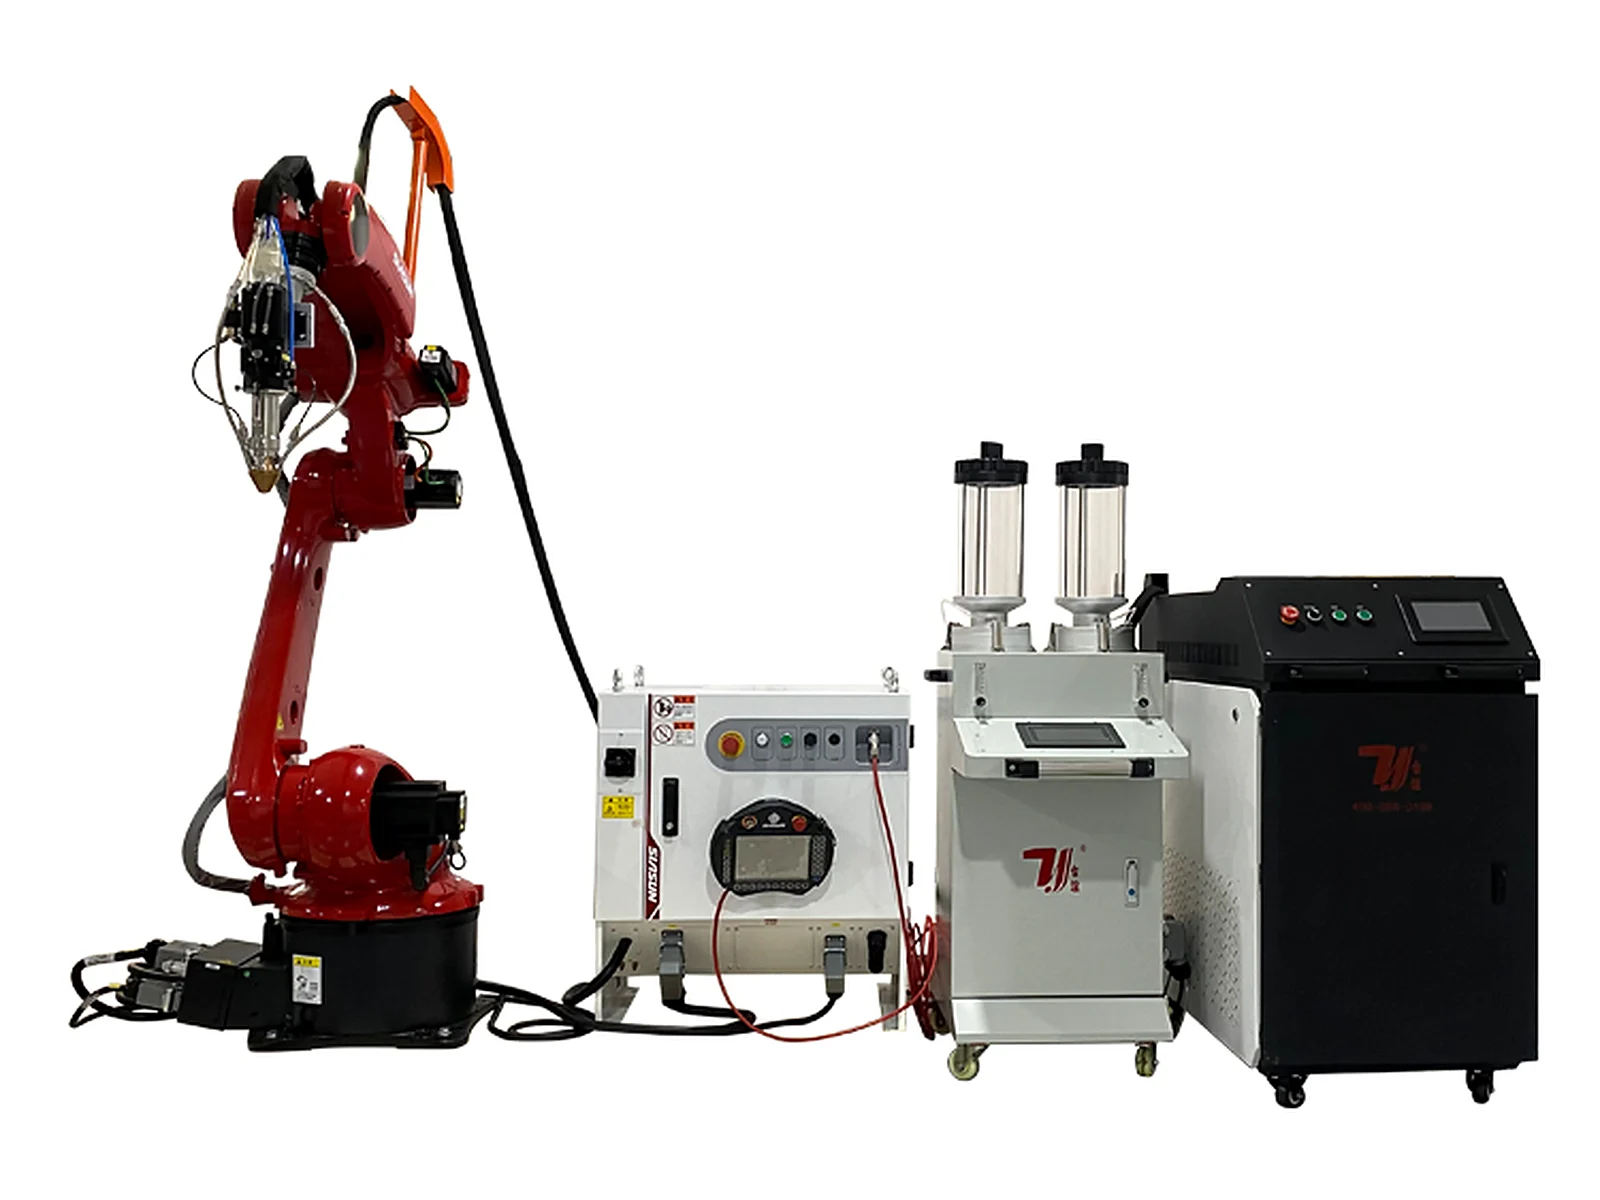
TY-HS5019-3 Collaborative Robot MIG Welding Machine
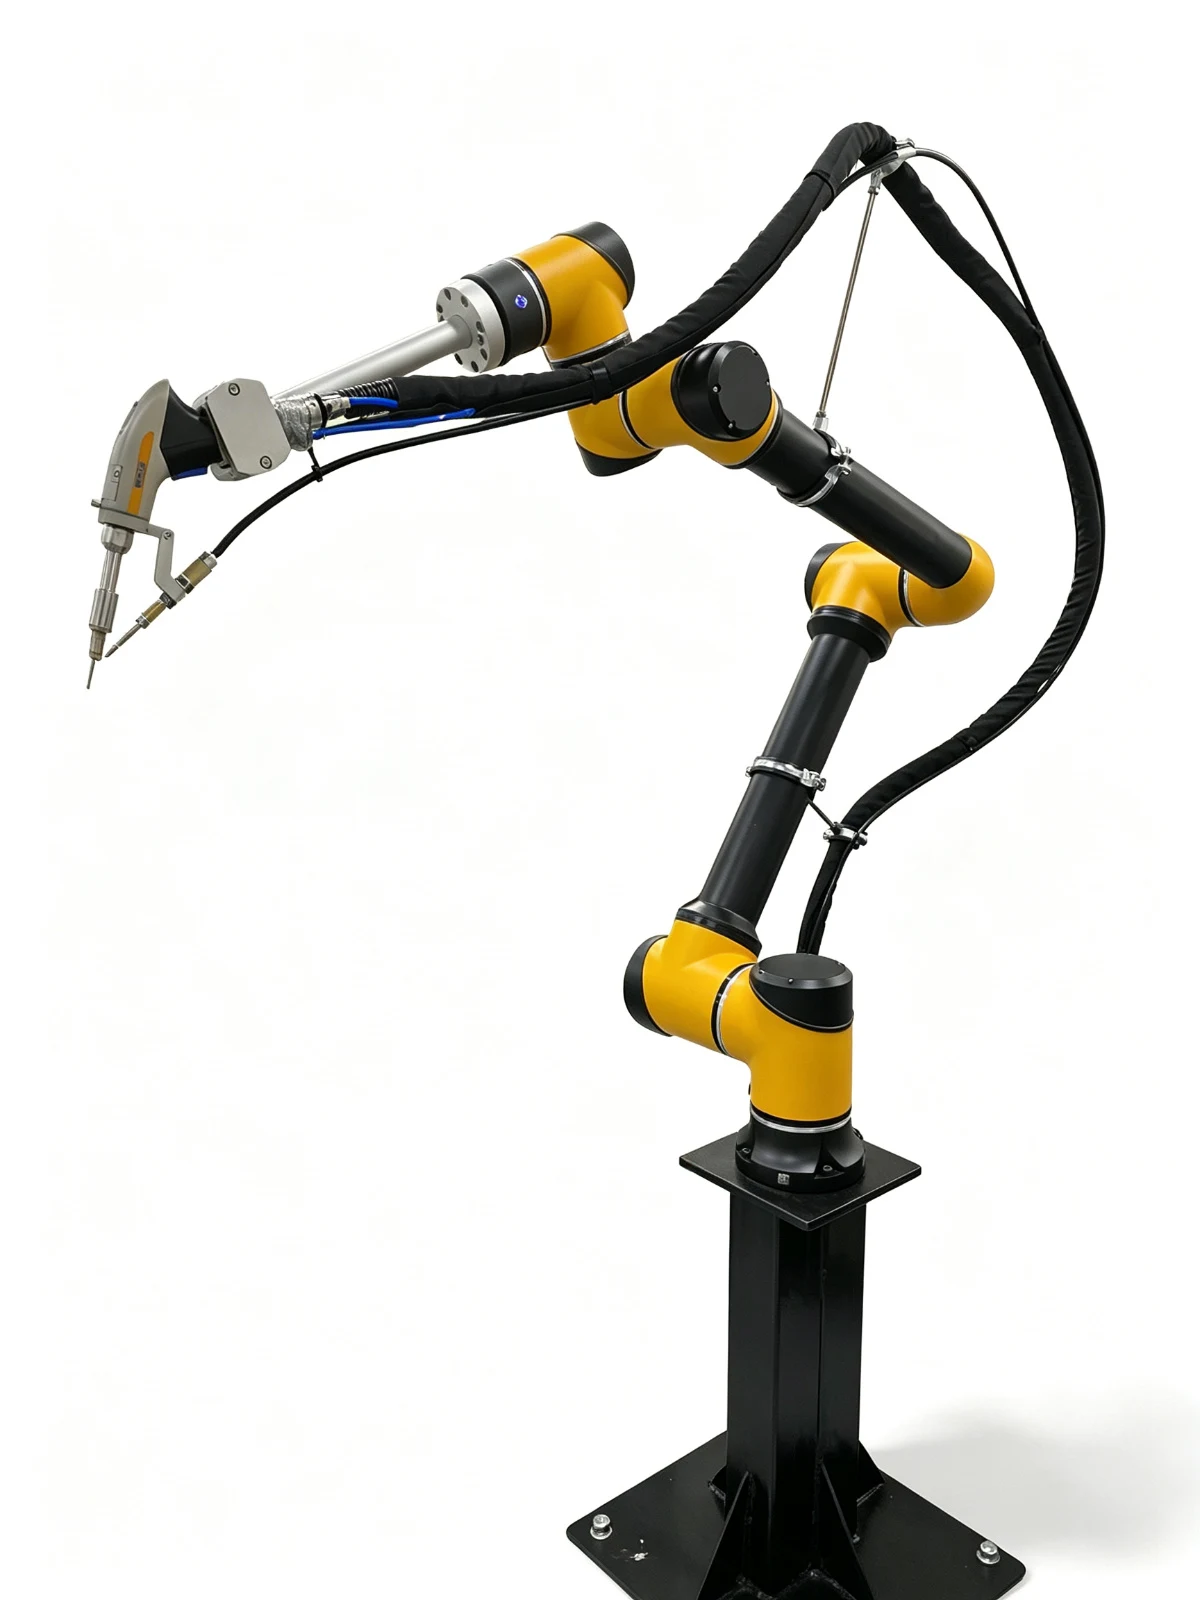
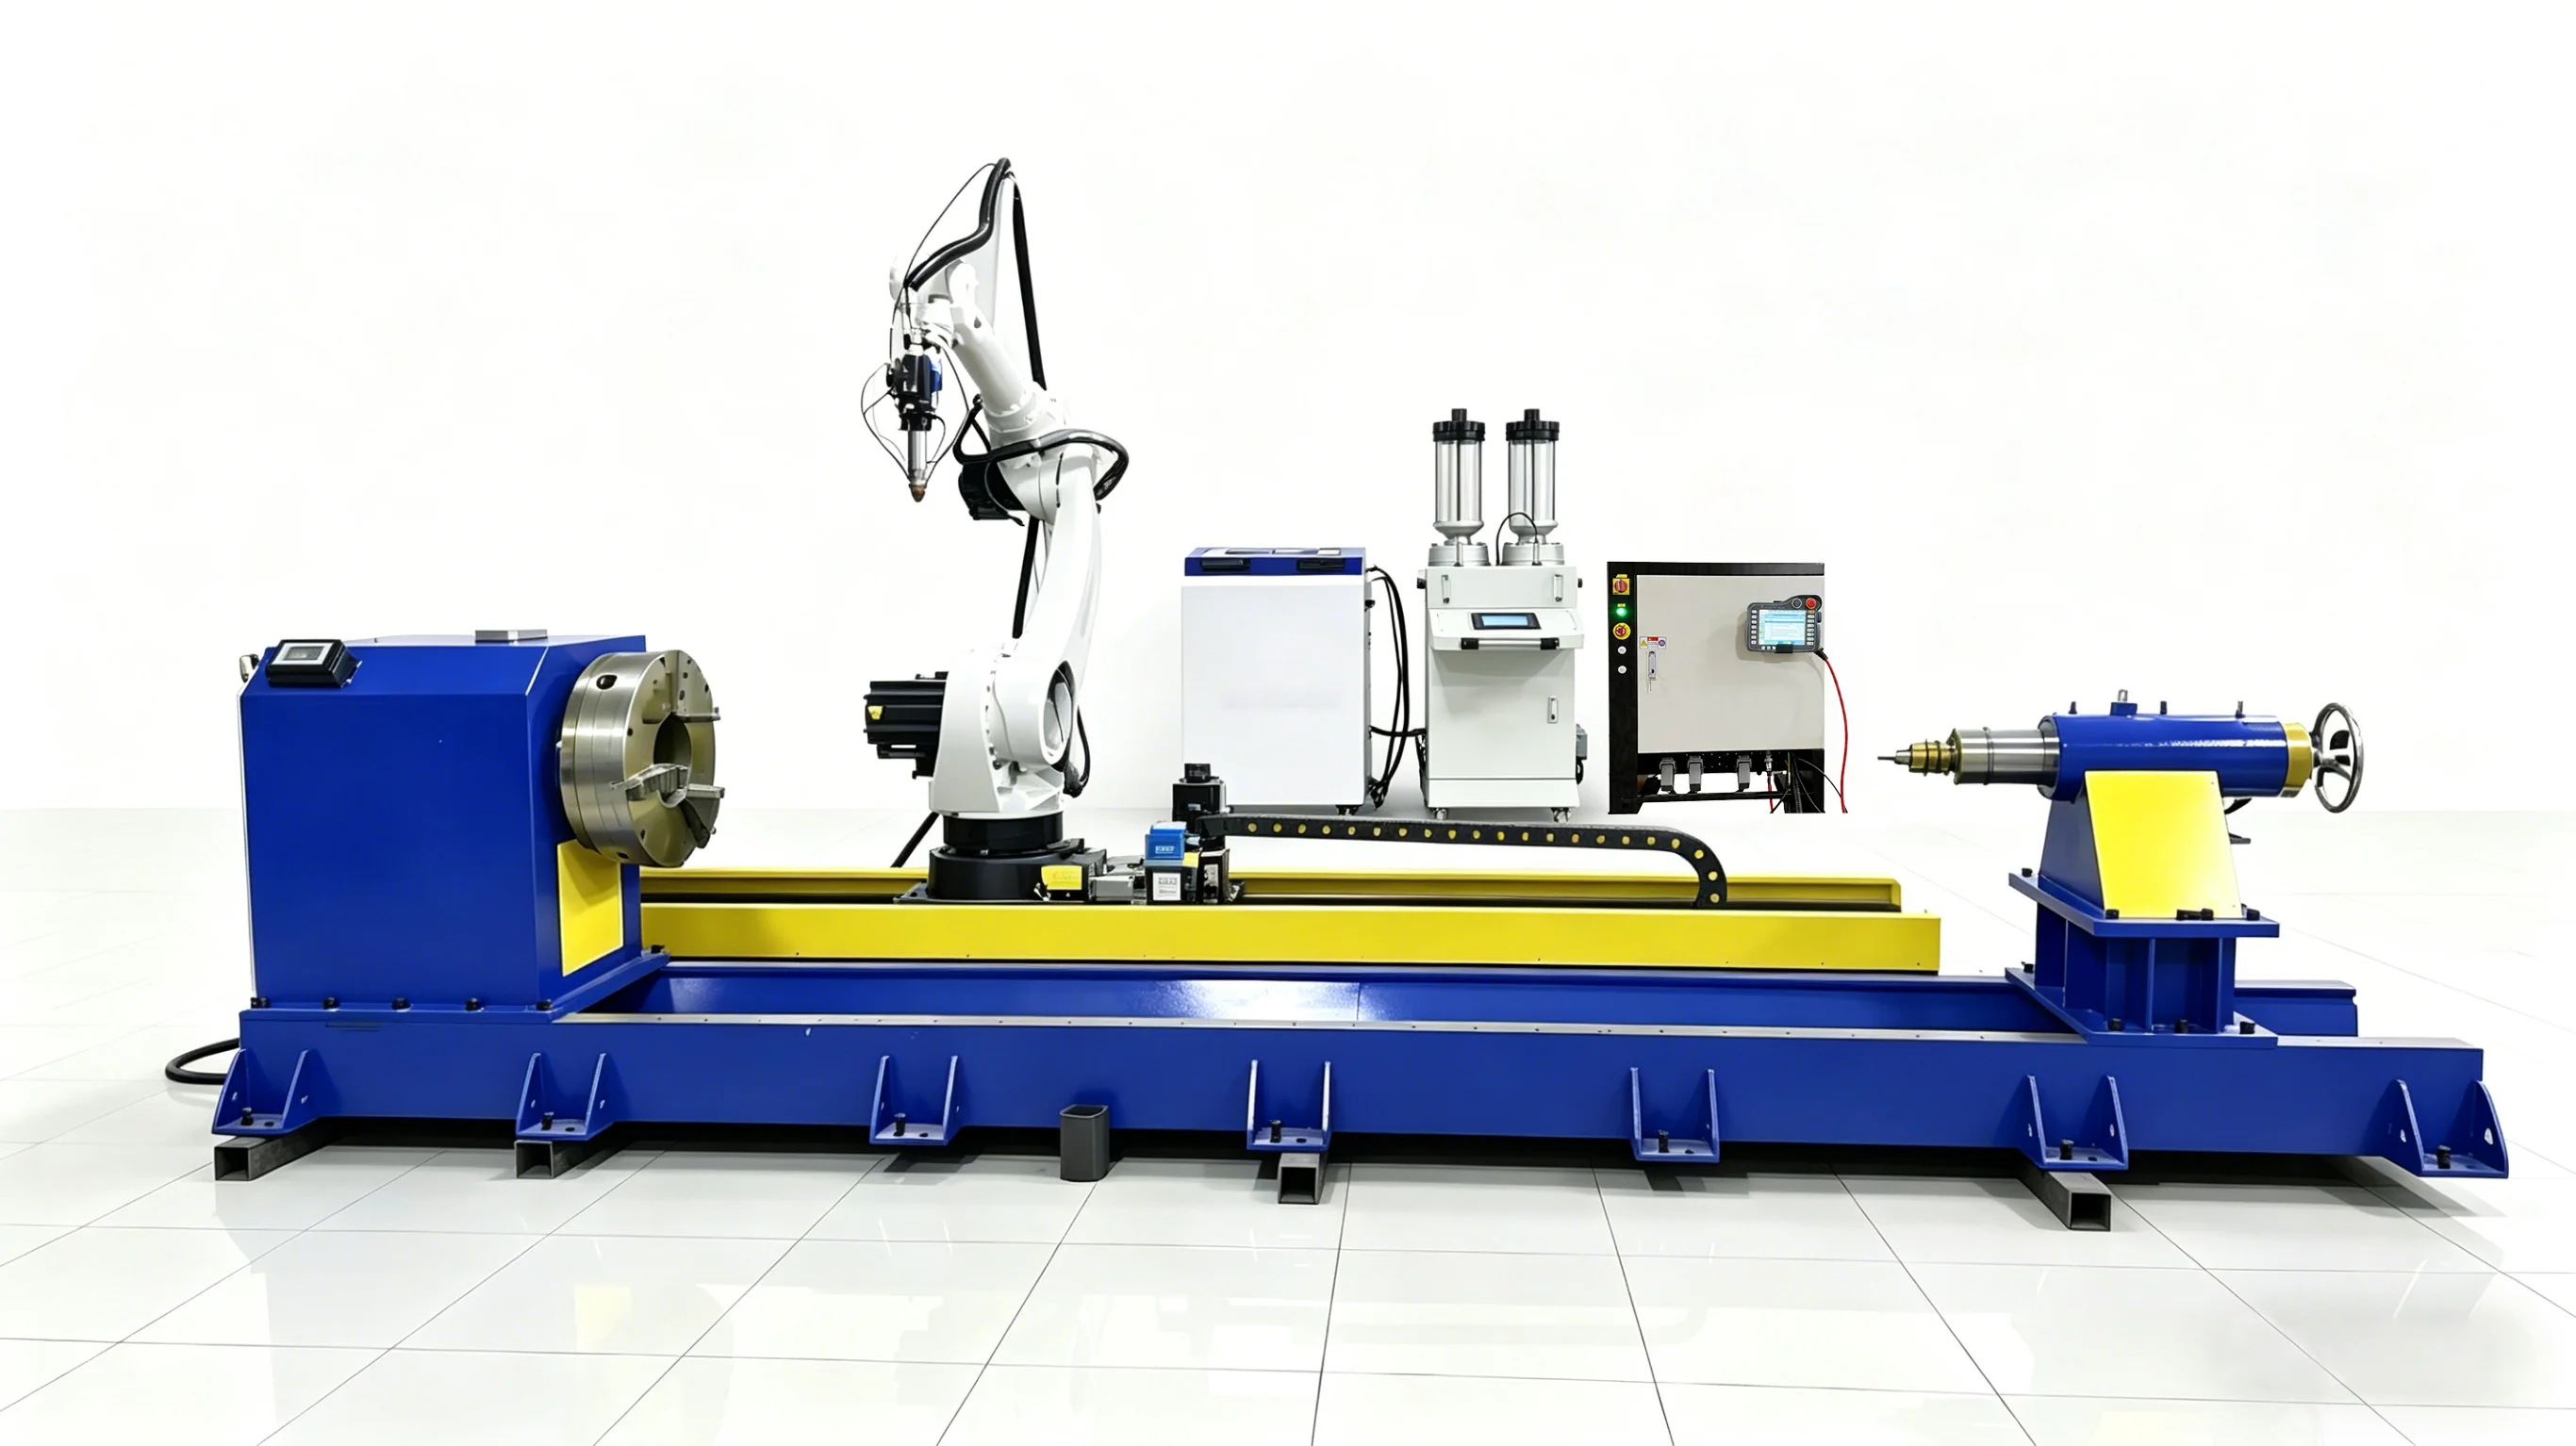
Combine a six-axis collaborative arm, a digital MIG/MAG welding power source and workpiece positioning for structural metal fabrication. Configure the torch, wire, shielding gas and fixture for the material, joint and welding sequence.
The quotation defines the robot, process equipment, fixtures, safeguarding, installation and acceptance scope for your application.
Specifications
TY-HS5019-3 configuration
Machine configuration
- Model
- TY-HS5019-3
- Welding process
- MIG / MAG, pulsed and double-pulsed options
- Power-source options
- 350 A / 500 A digital inverter
- Robot axes
- Six rotational joints with positioner axes as configured
- Robot payload
- 10 kg
- Working radius
- 1,300–1,400 mm
- Robot repeatability
- ±0.05 mm
- Wire diameter
- 0.8–1.6 mm
- Tracking options
- Laser seam tracking / arc tracking / wire sensing
- Power supply
- 380 V, 50/60 Hz
Features
Configure the system around your production task
Arc-welding process
Use MIG/MAG welding for structural joints, with the wire and shielding gas selected for the material.
Workpiece positioning
Rotate or reorient the component to provide torch access and a suitable welding position.
Digital welding setup
Select and tune welding parameters around the wire, material and joint preparation.
Optional seam tracking
Specify laser or arc tracking where incoming-part variation requires path correction.
Project configuration
From workpiece review to cell integration
- 01
Workpiece and production review
- 02
Robot and process selection
- 03
Fixture and layout planning
- 04
Programming and interface setup
- 05
Safeguarding and access review
- 06
Process trials and acceptance
Application scope
Parts and production applications
Review material, geometry, access and production requirements with the proposed configuration.
Related products
Compare related robot configurations
TY-HS5019-1
Use the detachable laser welding gun by hand or mount it on a six-axis collaborative arm. Repeated seams can follow a taught robot path, while manual operation supports varied parts and touch-up work. Choose the air-cooled or water-cooled laser package for the application.
Collaborative Robot Laser Welding MachineTY-HS5019-2
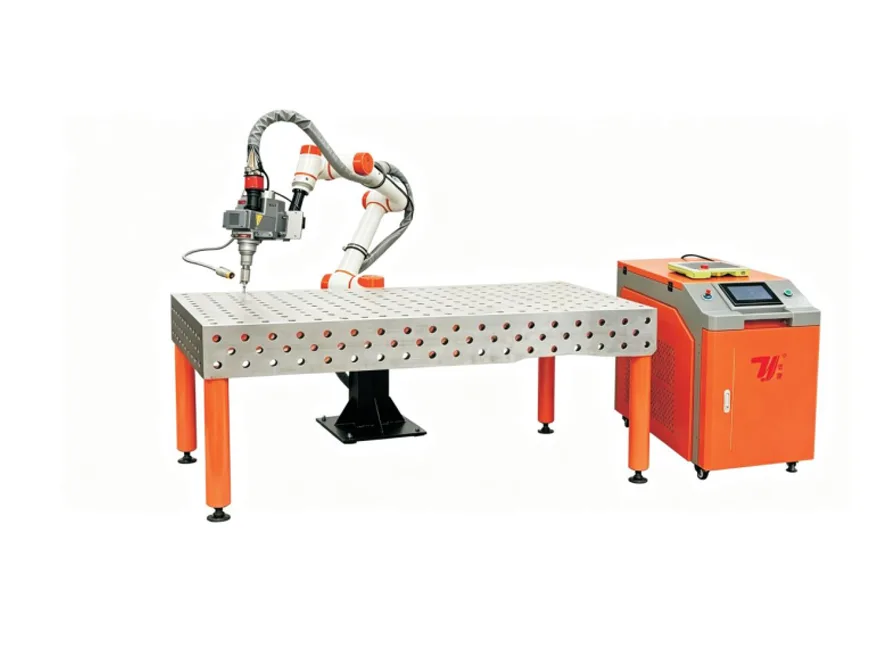
An integrated collaborative-arm laser welding workstation with a precision welding head and flexible workholding. Teach repeatable paths for circular seams, curved joints and visible metal assemblies, with the robot and fixture selected around the part.
Related industry solutions
Explore the applications and laser processes connected to this equipment.
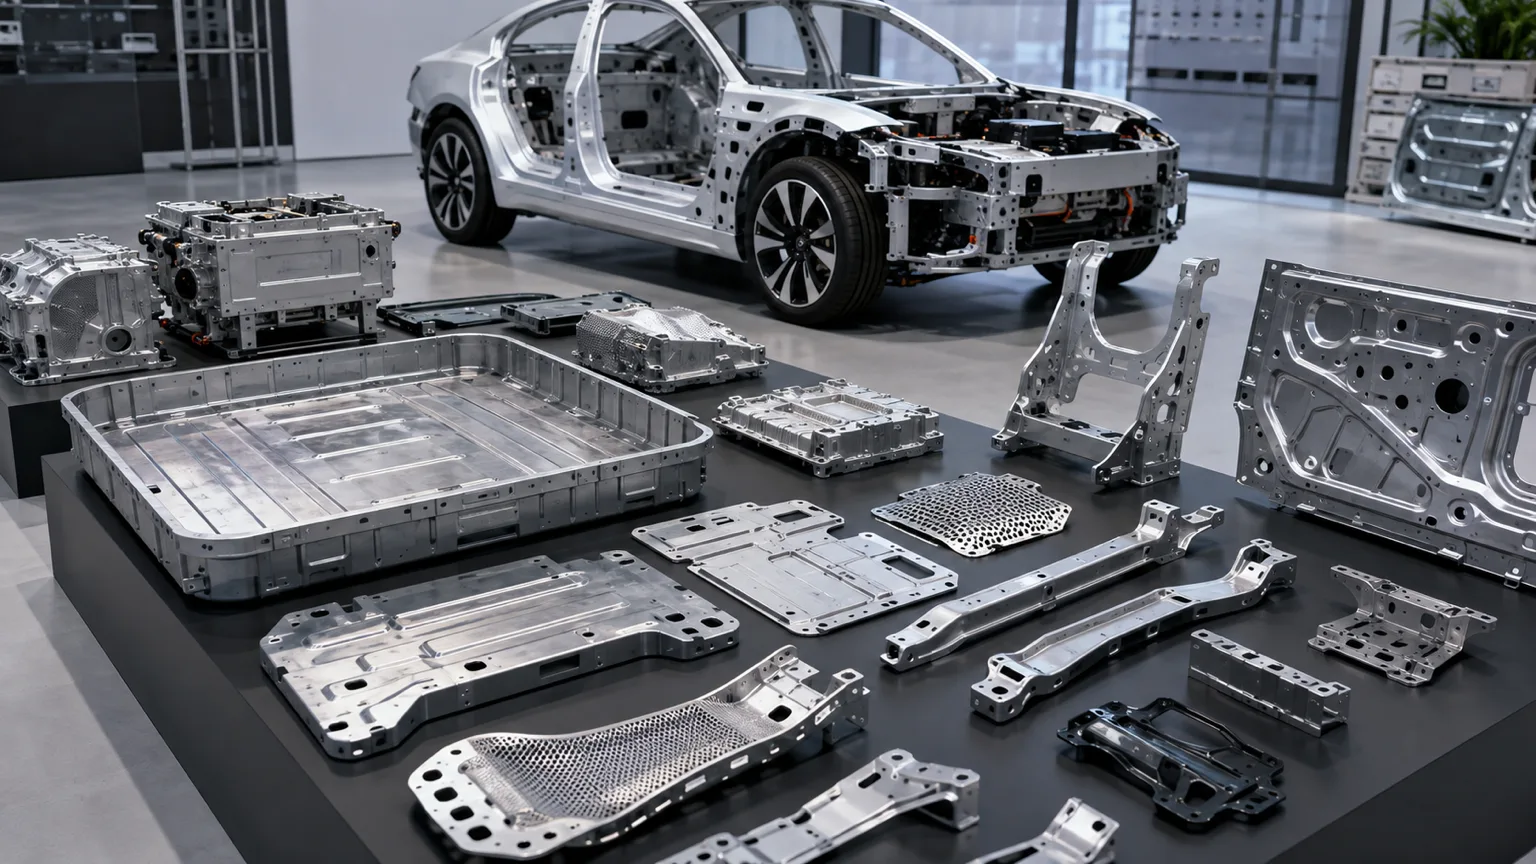
Automotive components
Laser processing for body structures, powertrain parts and battery components.
View solution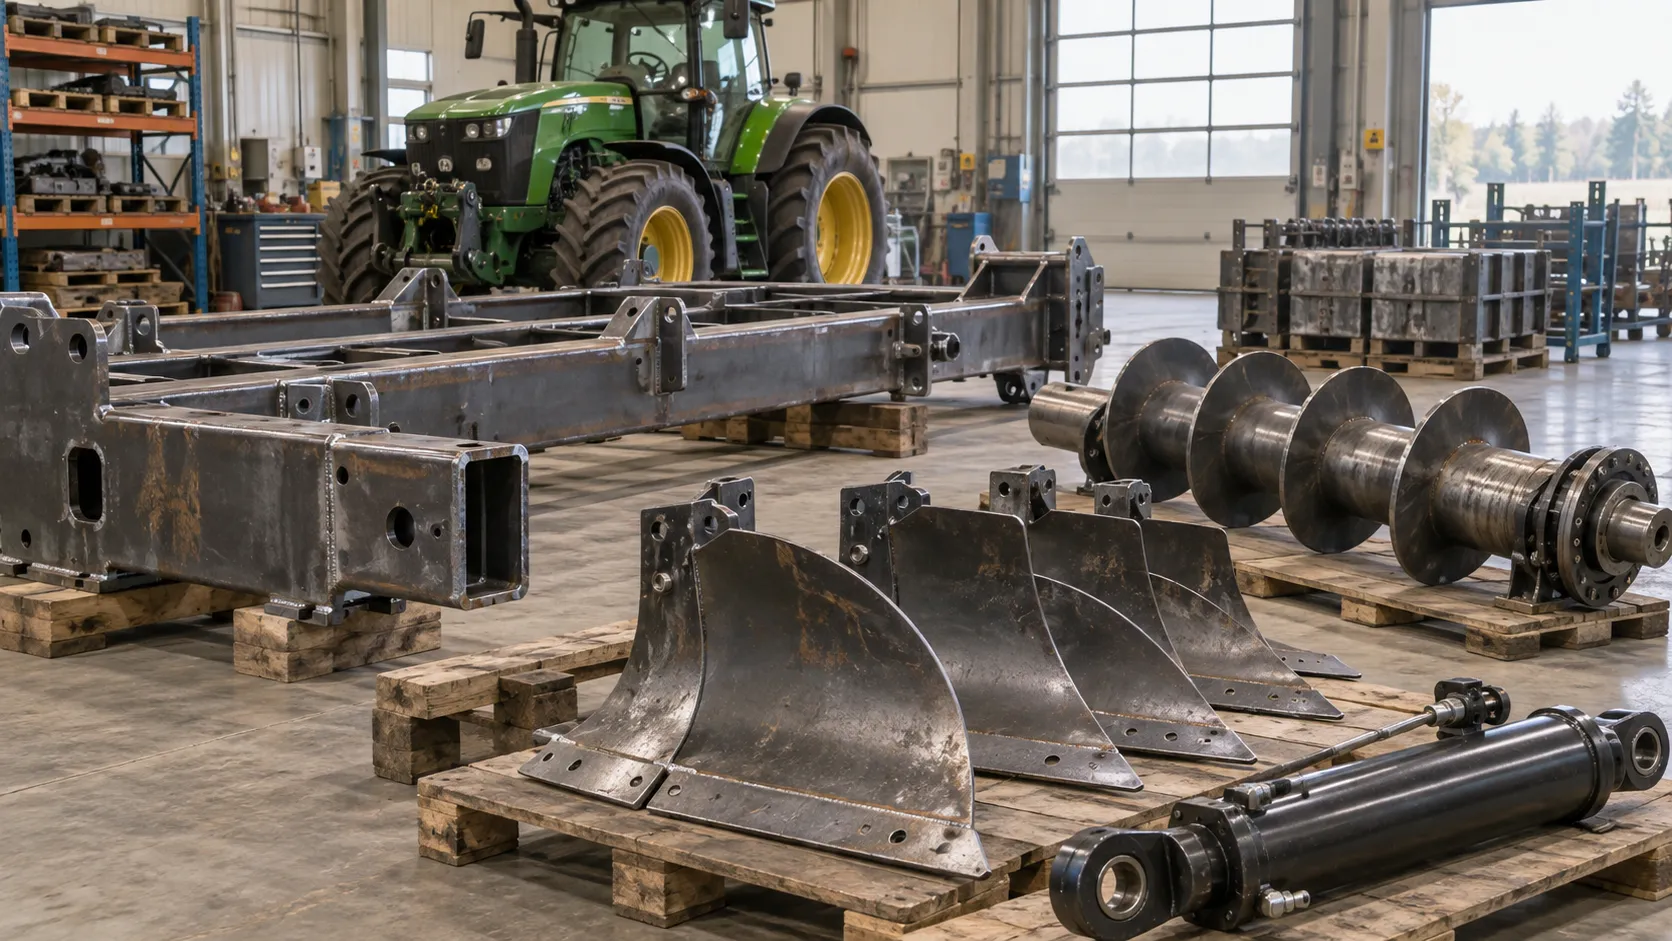
Agricultural machinery
Cutting, welding and surface repair for frames, blades and working components.
View solutionDefine the complete workstation before selecting the robot
Workpiece and tooling
Provide drawings, material, dimensions, mass and the required operations. Include fixture access and the intended loading method so the robot and tooling can be selected together.
Integration and acceptance
Specify production targets, connected equipment and available floor space. Agree the process trial, guarding, interfaces and acceptance criteria for the complete cell.
Machine selection questions
How is the TY-HS5019-3 configured?
Combine a six-axis collaborative arm, a digital MIG/MAG welding power source and workpiece positioning for structural metal fabrication. Configure the torch, wire, shielding gas and fixture for the material, joint and welding sequence.
What information is needed for a quotation?
Send representative part drawings, material and dimensions, required operations, target output and available layout. Include connected equipment and any requested fixture or positioner.
How are guarding and operator access defined?
The complete application determines protective measures. The process, tool, workpiece, fixtures and operator access are considered together when defining guarding and interlocks.
Request a quote
Tell us the part. We will tell you the machine.
Price and delivery depend on the robot, process package, workholding, safeguarding and integration scope.
- Phone+86 153 6281 4831
- Emailsales02@taiyilaser.com
- WhatsApp+86 153 6281 4831