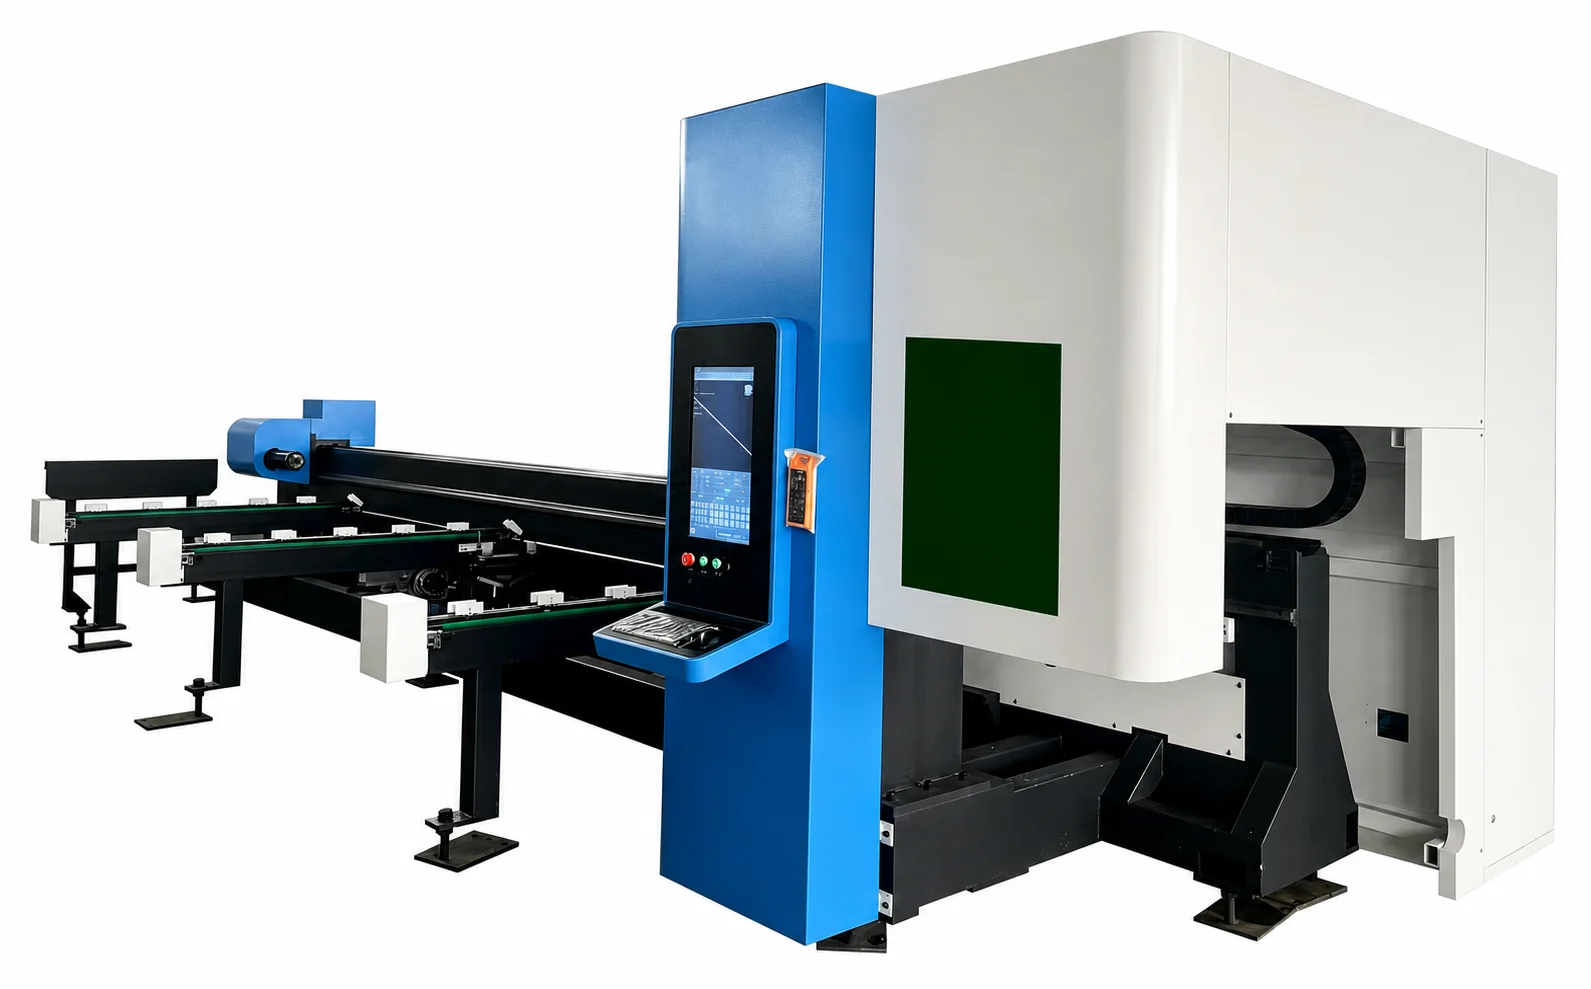
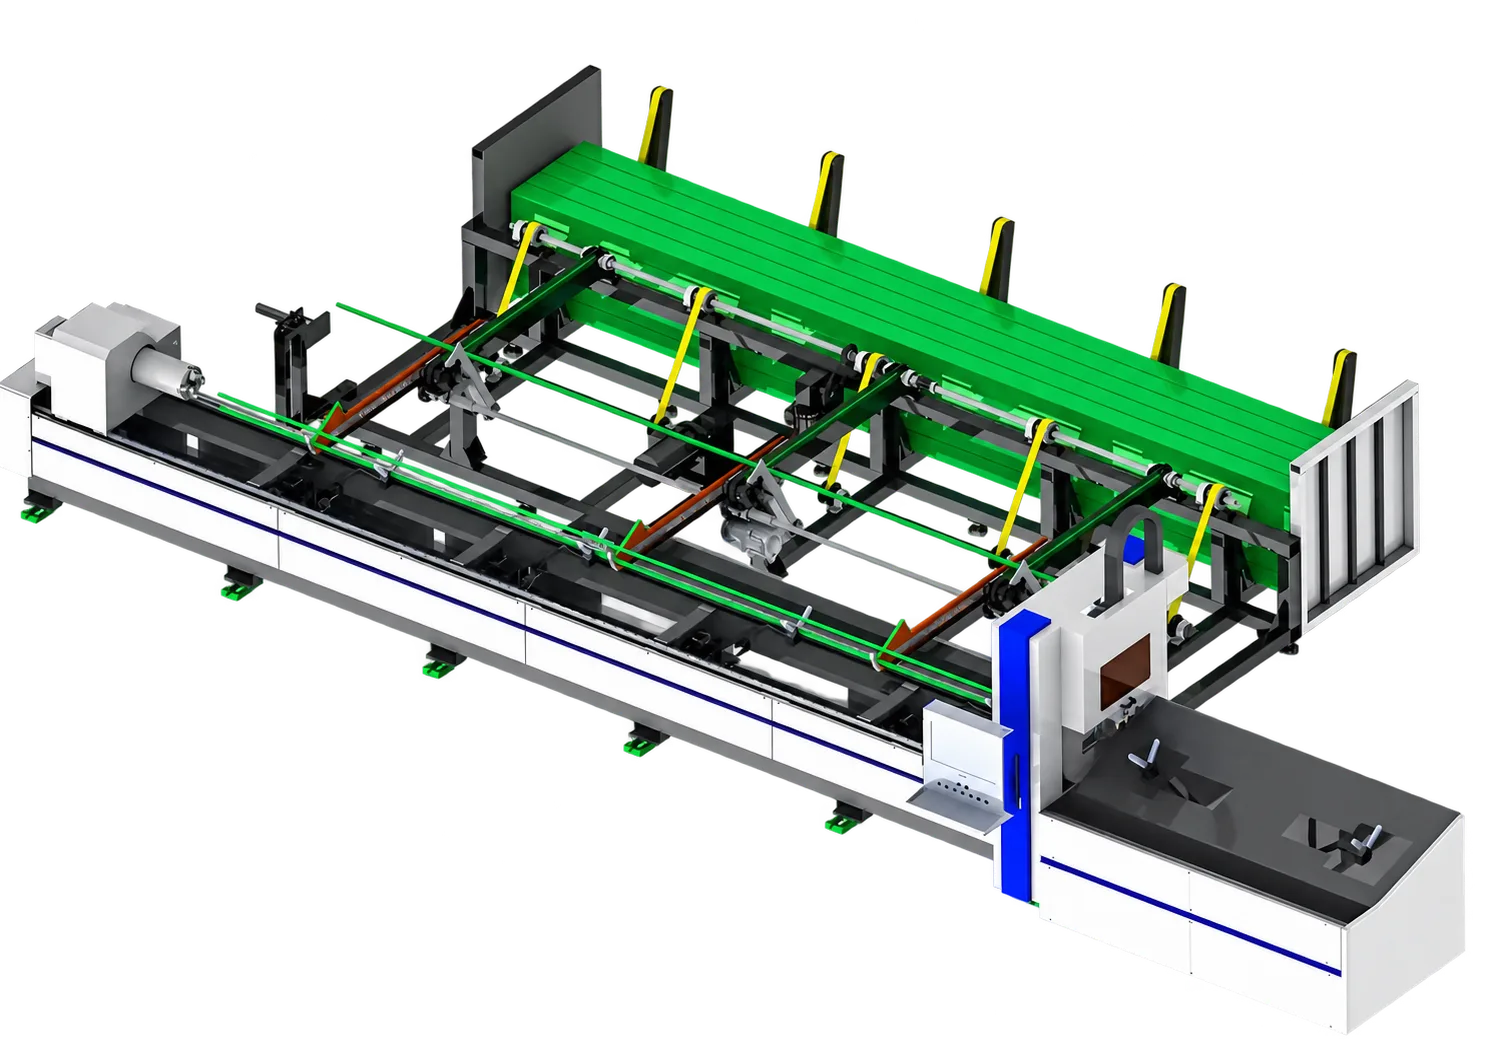
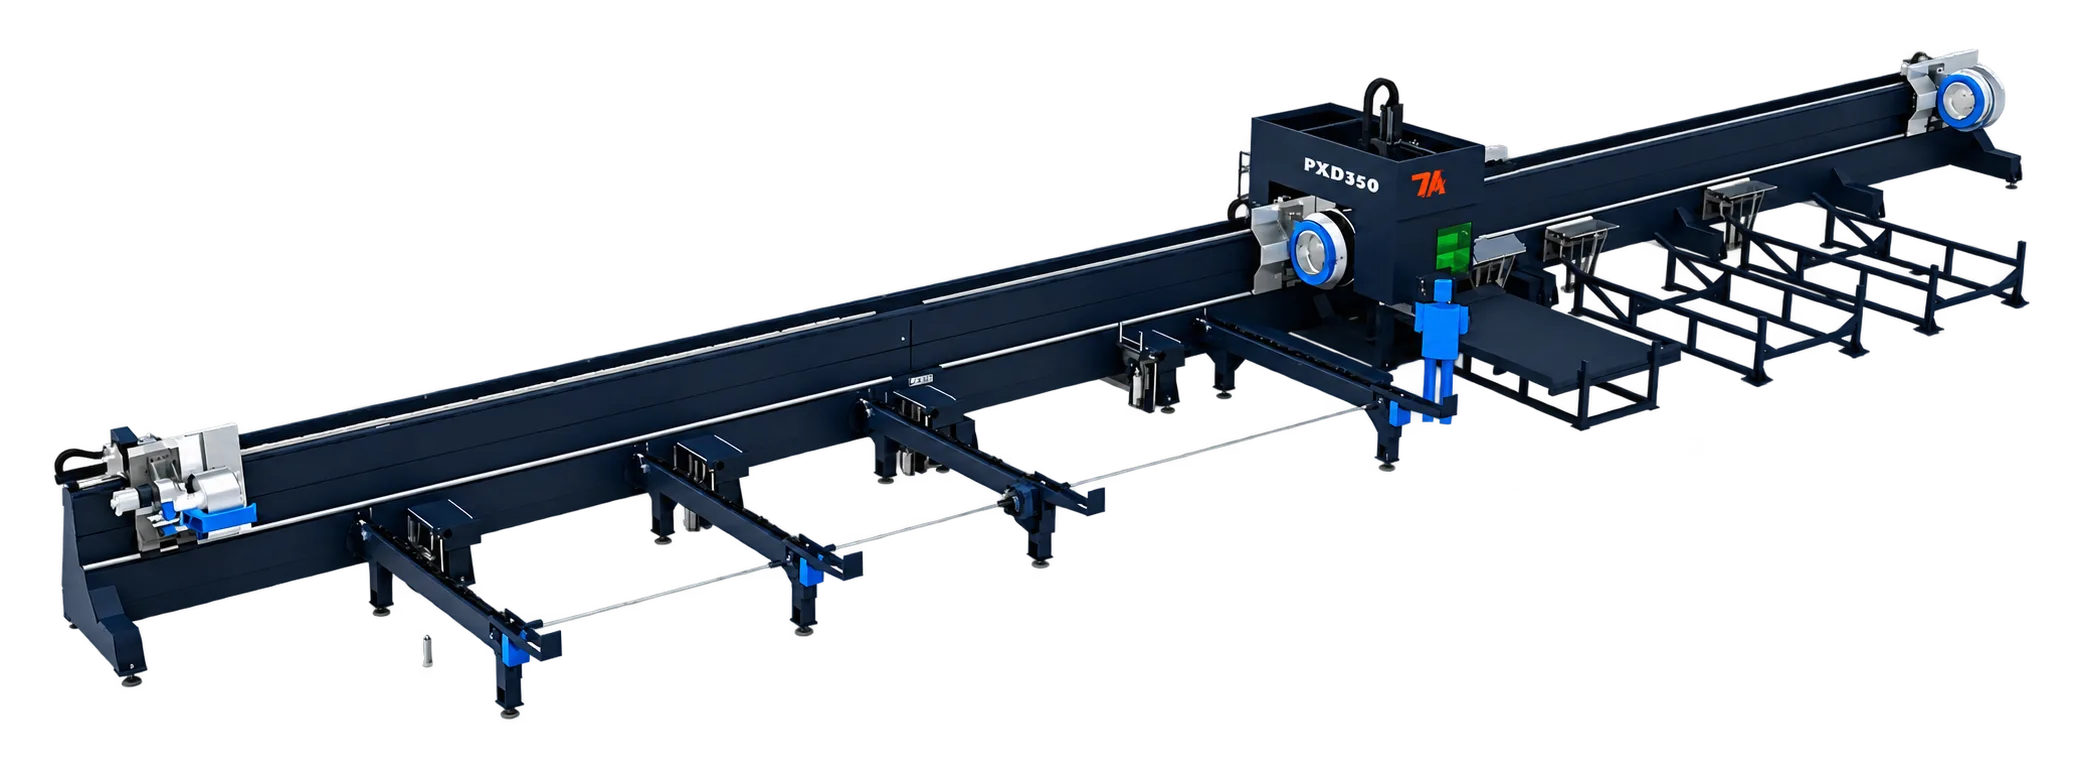
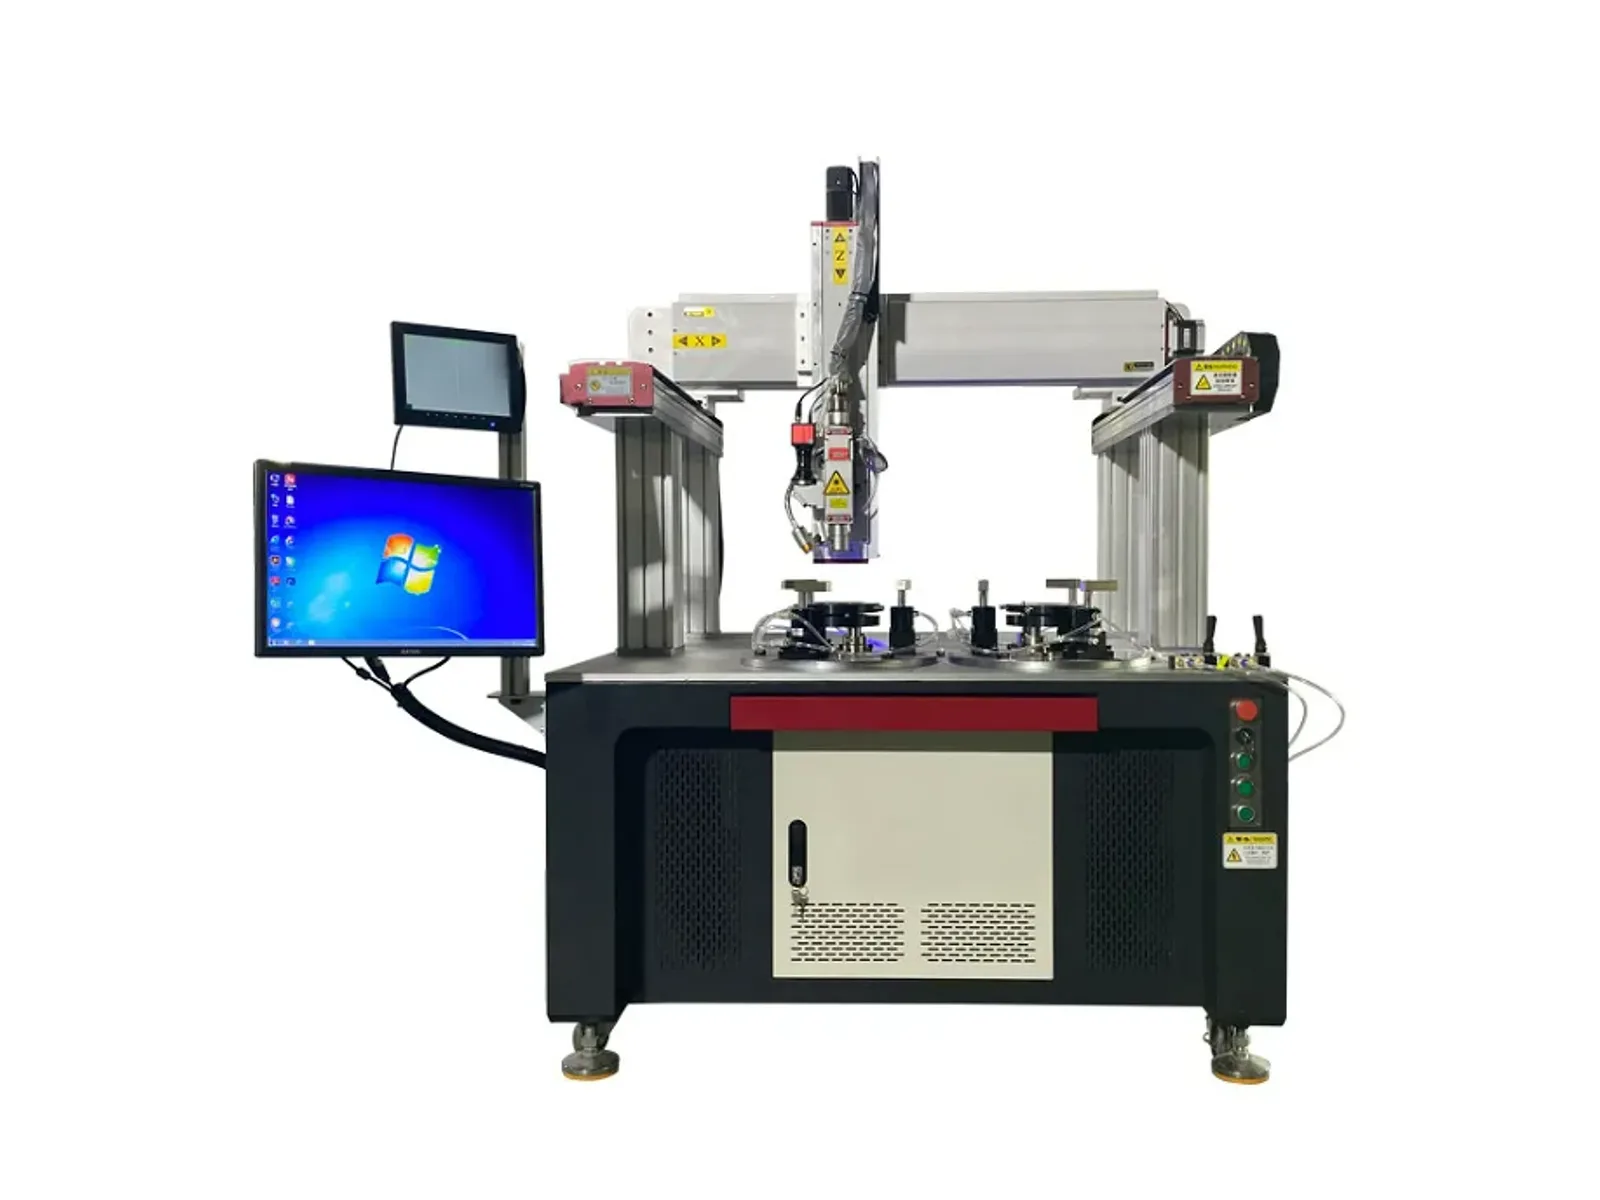
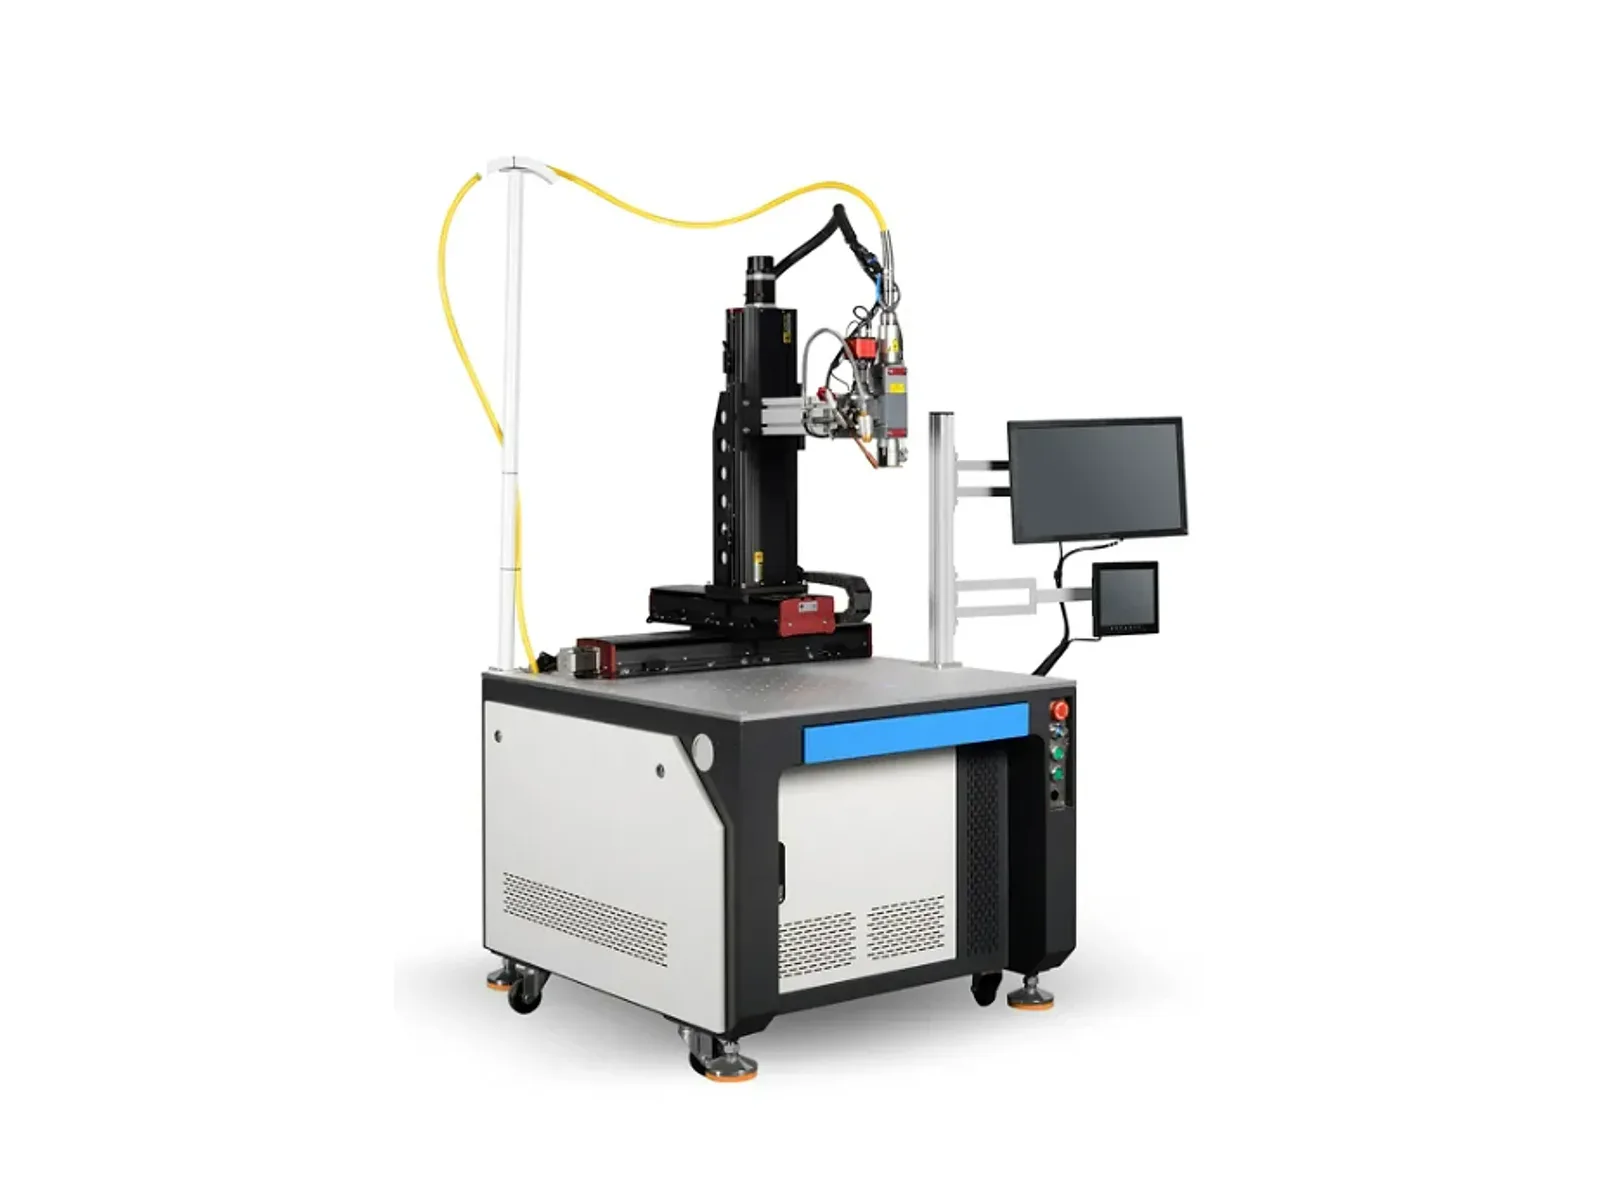
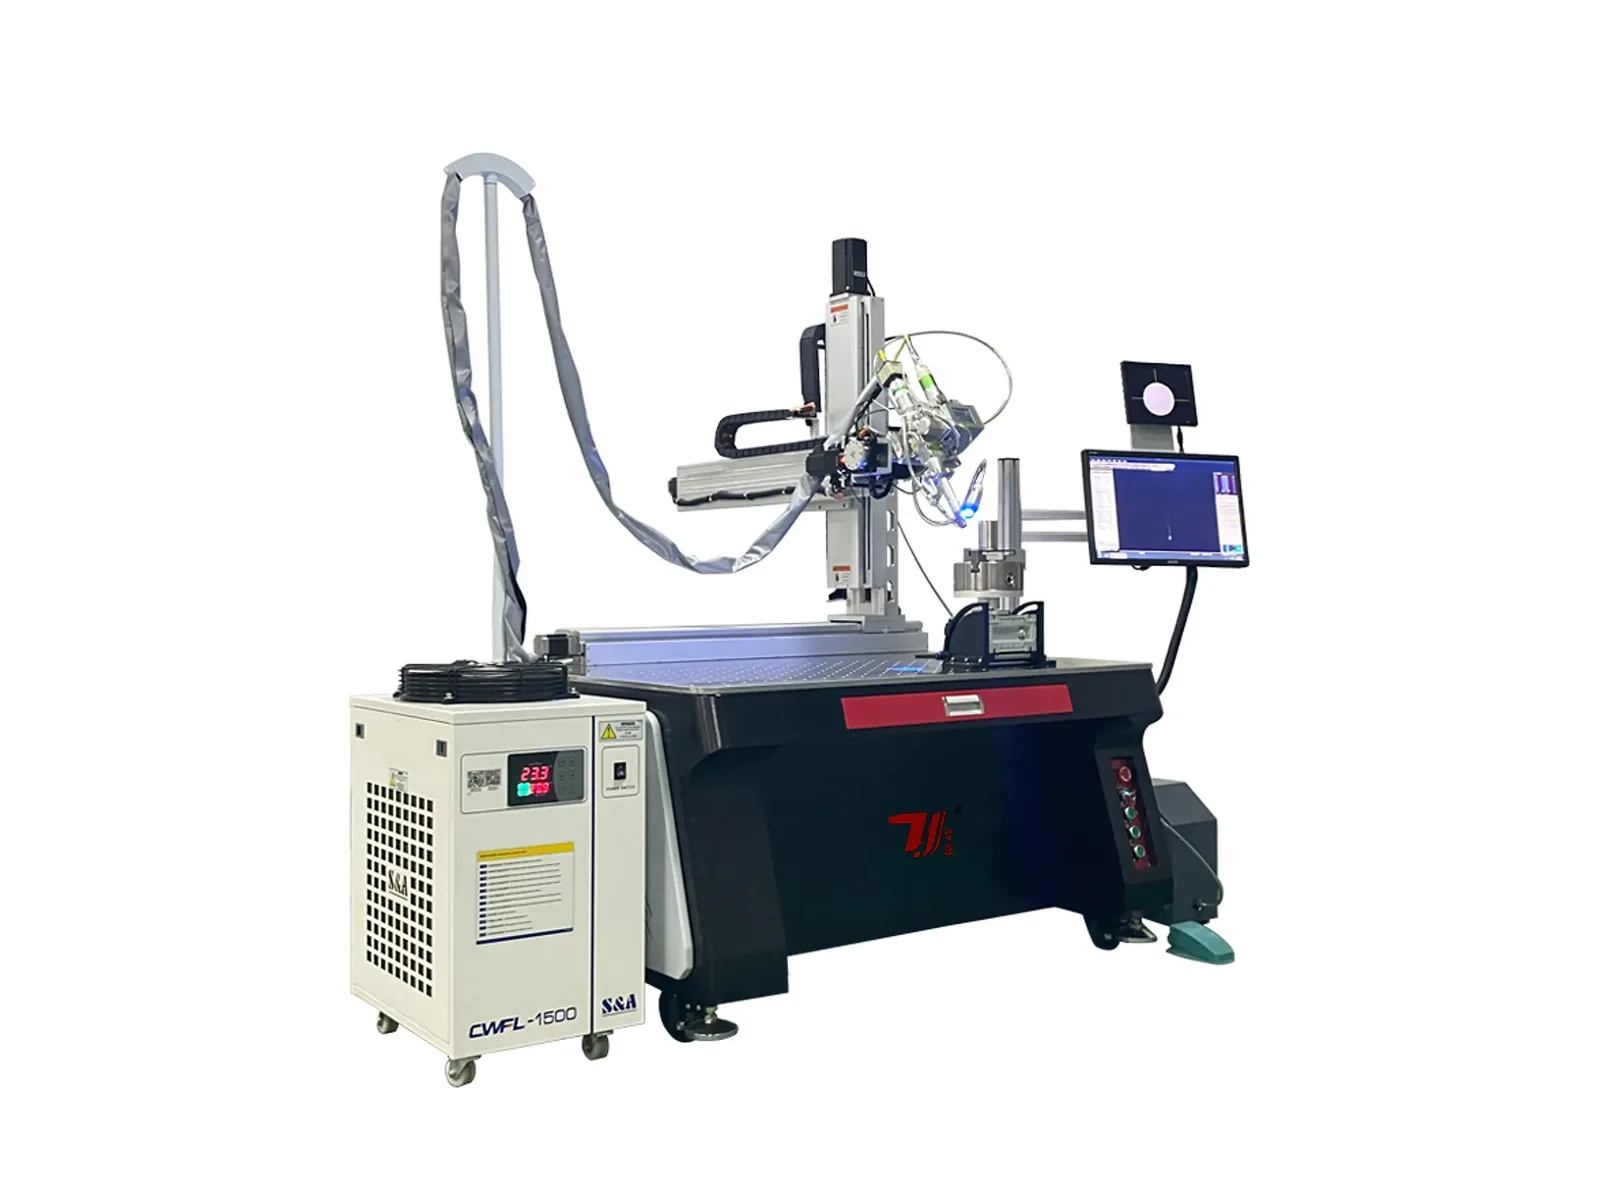
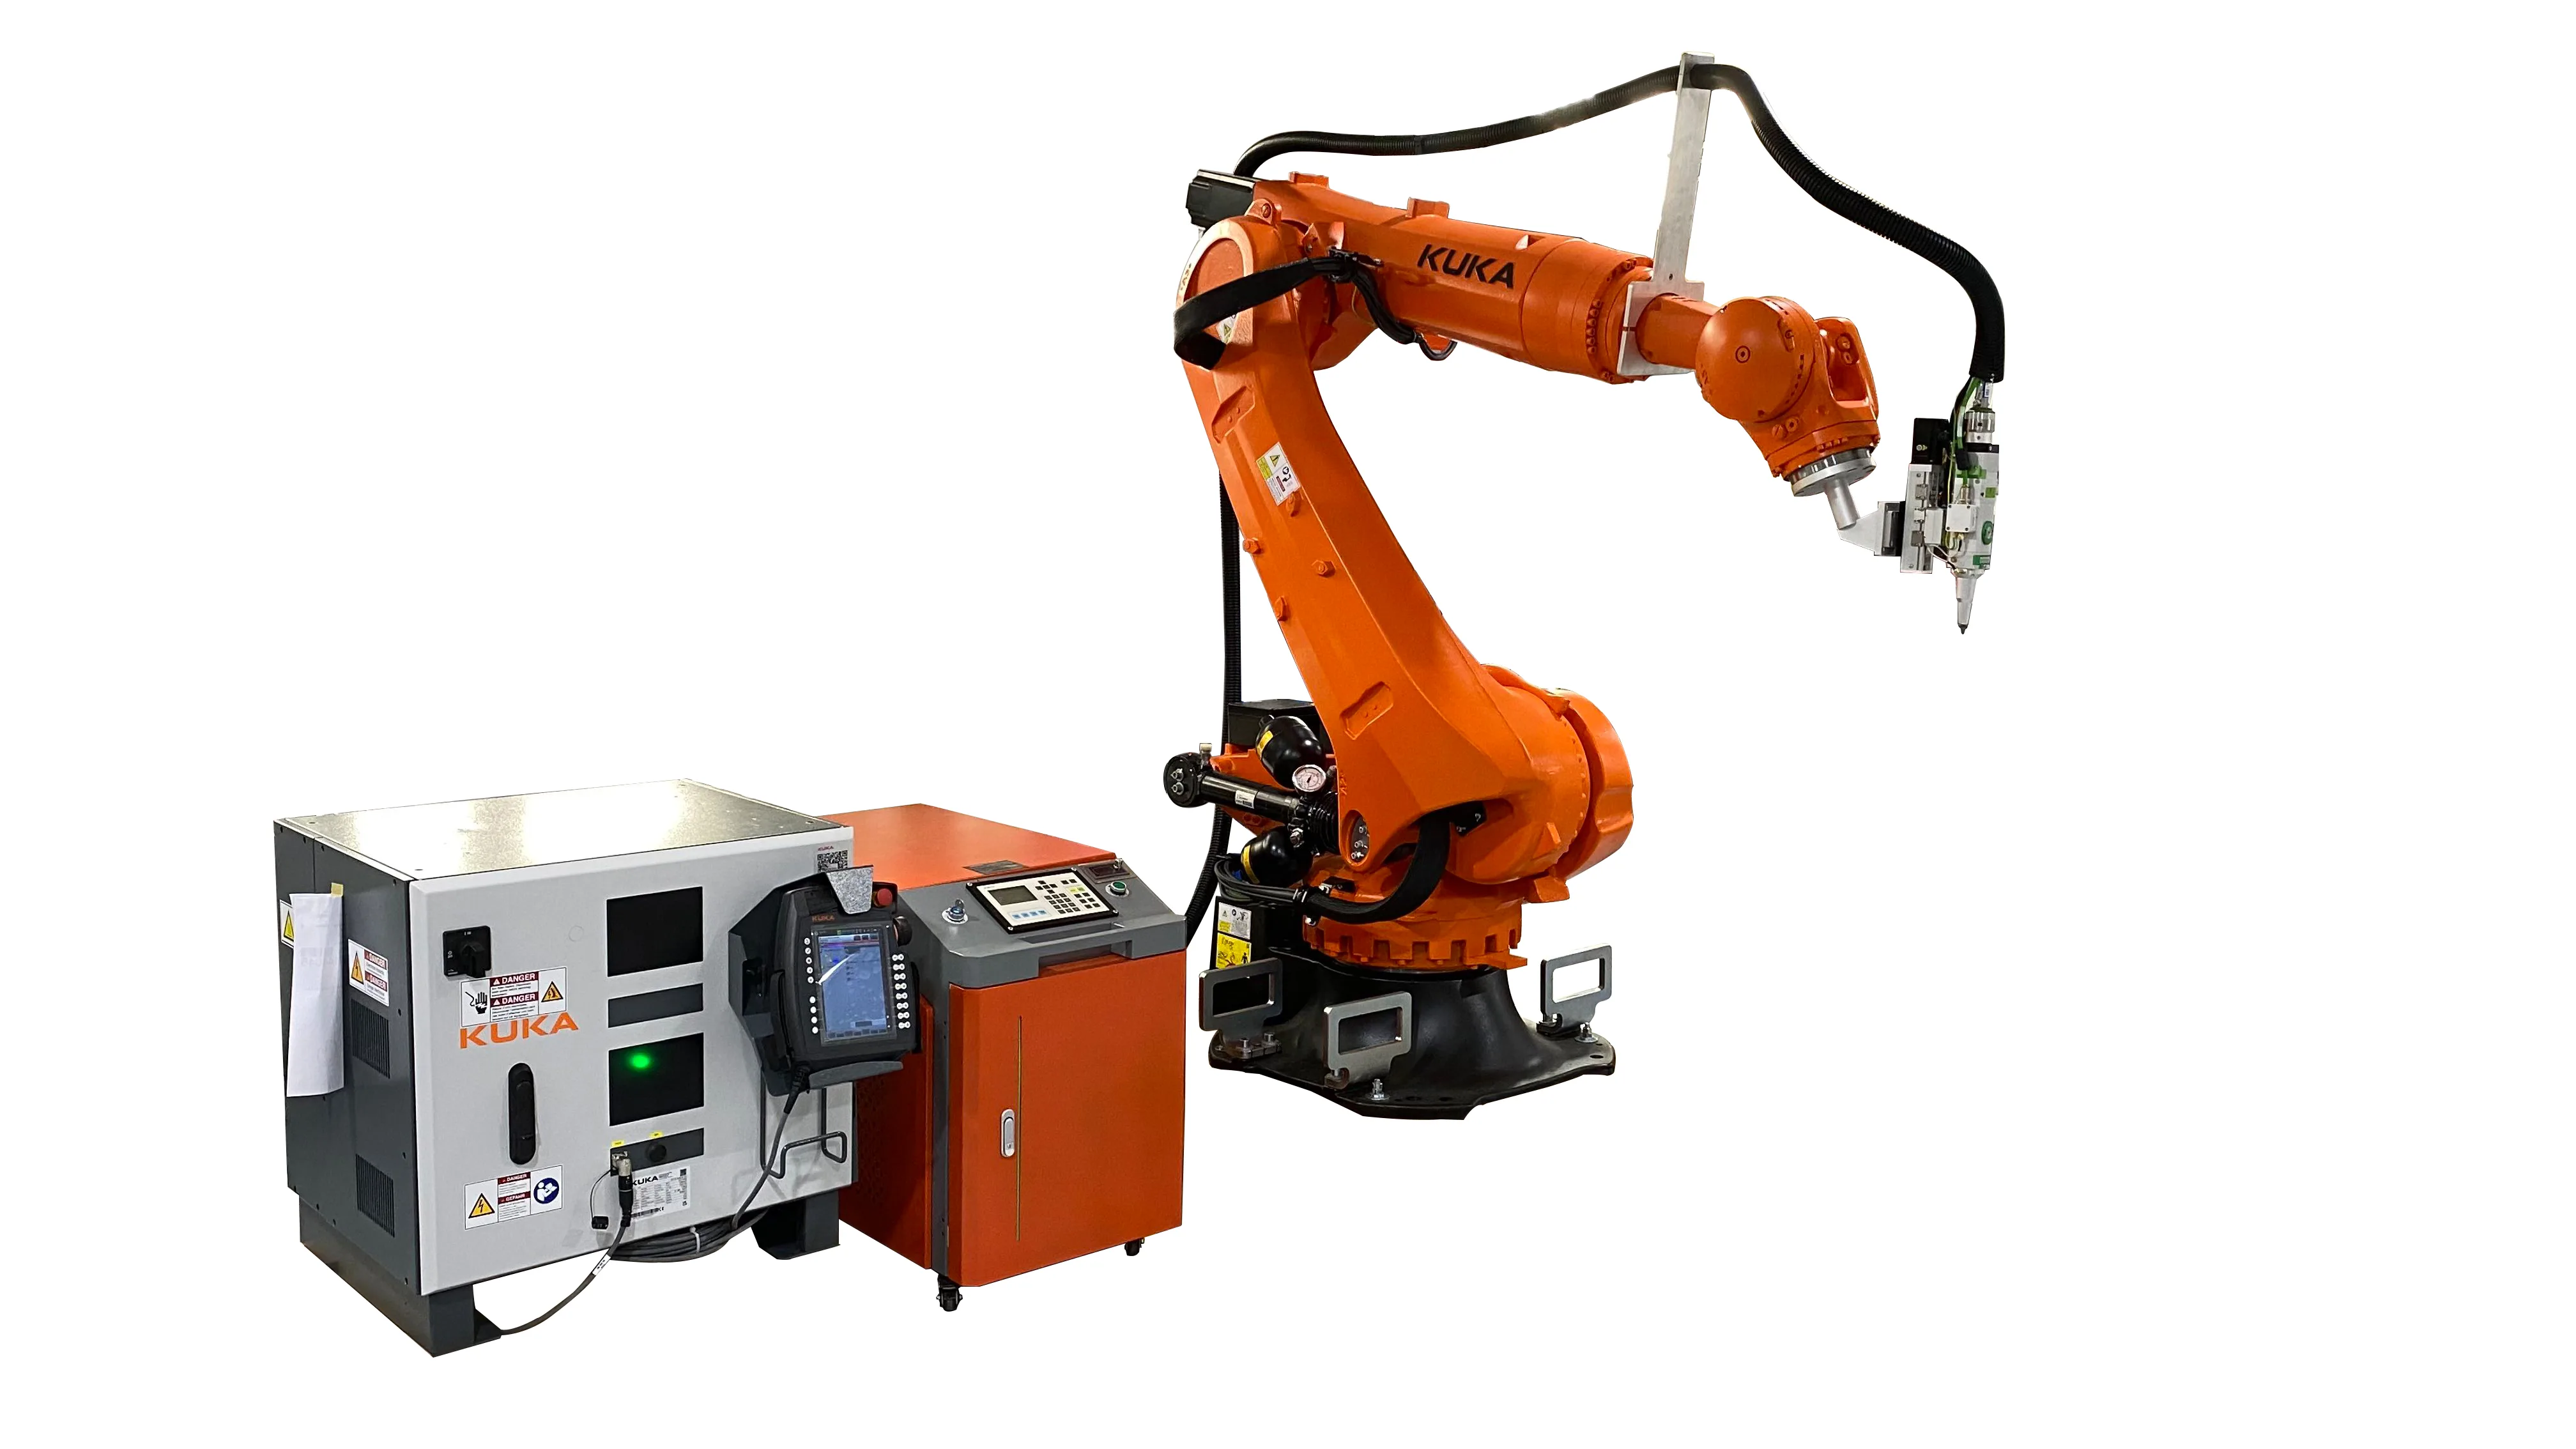
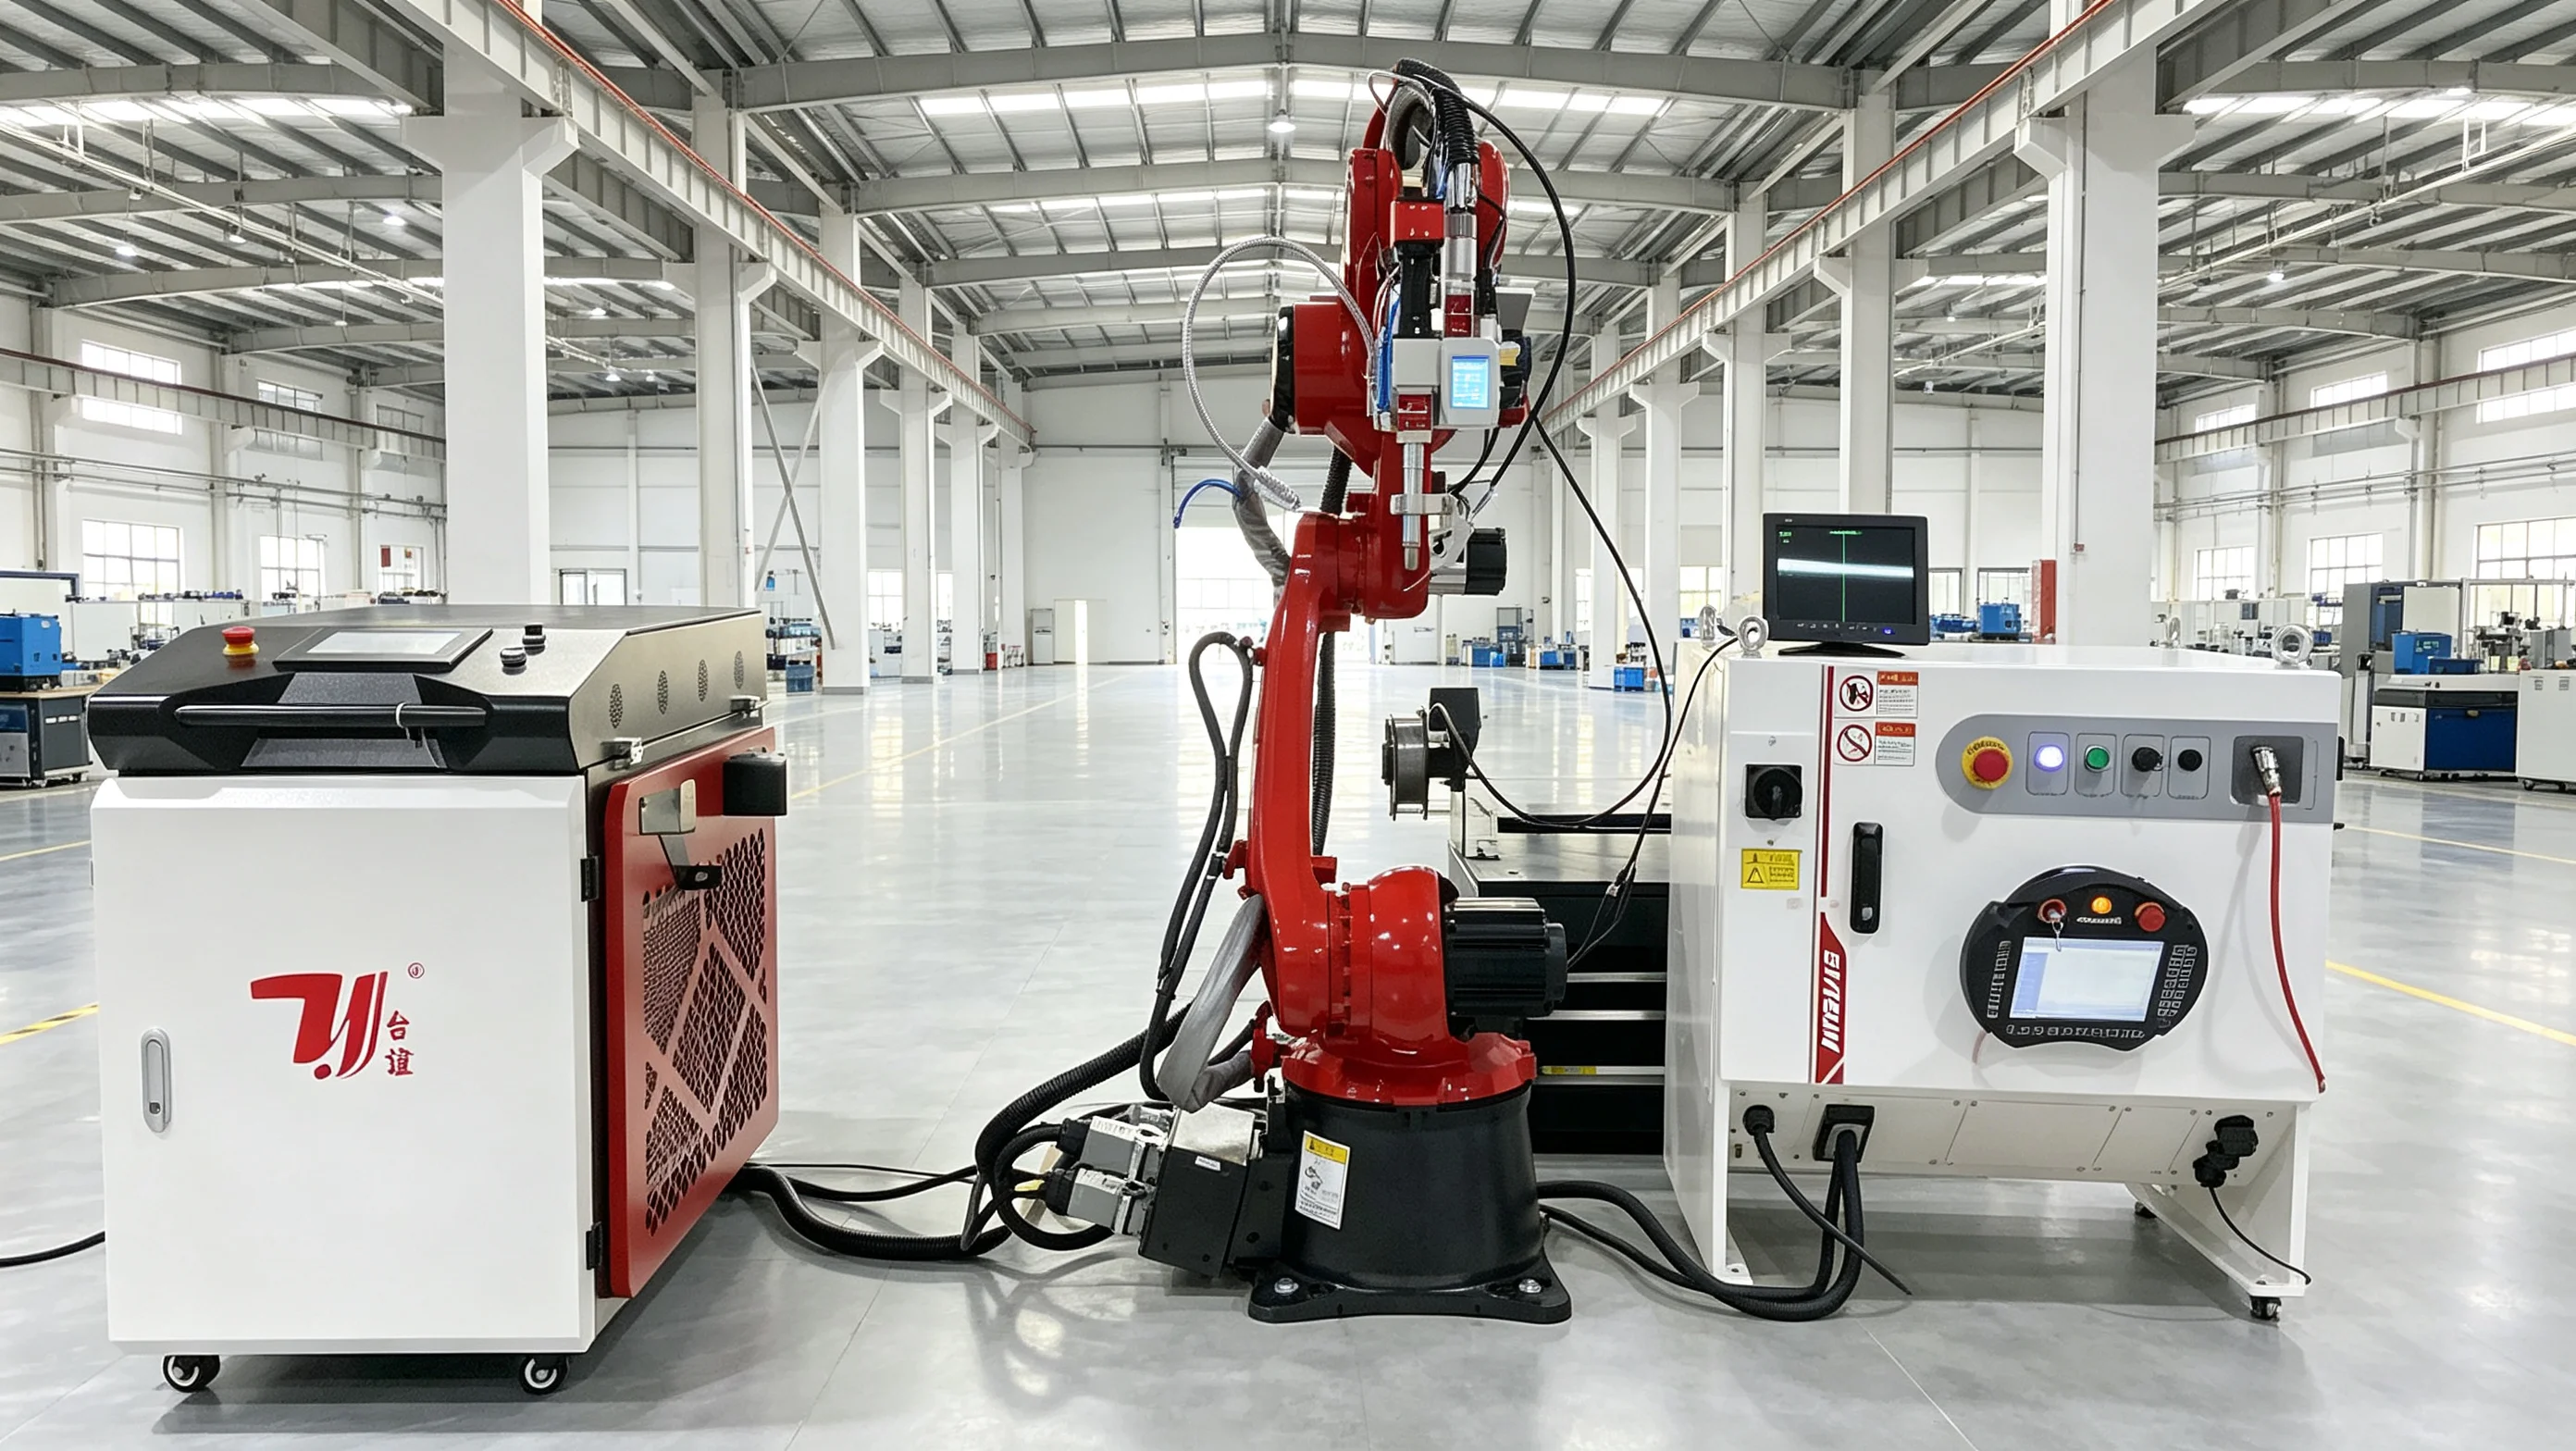
Robot automation systems
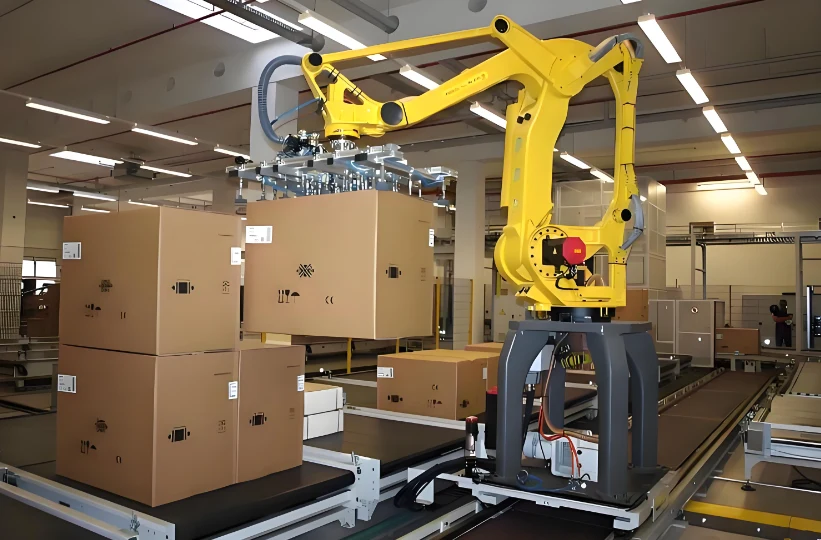
H-AGV Robot Handling System
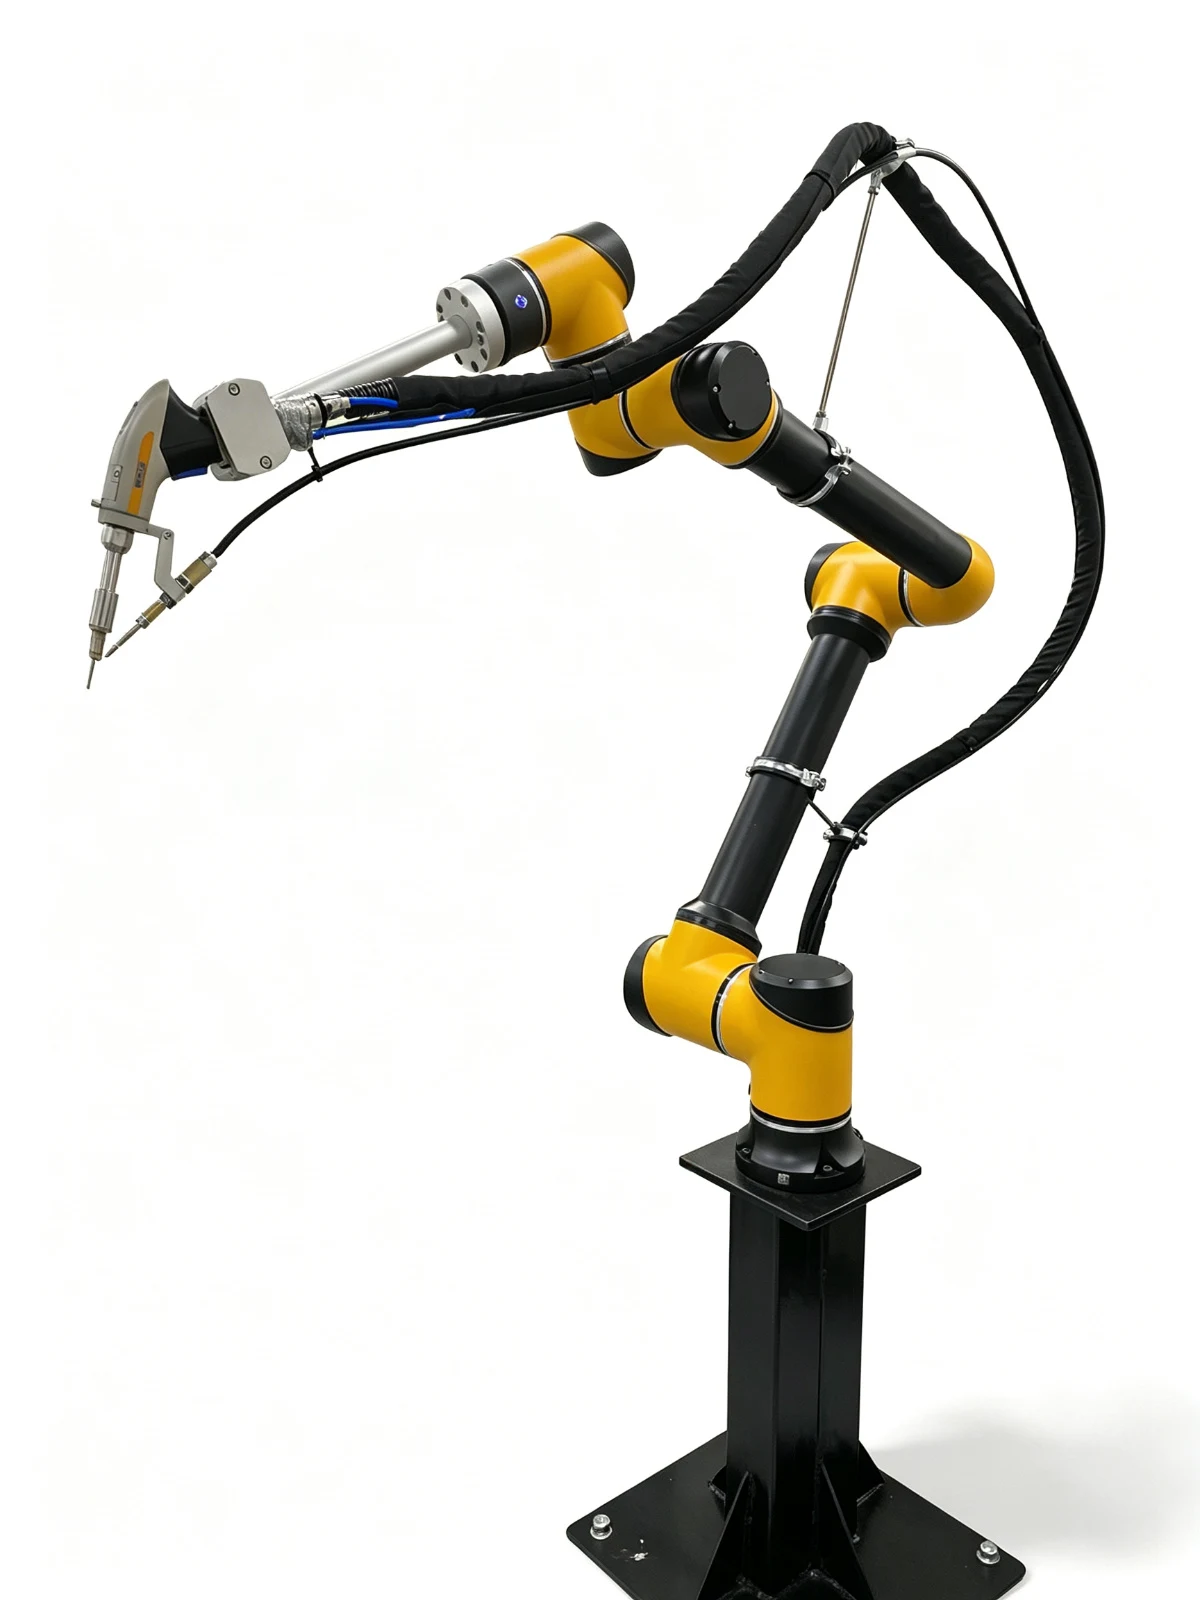
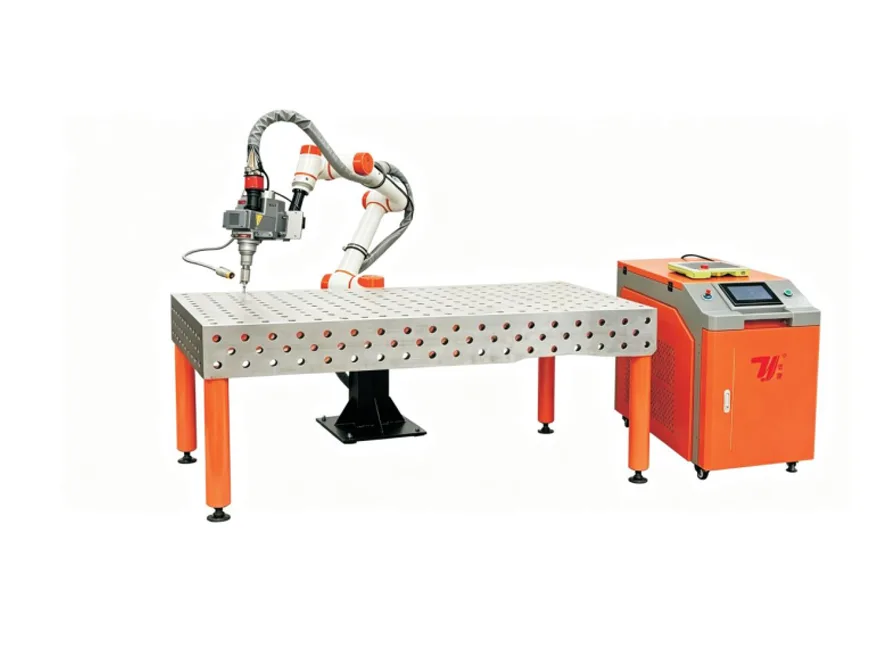
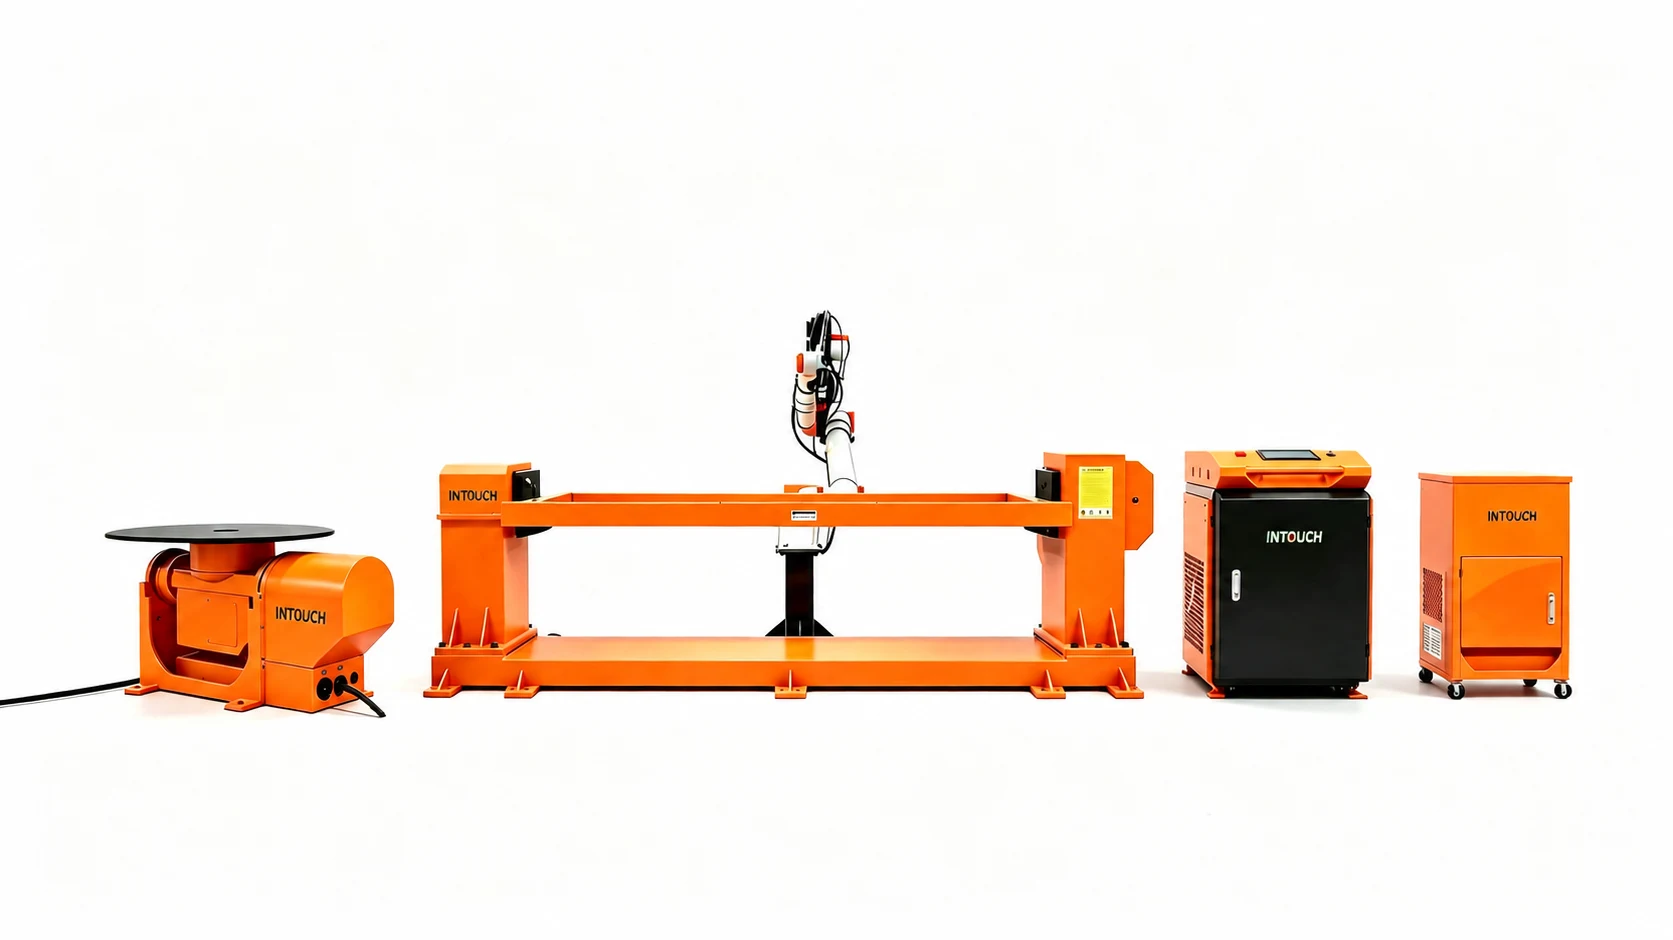
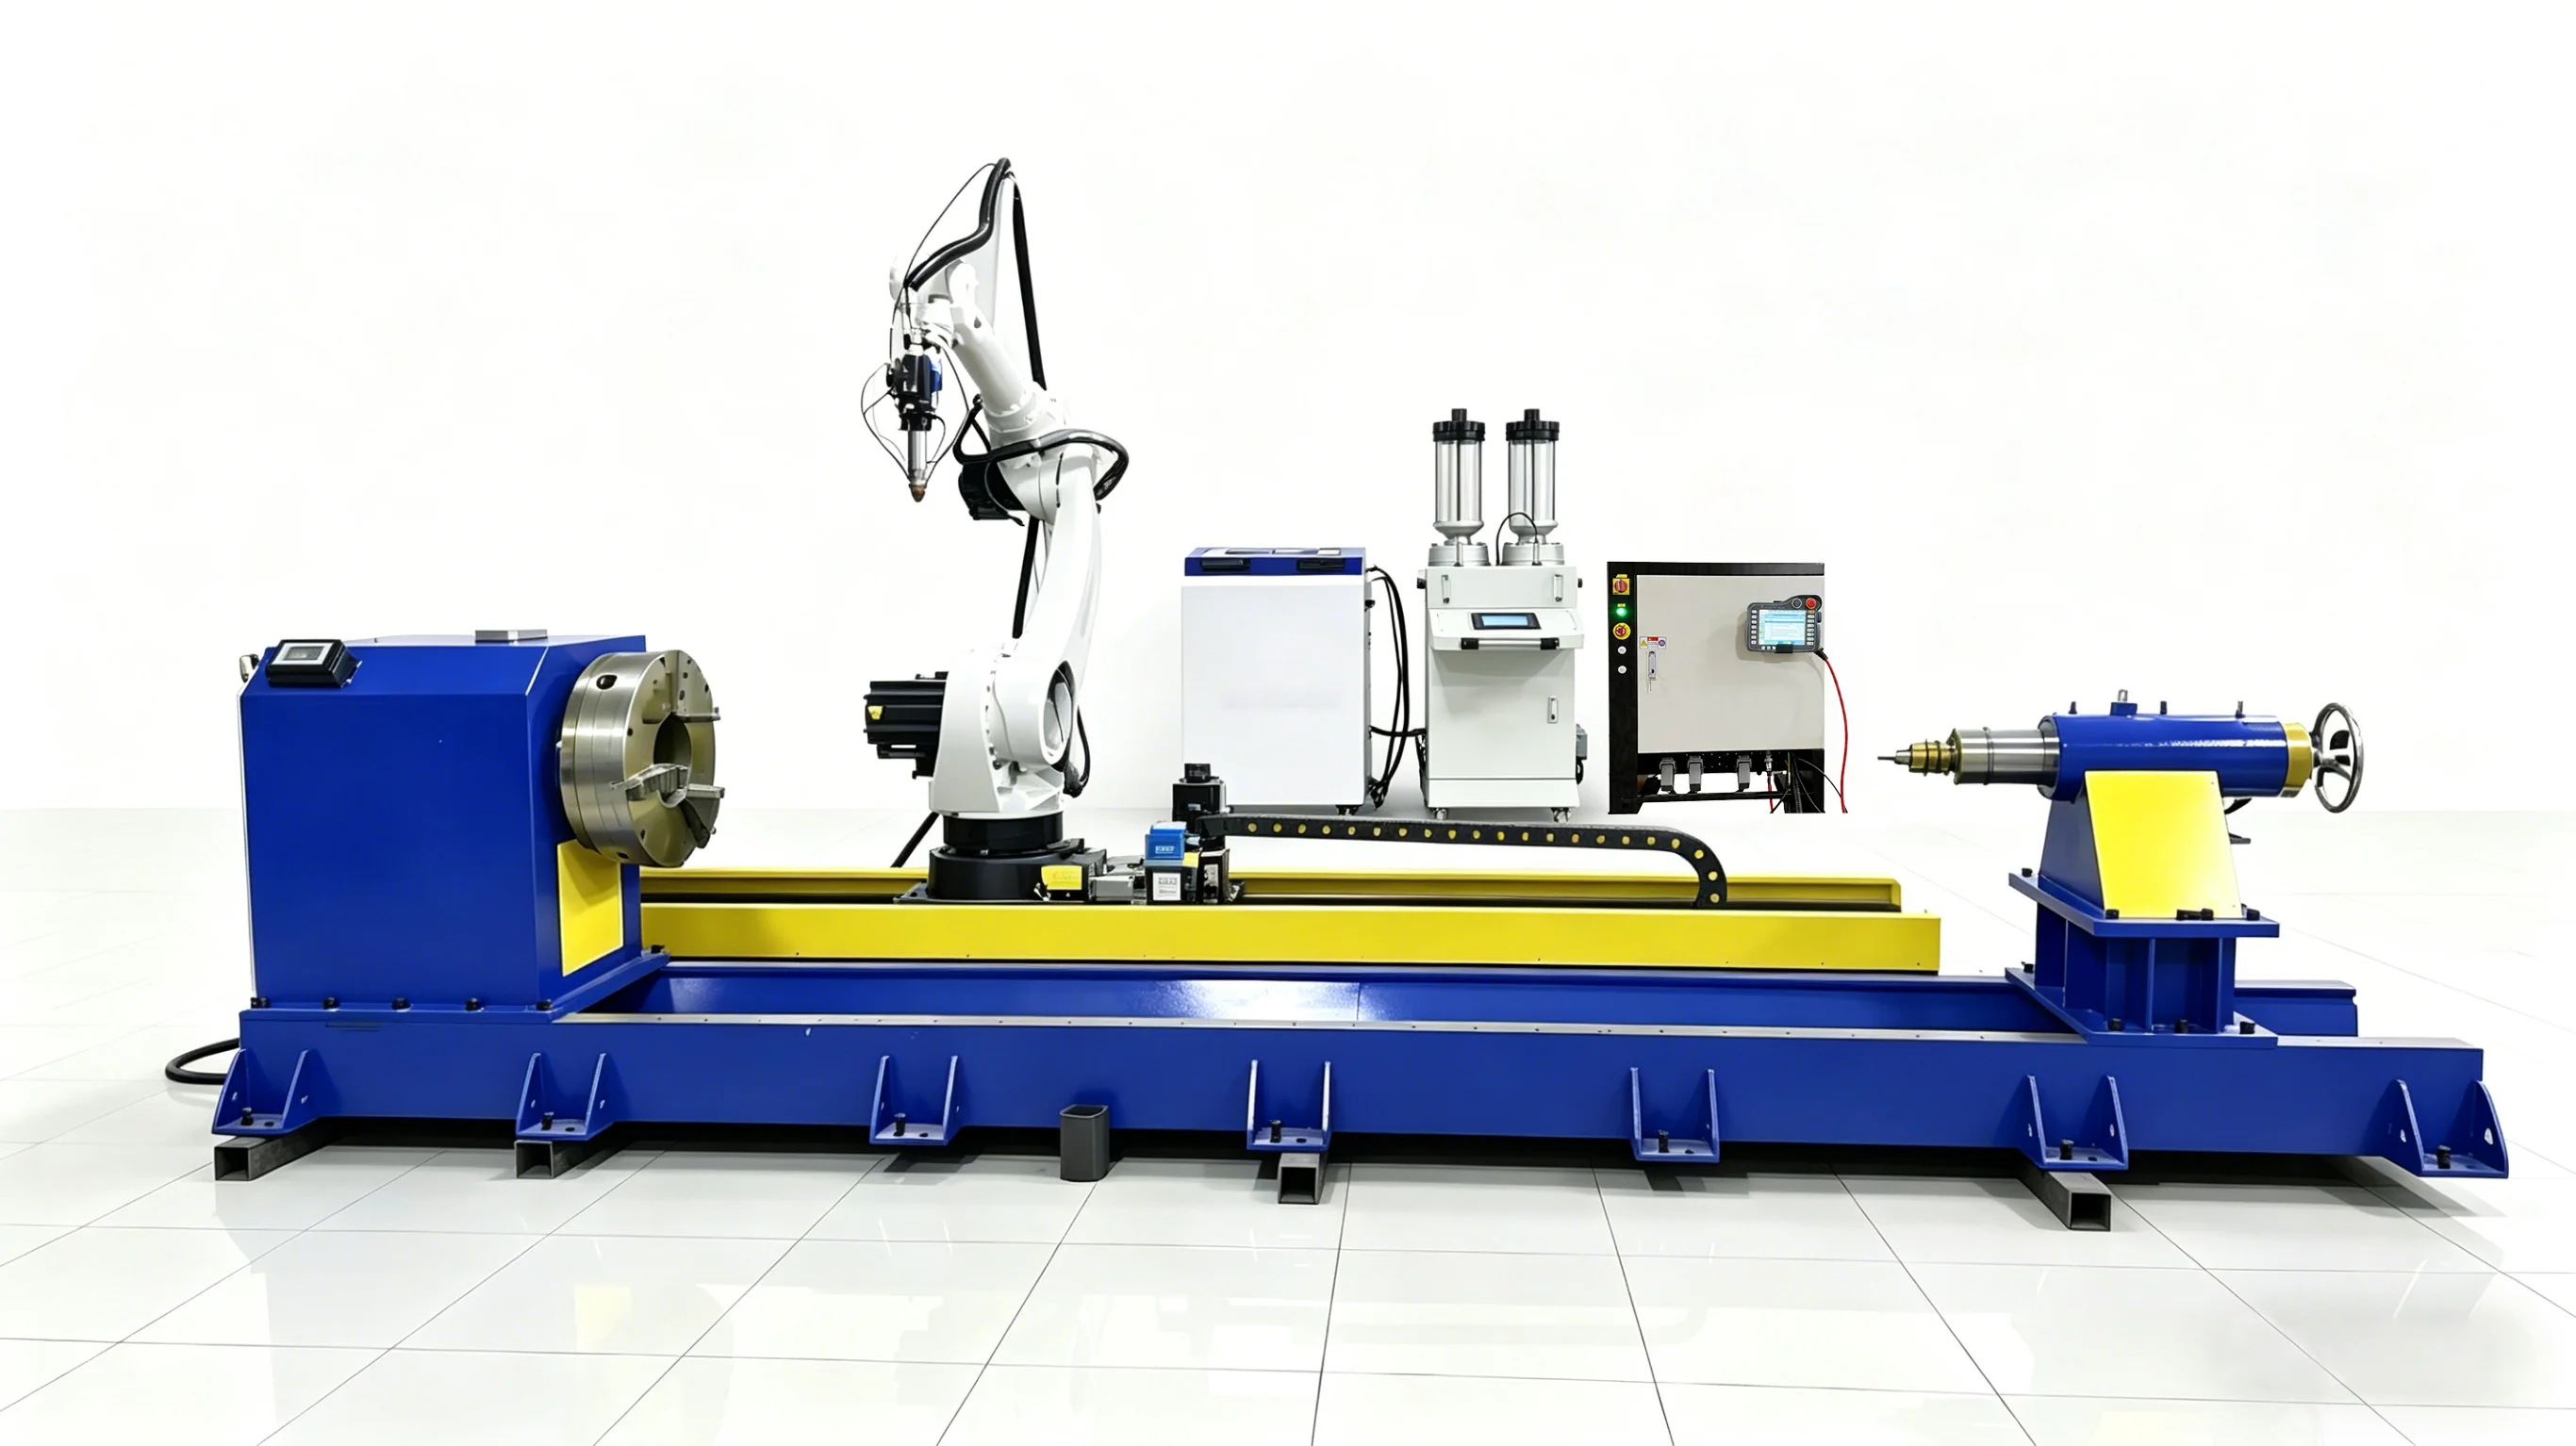
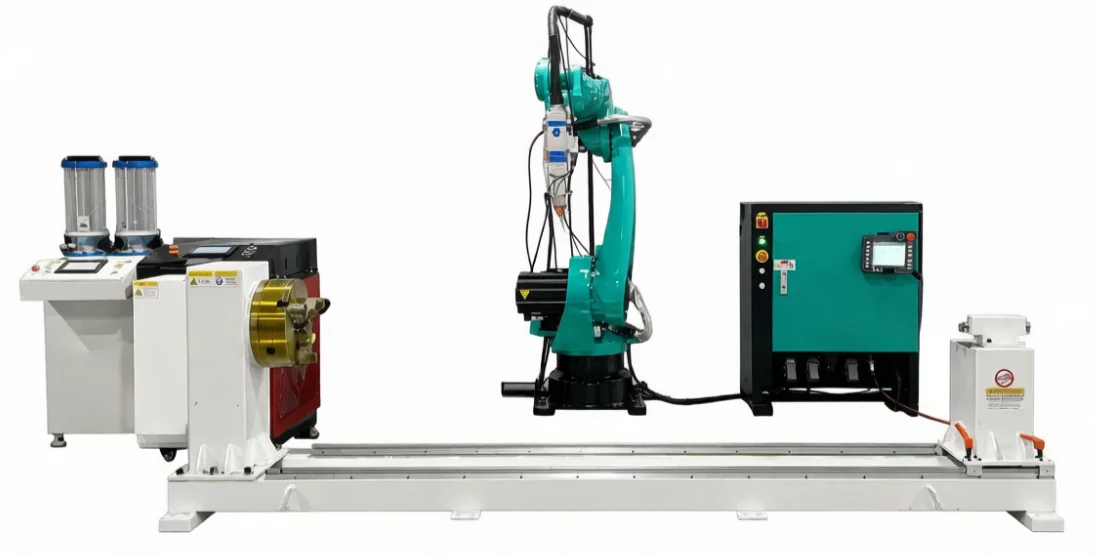
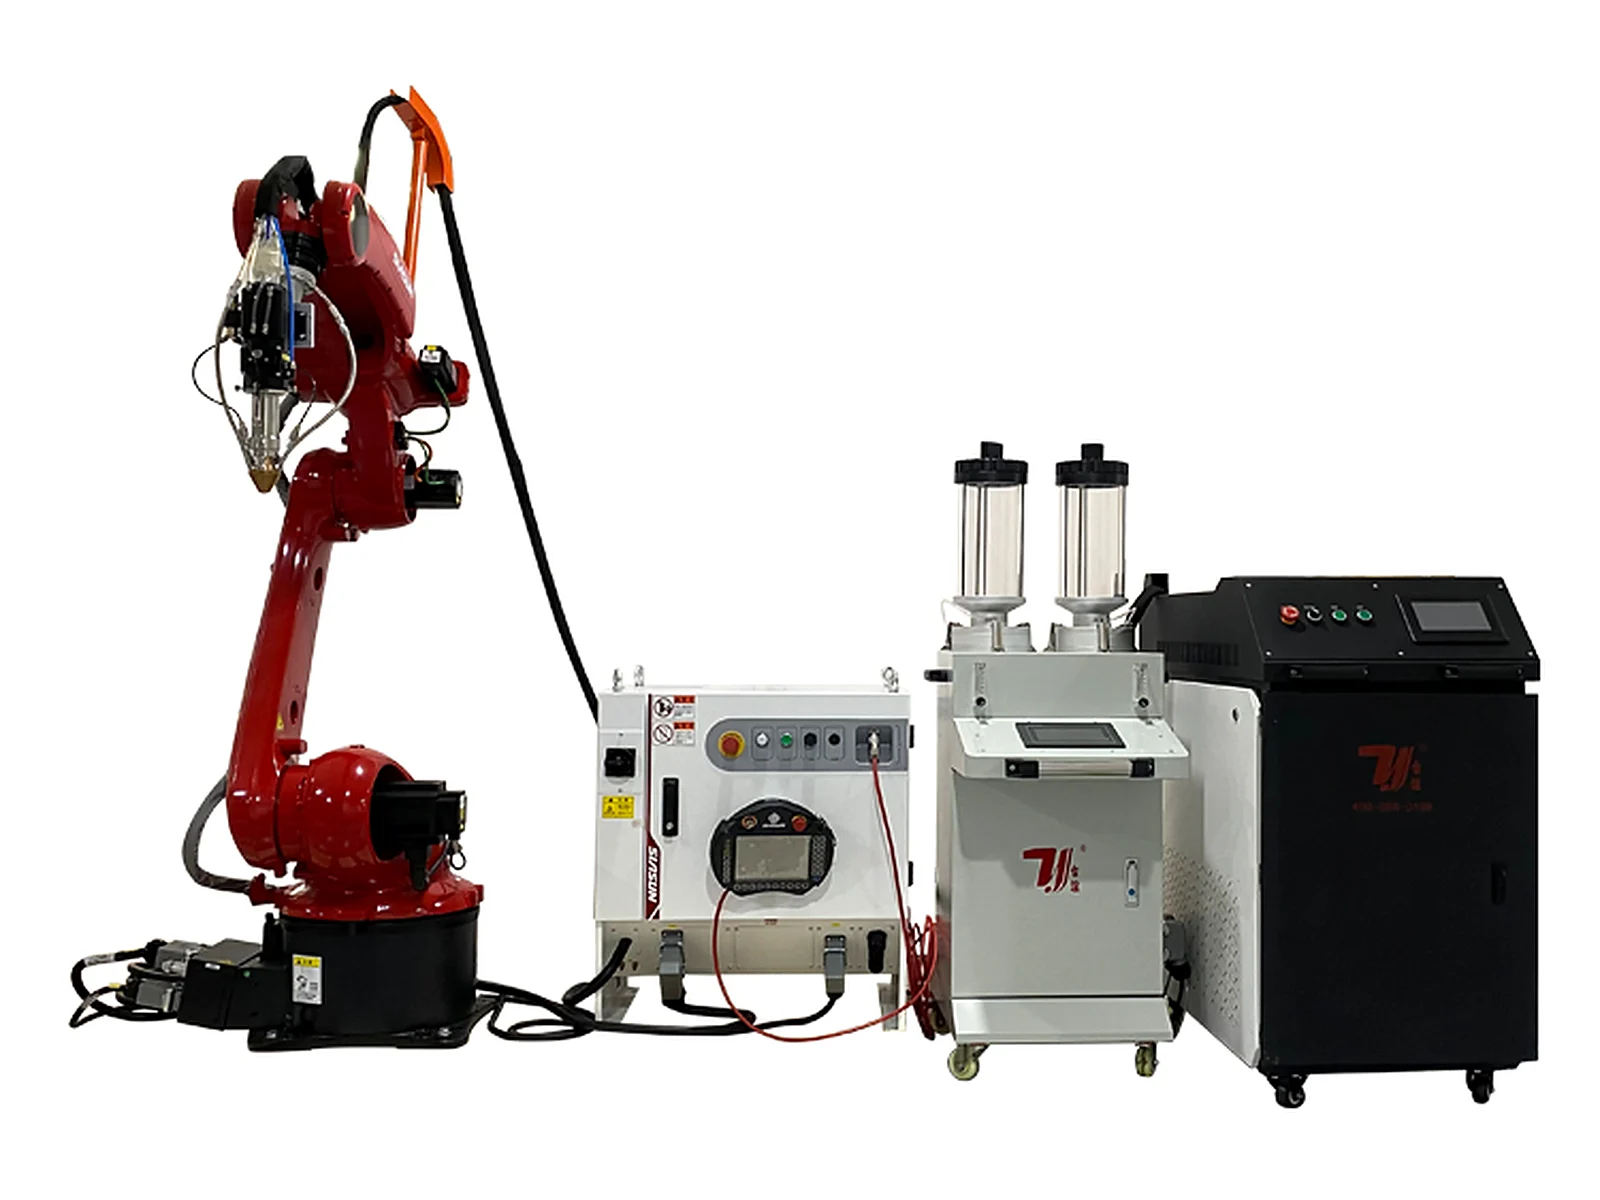
A fixed-base or rail-mounted industrial robot handling system for transferring parts and loads between defined stations. Select the gripper, robot reach, rail arrangement and connected equipment around the load and workflow.
The quotation defines the robot, process equipment, fixtures, safeguarding, installation and acceptance scope for your application.
Specifications
H-AGV configuration
Machine configuration
- System type
- Fixed-base or rail-mounted industrial robot
- Mounting
- Fixed pedestal / linear rail configuration
- End effector
- Configured for the workpiece and load
- Robot payload and reach
- Selected for the load, gripper and station layout
- Rail length
- Specified for the station spacing
- Control interfaces
- Configured with connected production equipment
Features
Configure the system around your production task
Fixed or travelling robot
Use a fixed mounting point or a linear rail to serve the required stations.
Load-specific end effector
Define gripping surfaces, orientation, dimensions and centre of gravity before selecting tooling.
Station-to-station handling
Coordinate pickup, transfer and placement with conveyors, fixtures or machine loading points.
Integrated production cycle
Review access, guarding and interlocks together with the connected equipment.
Project configuration
From workpiece review to cell integration
- 01
Workpiece and production review
- 02
Robot and process selection
- 03
Fixture and layout planning
- 04
Programming and interface setup
- 05
Safeguarding and access review
- 06
Process trials and acceptance
Application scope
Parts and production applications
Review material, geometry, access and production requirements with the proposed configuration.
Related products
Compare related robot configurations
TY-QG5018
Six-axis fiber laser cutting for formed and irregular metal components. Program holes, trimmed edges and three-dimensional contours around the workpiece, with robot reach, tooling and laser power selected for each application.
Robot Laser Welding MachineTY-HS5018
Combine a six-axis industrial robot with a fiber laser welding system for repeatable three-dimensional joints. Configure the welding head, fixtures, wire feed and workpiece access around the material and seam.
Robot Laser Cutting Machine with PositionerTY-QG5020
Pair a six-axis laser-cutting robot with a rotary workpiece positioner for multi-sided metal parts. Coordinated reorientation brings additional surfaces into reach and supports cutting, trimming and hole-making around formed components.
Related industry solutions
Explore the applications and laser processes connected to this equipment.
View all industry solutions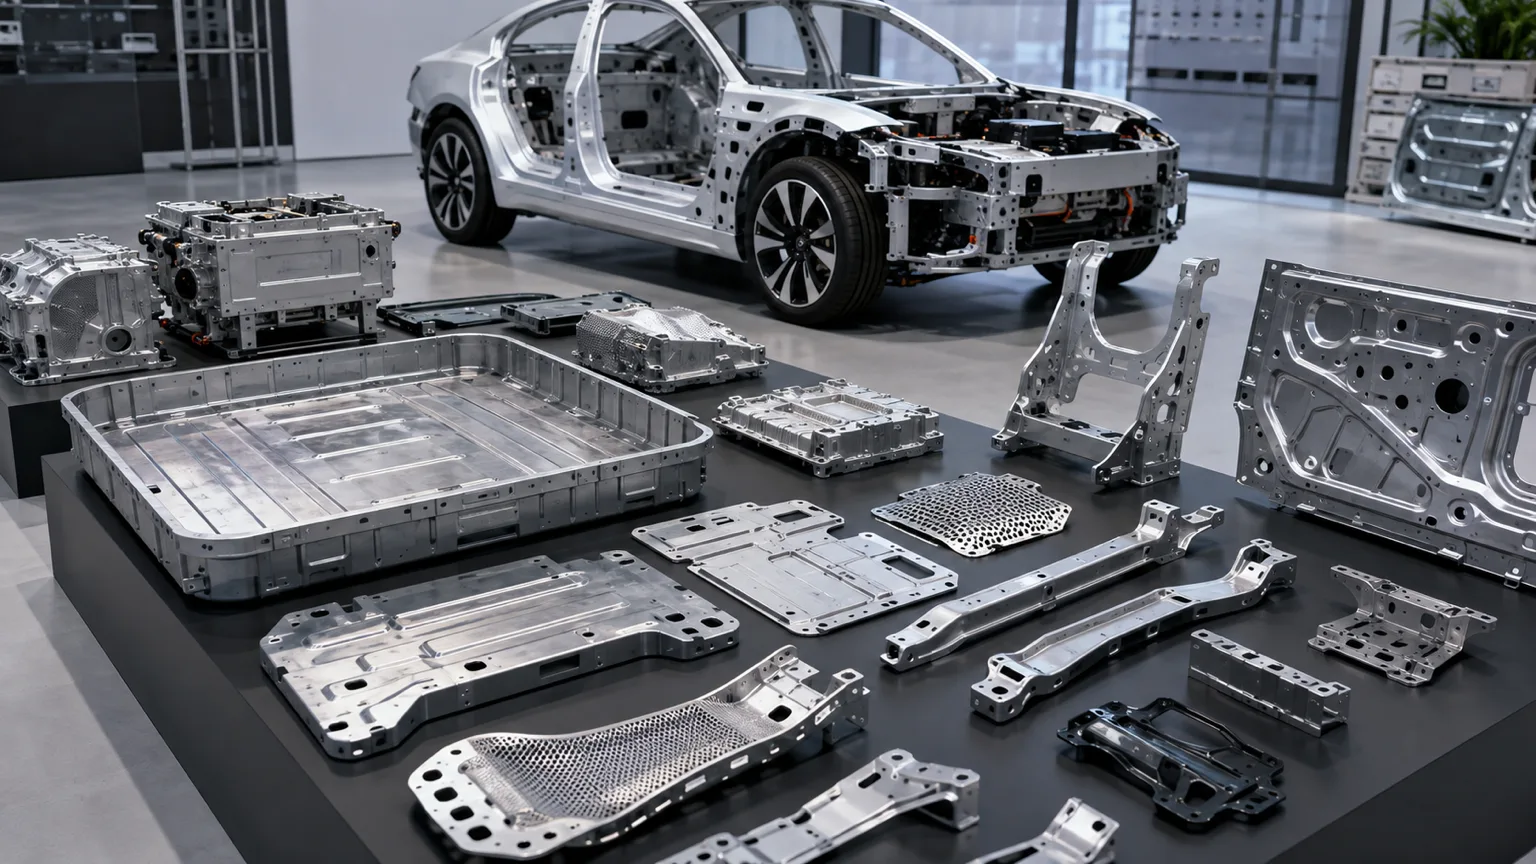
Define the complete workstation before selecting the robot
Workpiece and tooling
Provide drawings, material, dimensions, mass and the required operations. Include fixture access and the intended loading method so the robot and tooling can be selected together.
Integration and acceptance
Specify production targets, connected equipment and available floor space. Agree the process trial, guarding, interfaces and acceptance criteria for the complete cell.
Machine selection questions
How is the H-AGV configured?
A fixed-base or rail-mounted industrial robot handling system for transferring parts and loads between defined stations. Select the gripper, robot reach, rail arrangement and connected equipment around the load and workflow.
What information is needed for a quotation?
Send representative part drawings, material and dimensions, required operations, target output and available layout. Include connected equipment and any requested fixture or positioner.
How are guarding and operator access defined?
The complete application determines protective measures. The process, tool, workpiece, fixtures and operator access are considered together when defining guarding and interlocks.
Request a quote
Tell us the part. We will tell you the machine.
Price and delivery depend on the robot, process package, workholding, safeguarding and integration scope.
- Phone+86 153 6281 4831
- Emailsales02@taiyilaser.com
- WhatsApp+86 153 6281 4831