TAIYI LASER

Industrial robots

Robot automation systems

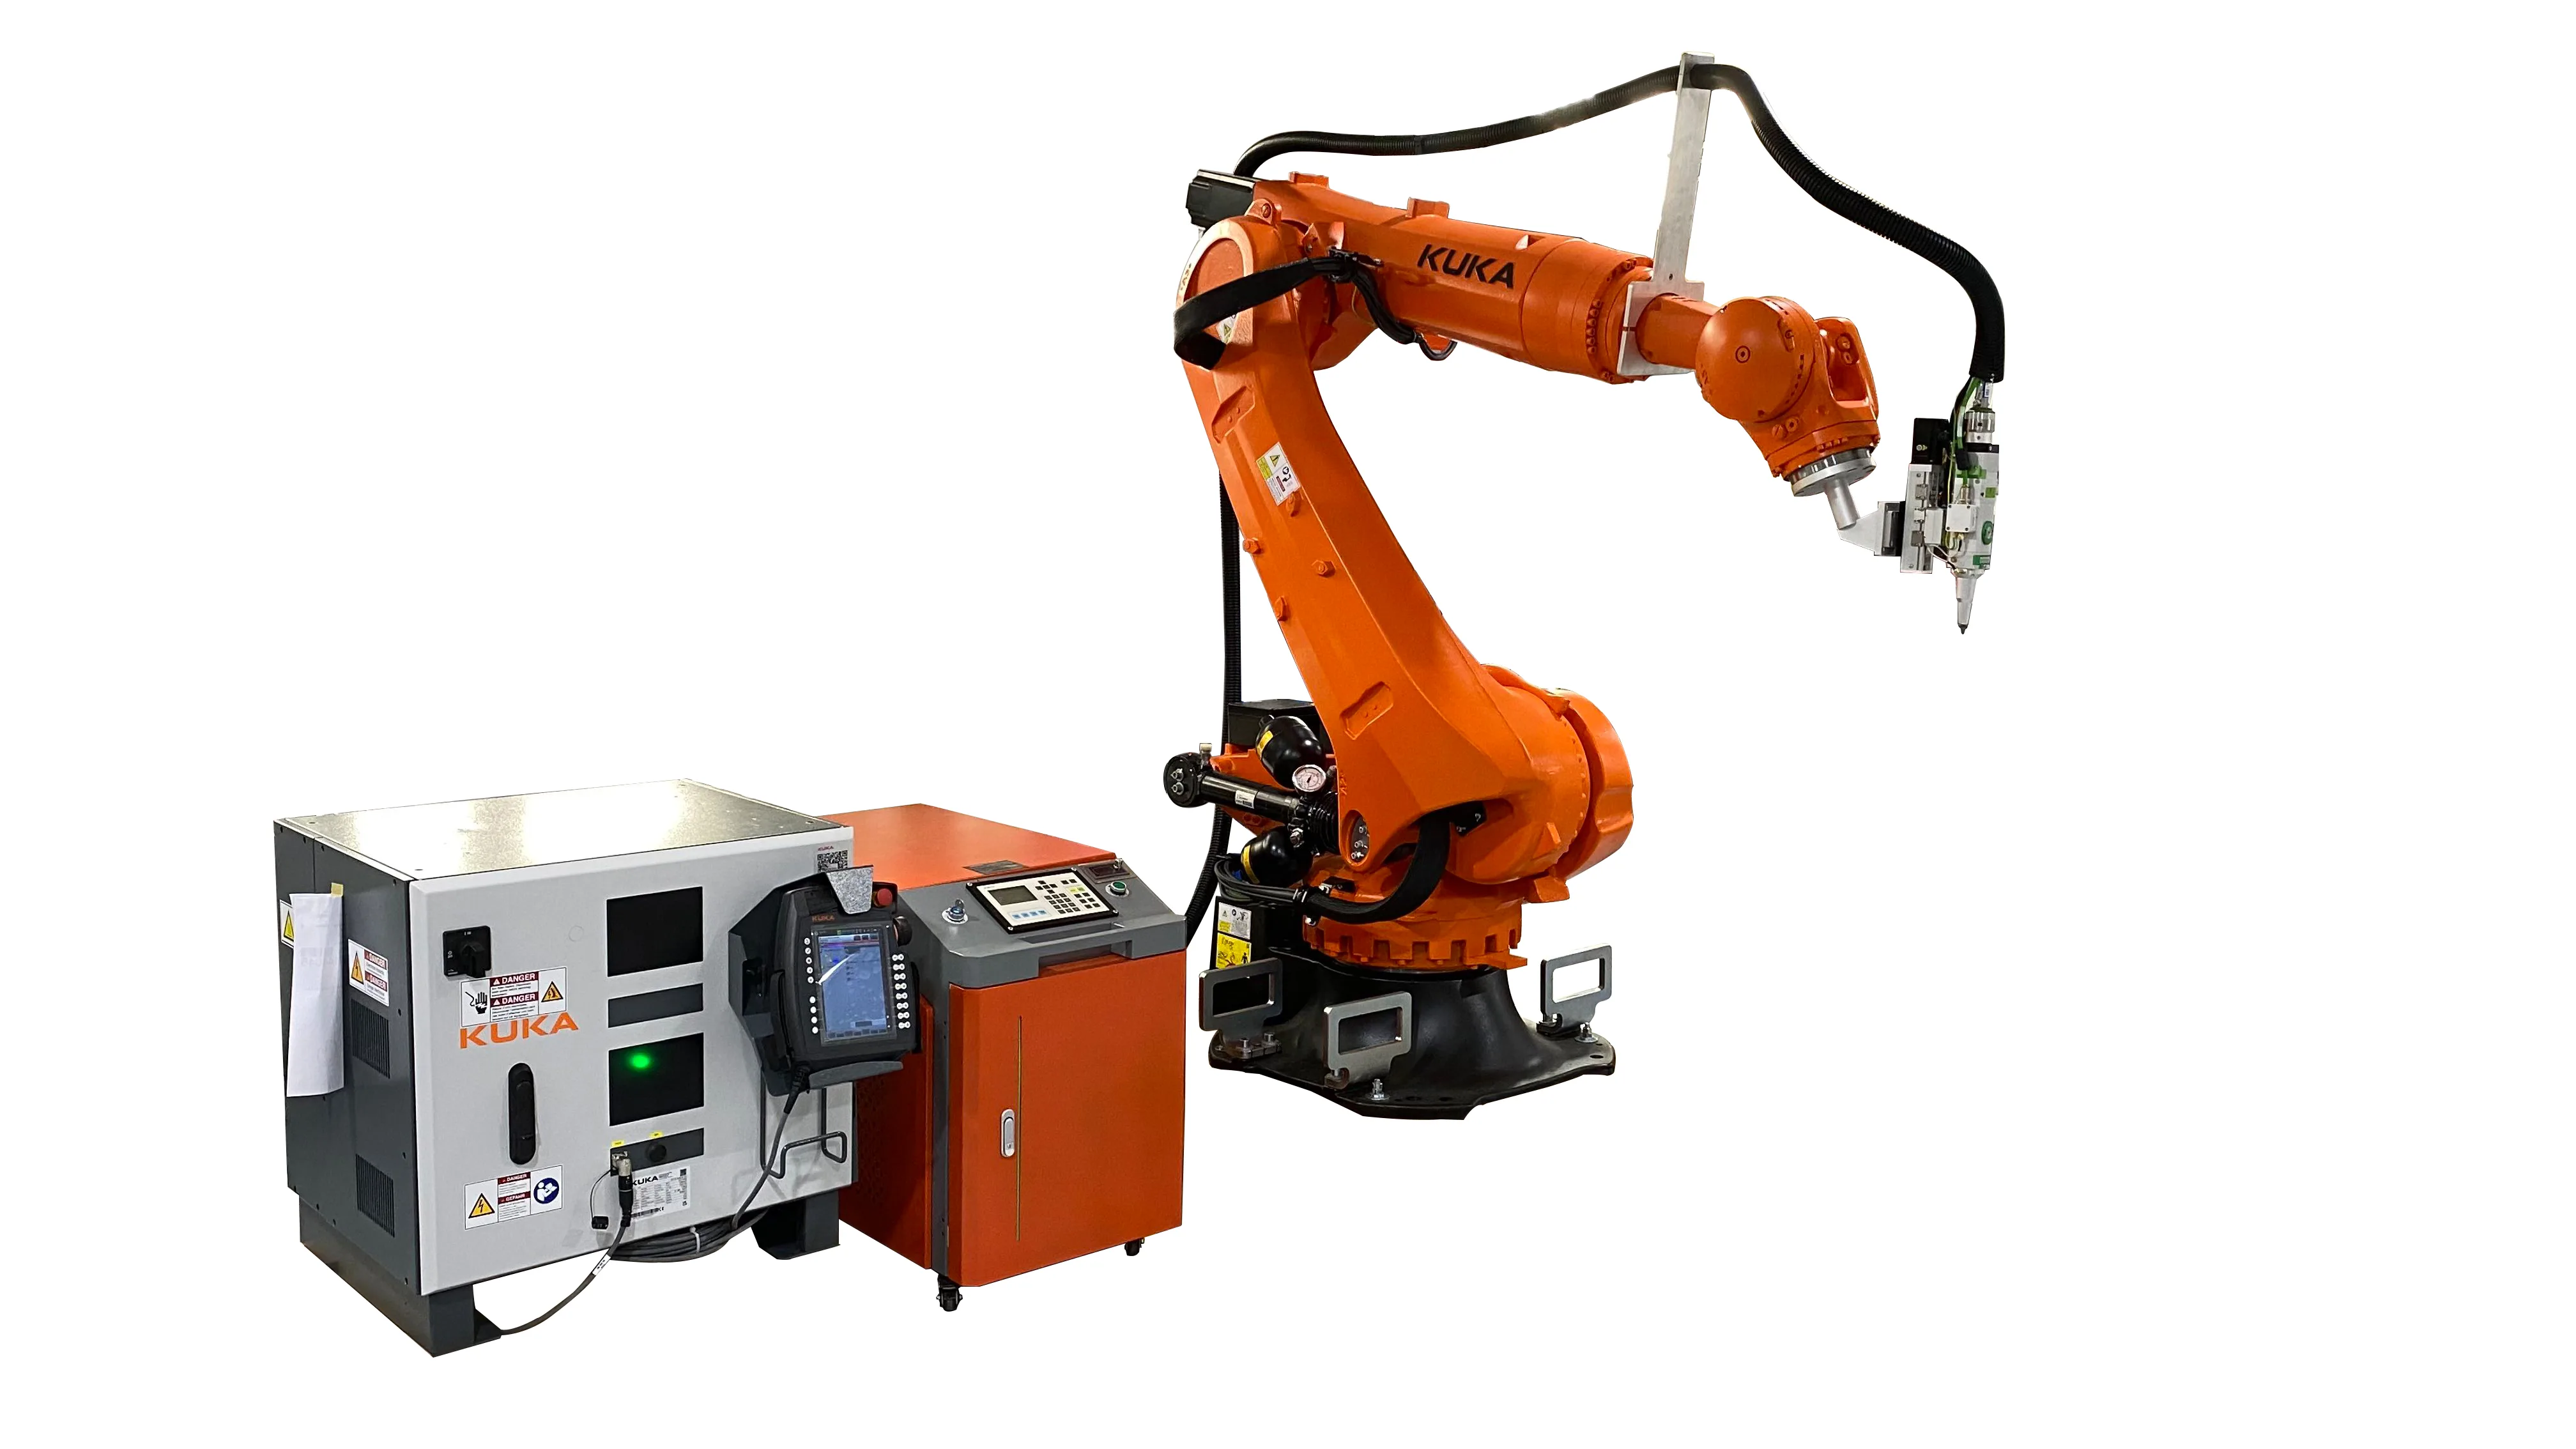
Compare five robot systems for laser cutting, laser welding and fixed or rail-mounted handling, including positioner and overhead gantry cutting configurations.

Available range05 robot systems
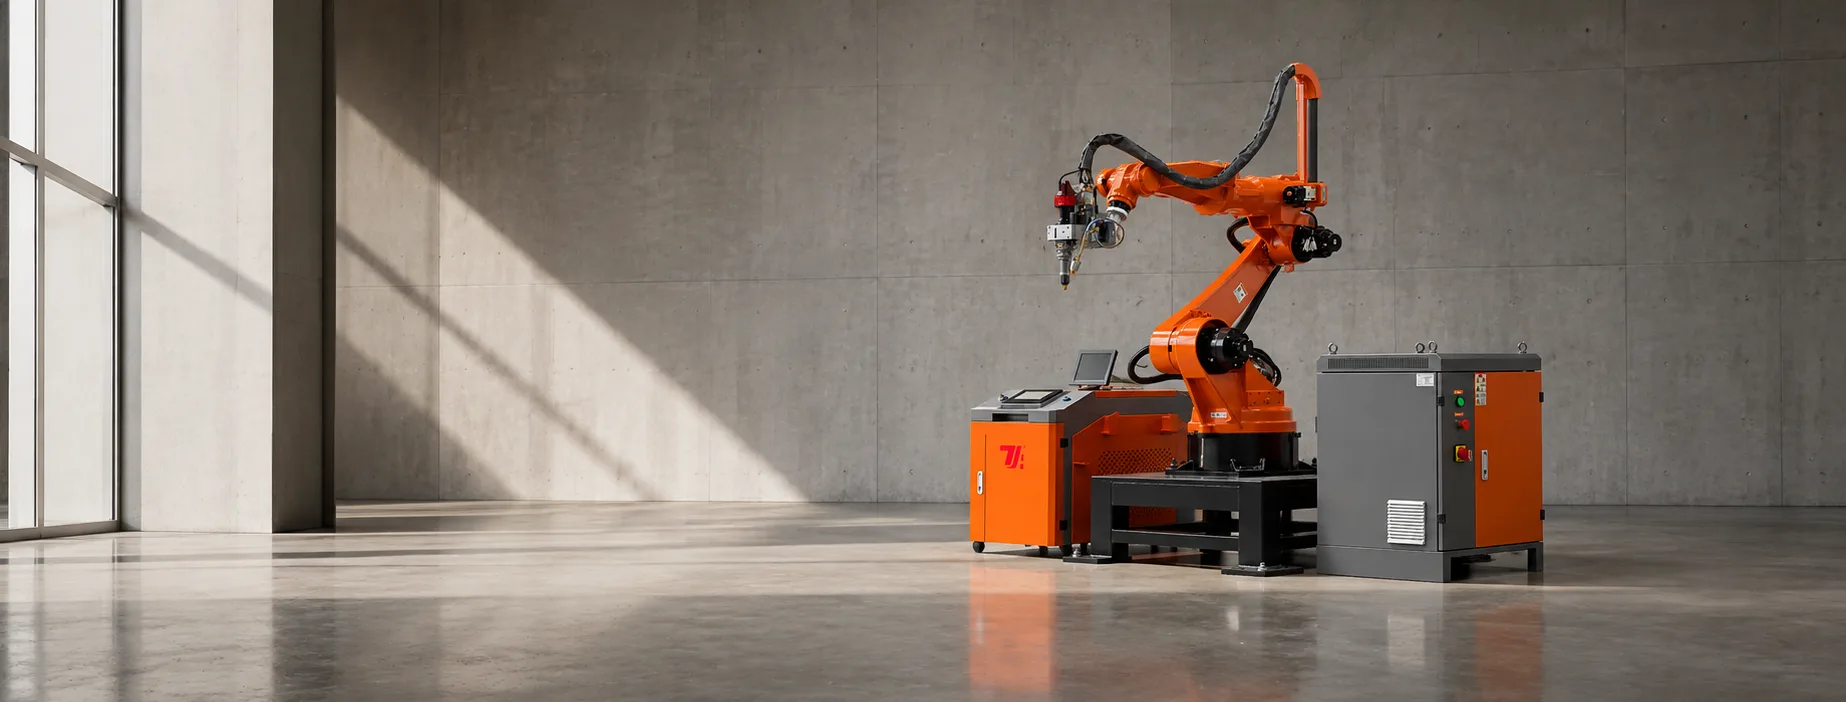
Industrial robot workstation in a warm concrete studio

Machines in this category

Choose the complete robot system by its production task

Compare standard robot laser cutting, positioner-assisted cutting, overhead gantry cutting, laser welding and fixed or rail-mounted handling. The part, tool access and workholding determine the complete cell.

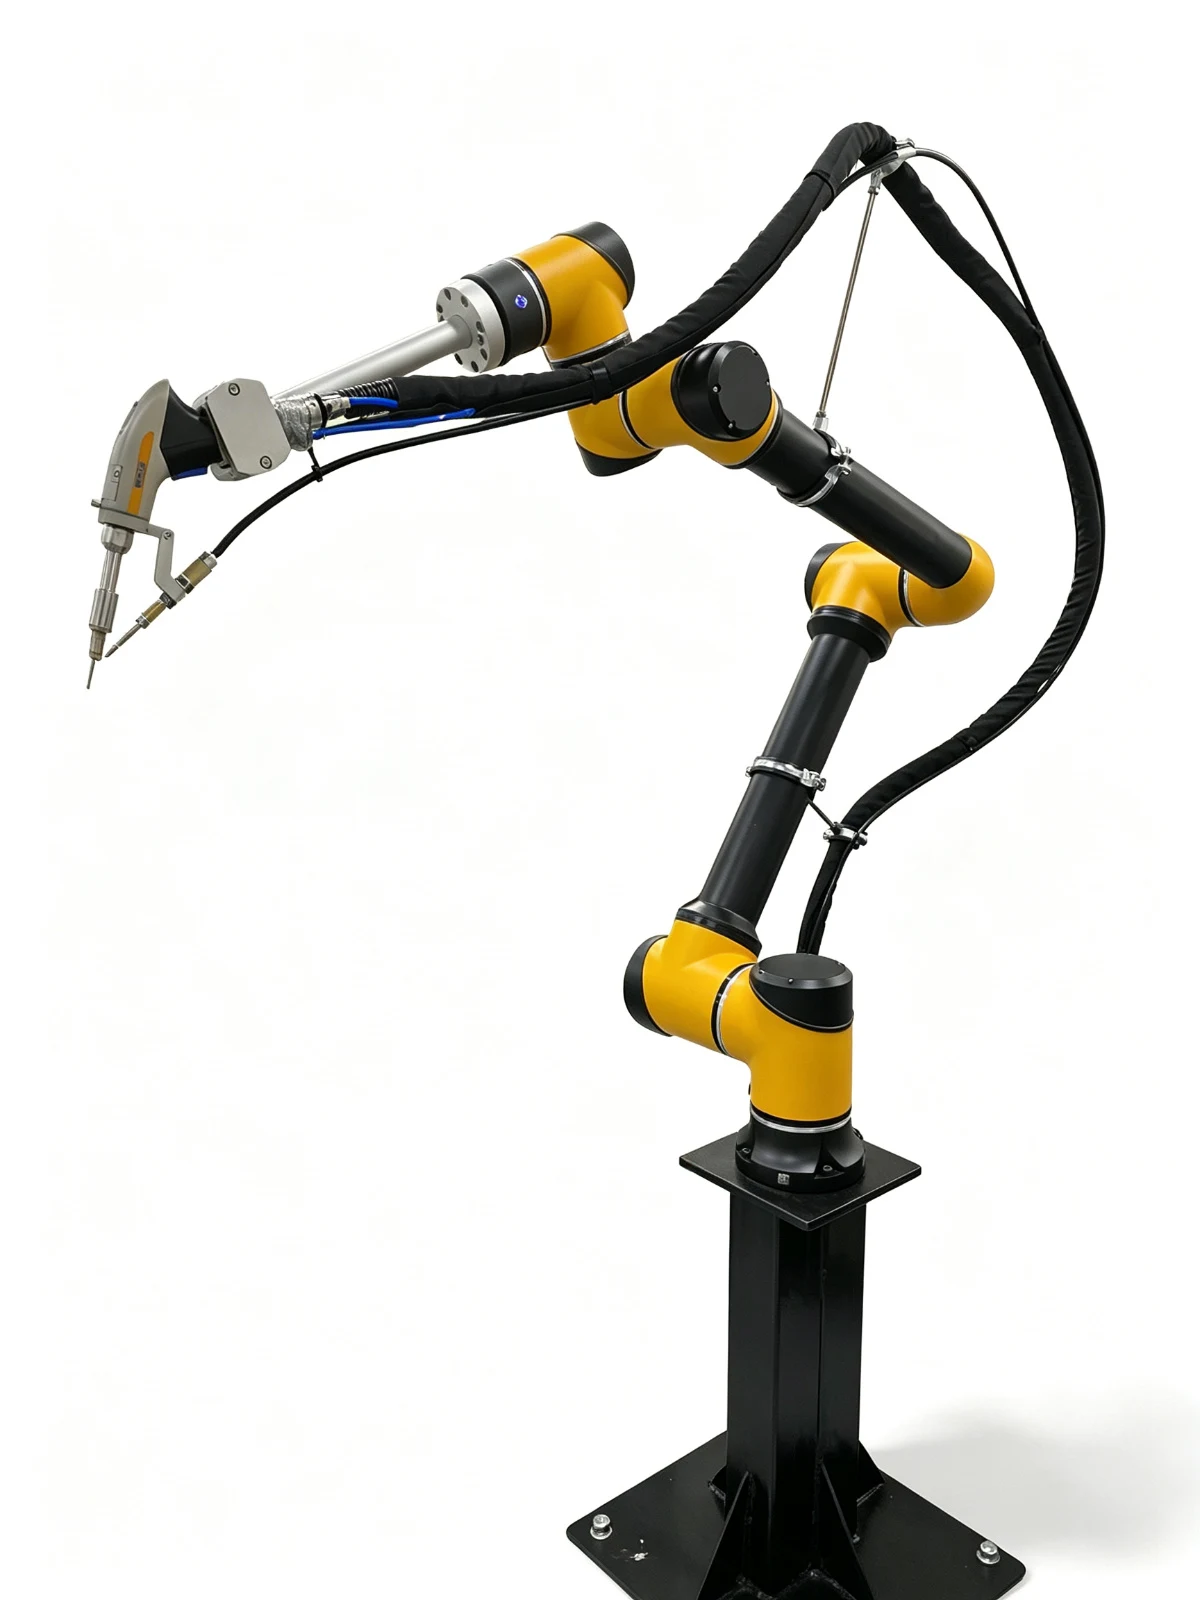
TY-QG5018 Robot Laser Cutting Machine

Six-axis fiber laser cutting for formed and irregular metal components. Program holes, trimmed edges and three-dimensional contours around the workpiece, with robot reach, tooling and laser power selected for each application.

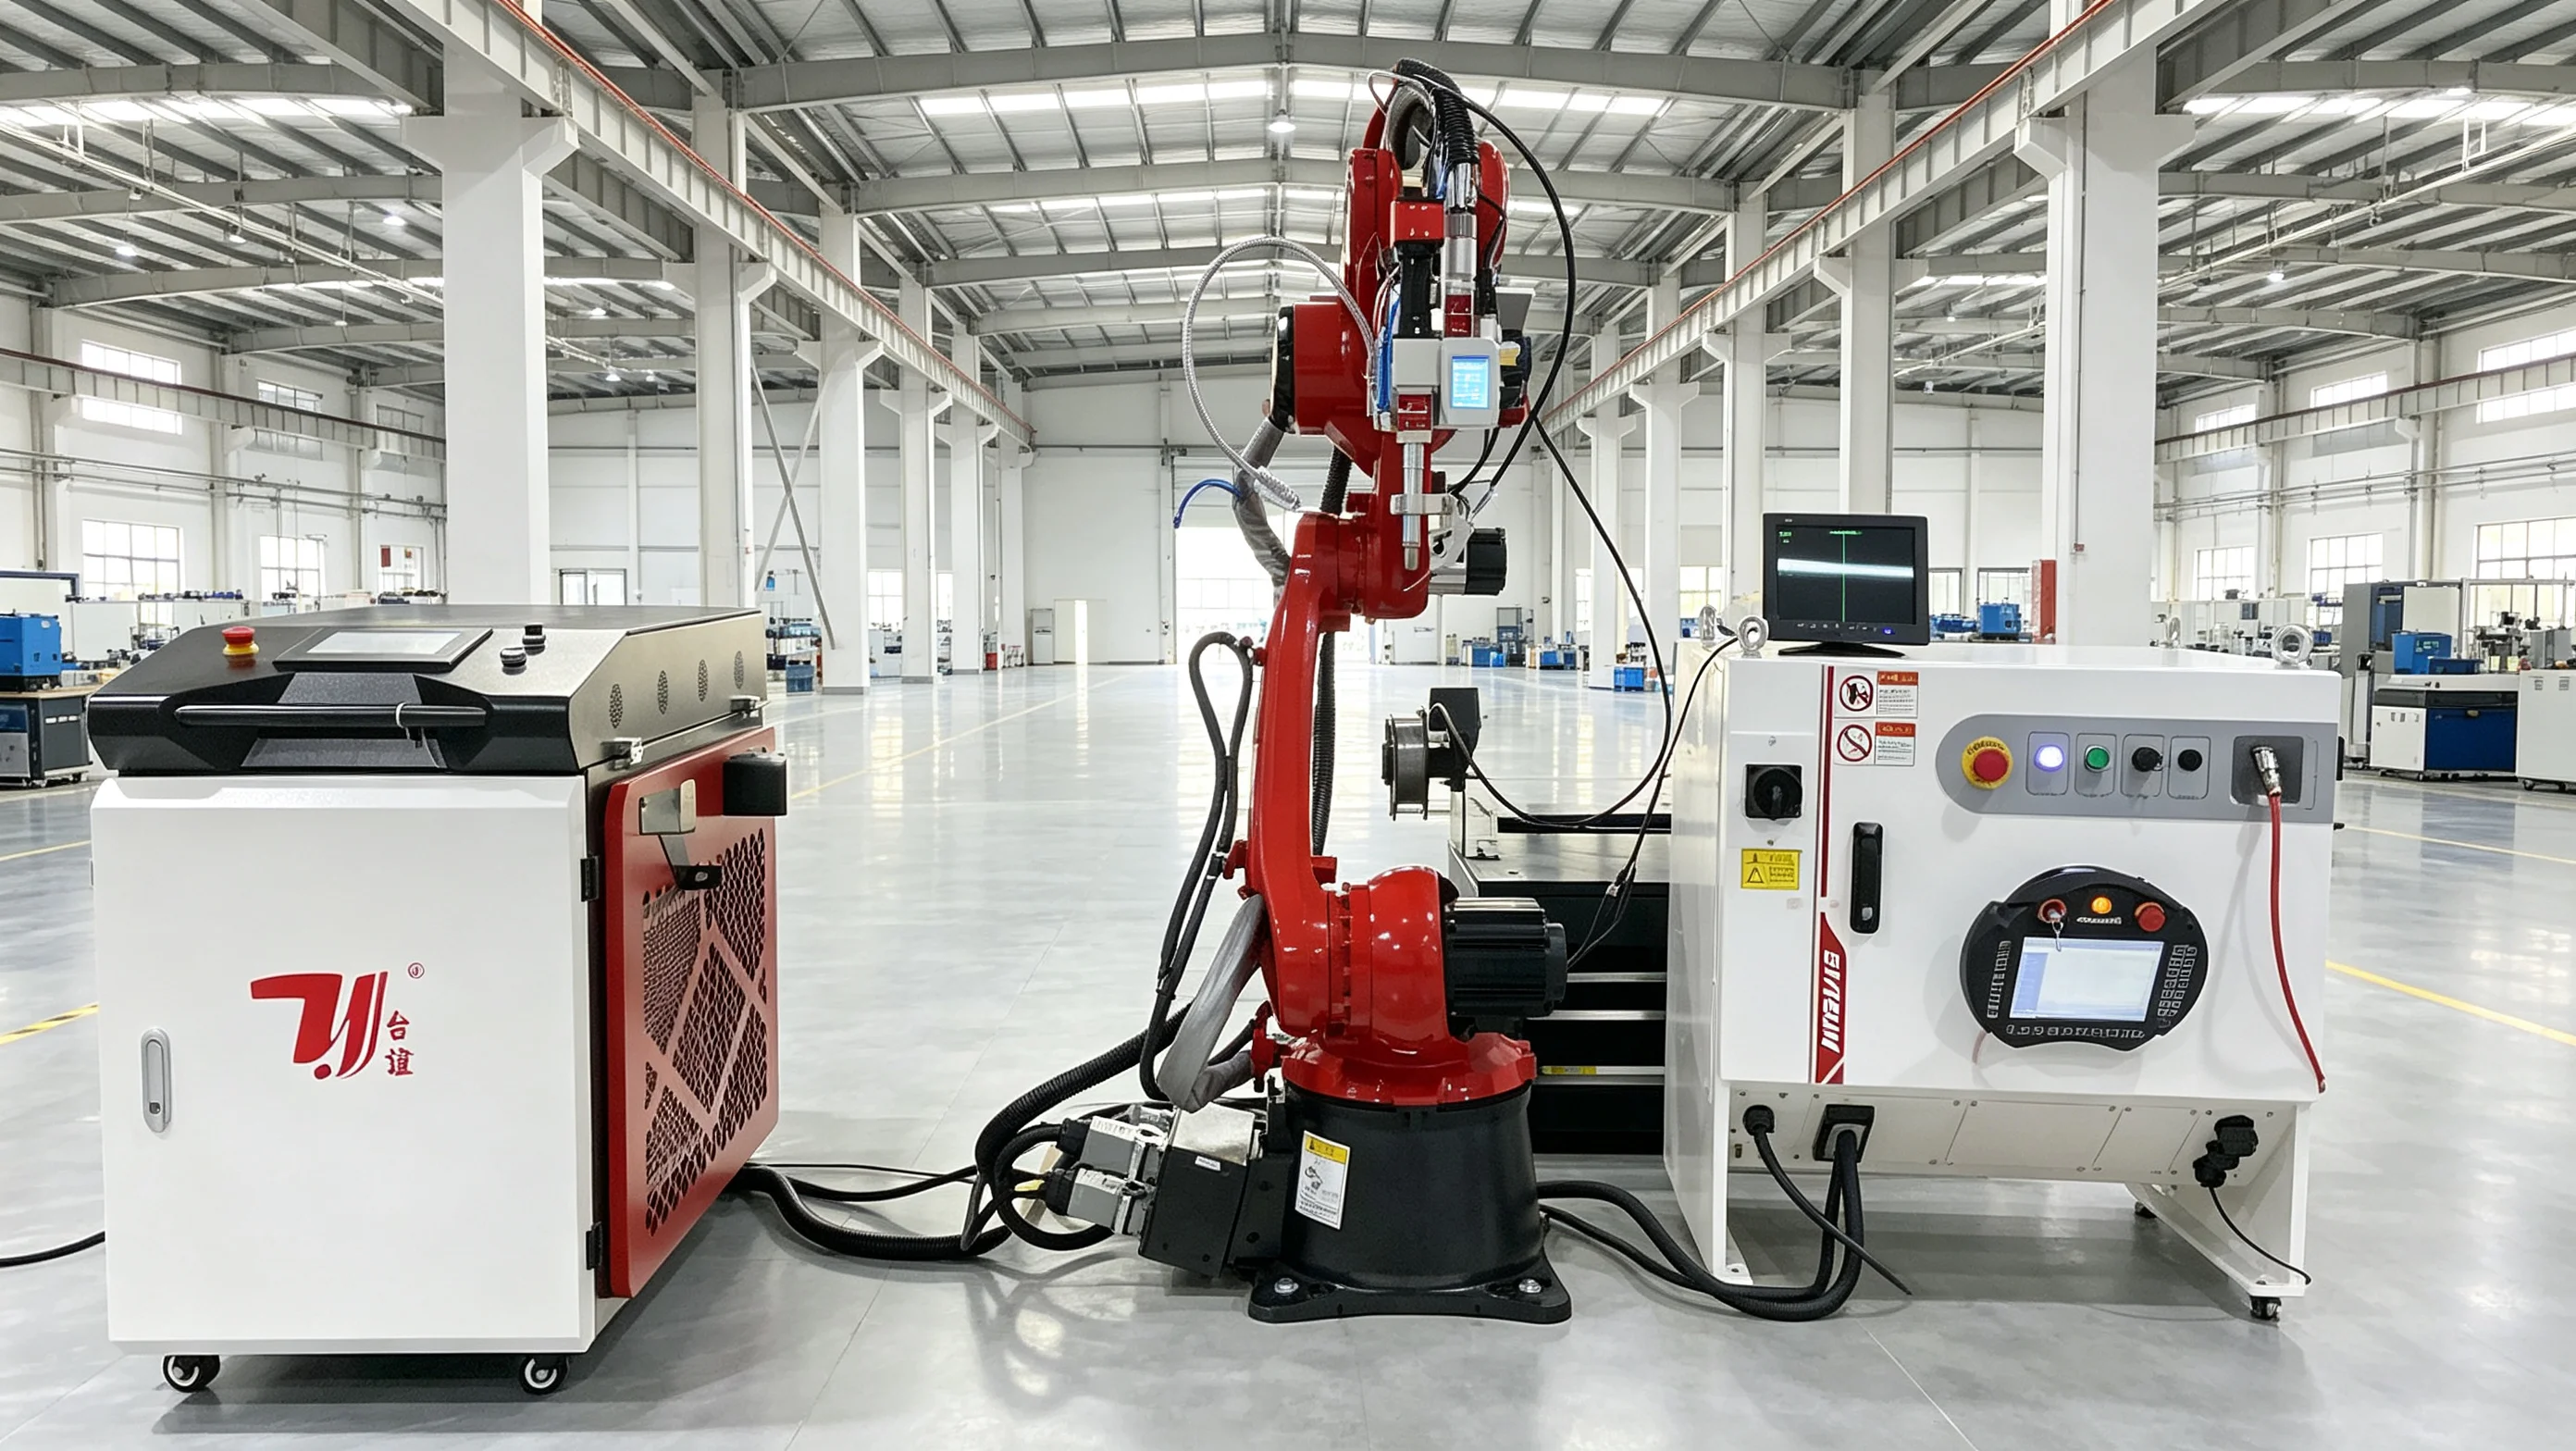
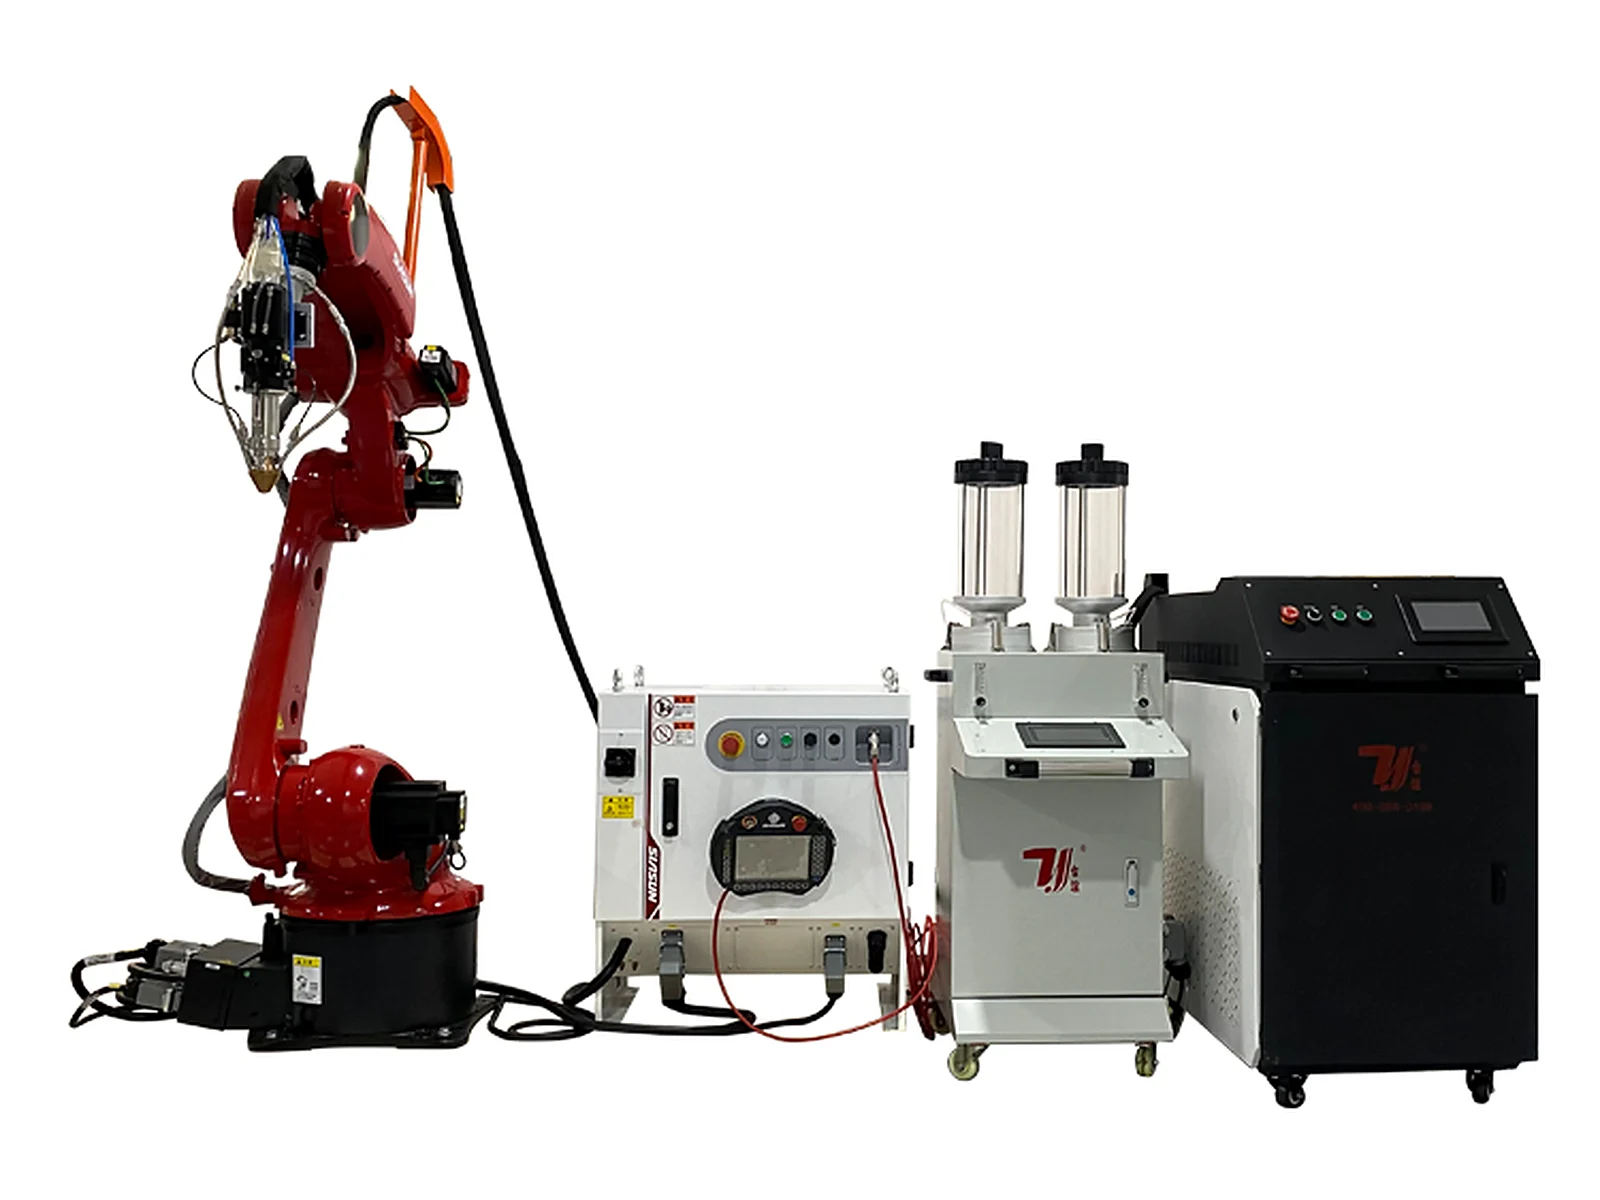
TY-HS5018 Robot Laser Welding Machine

Combine a six-axis industrial robot with a fiber laser welding system for repeatable three-dimensional joints. Configure the welding head, fixtures, wire feed and workpiece access around the material and seam.

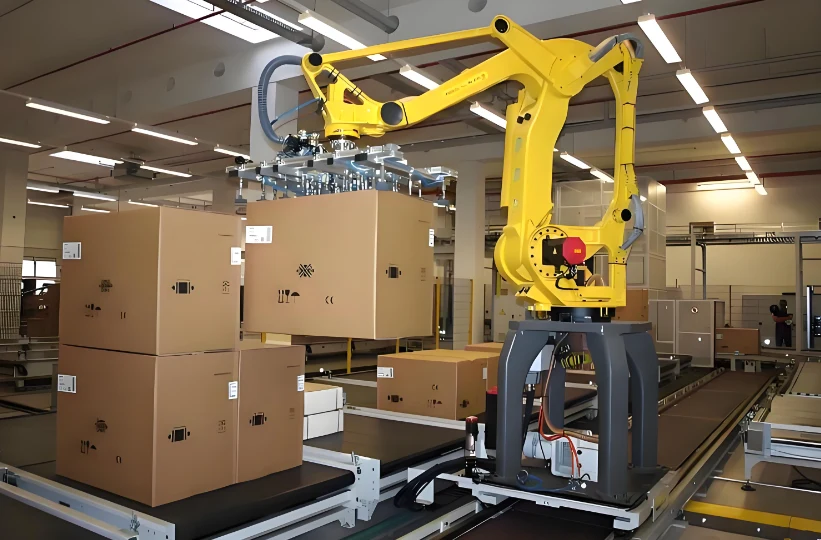
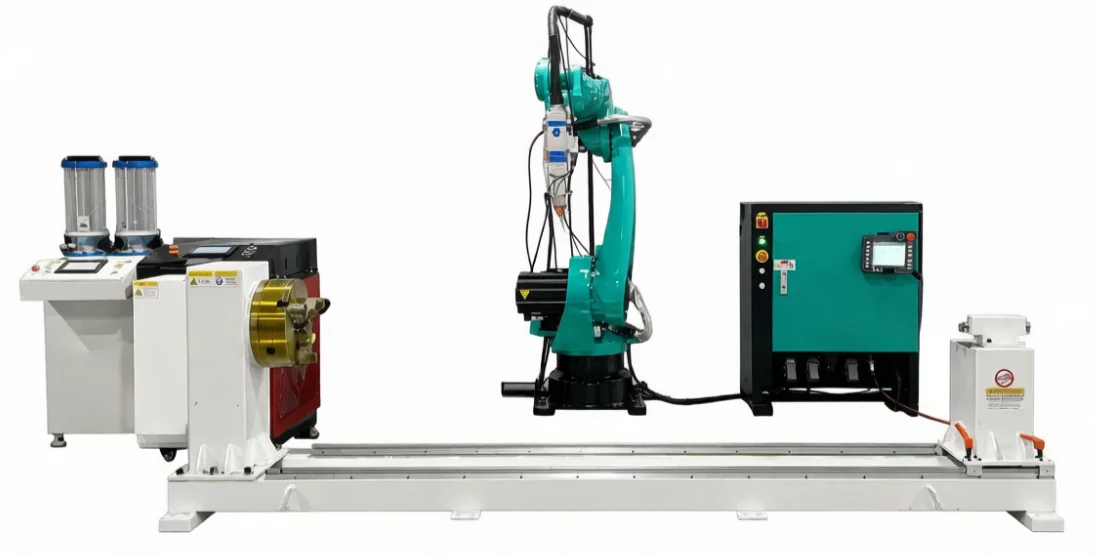
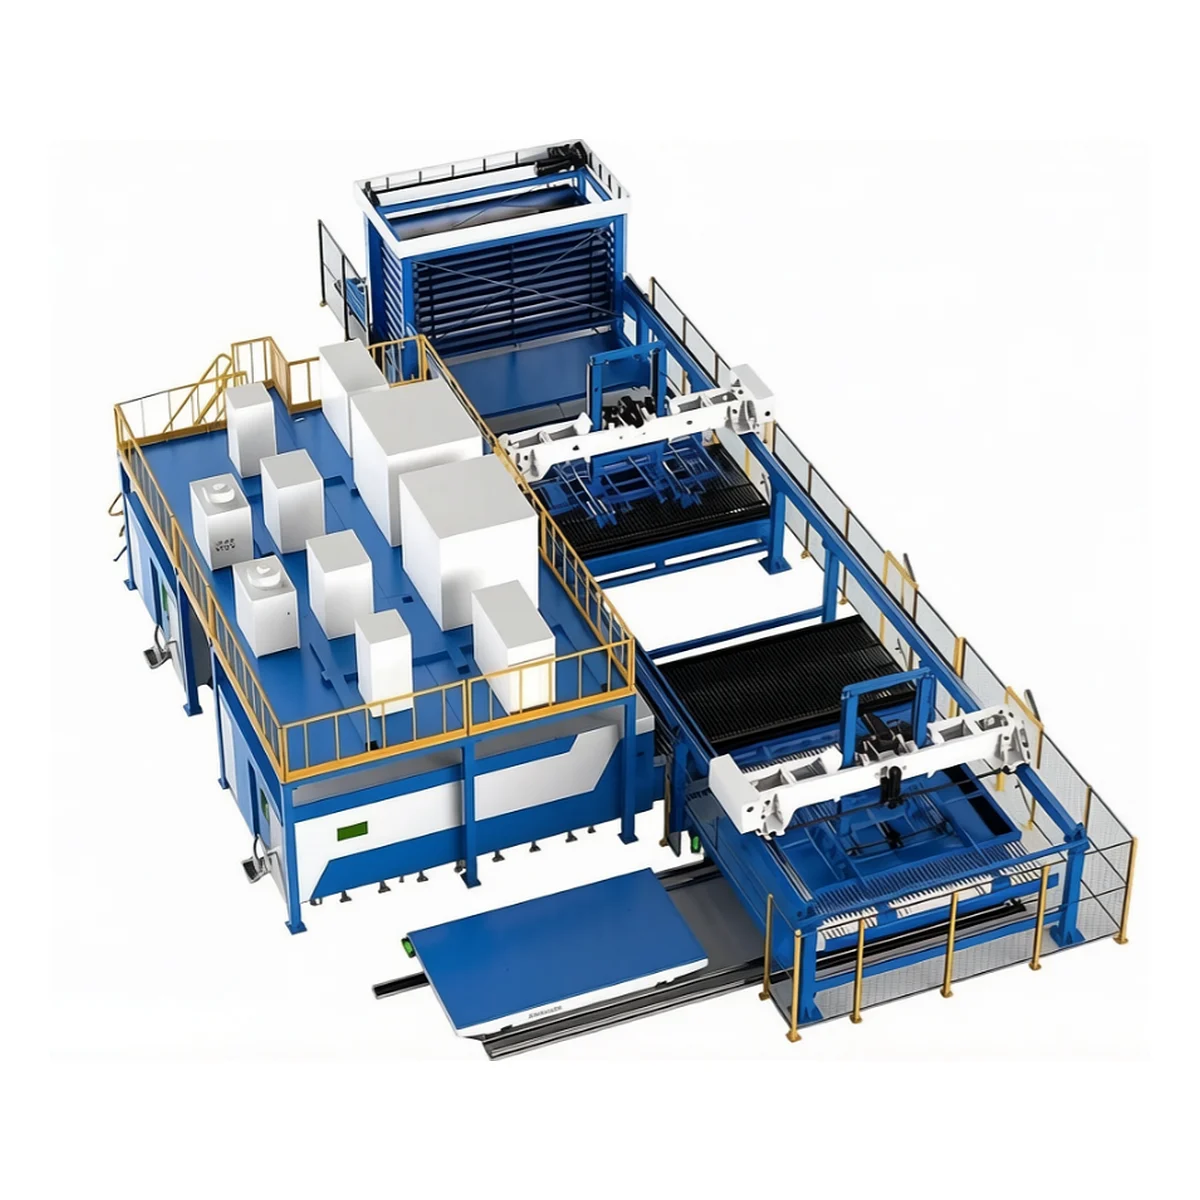
H-AGV Robot Handling System

A fixed-base or rail-mounted industrial robot handling system for transferring parts and loads between defined stations. Select the gripper, robot reach, rail arrangement and connected equipment around the load and workflow.

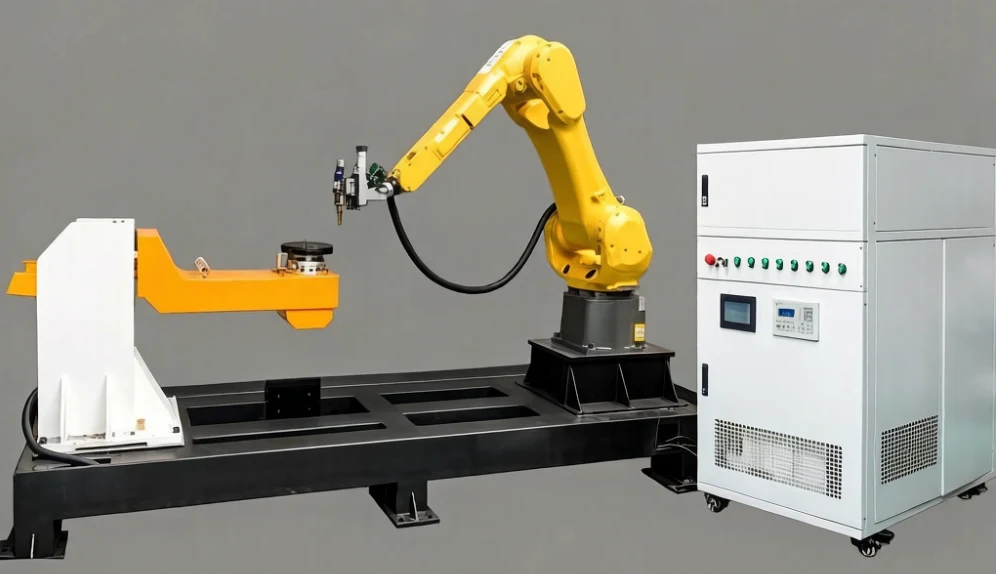
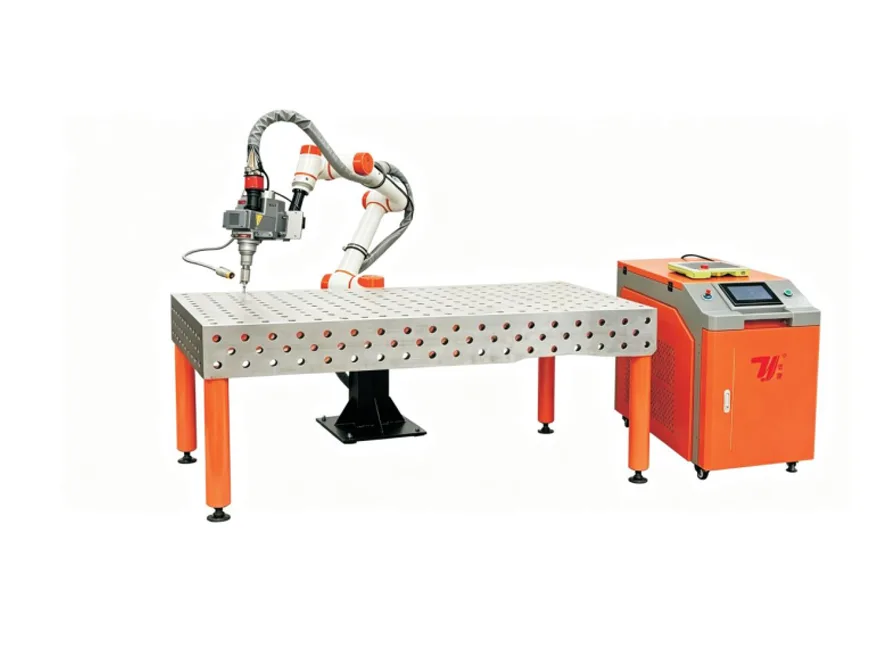
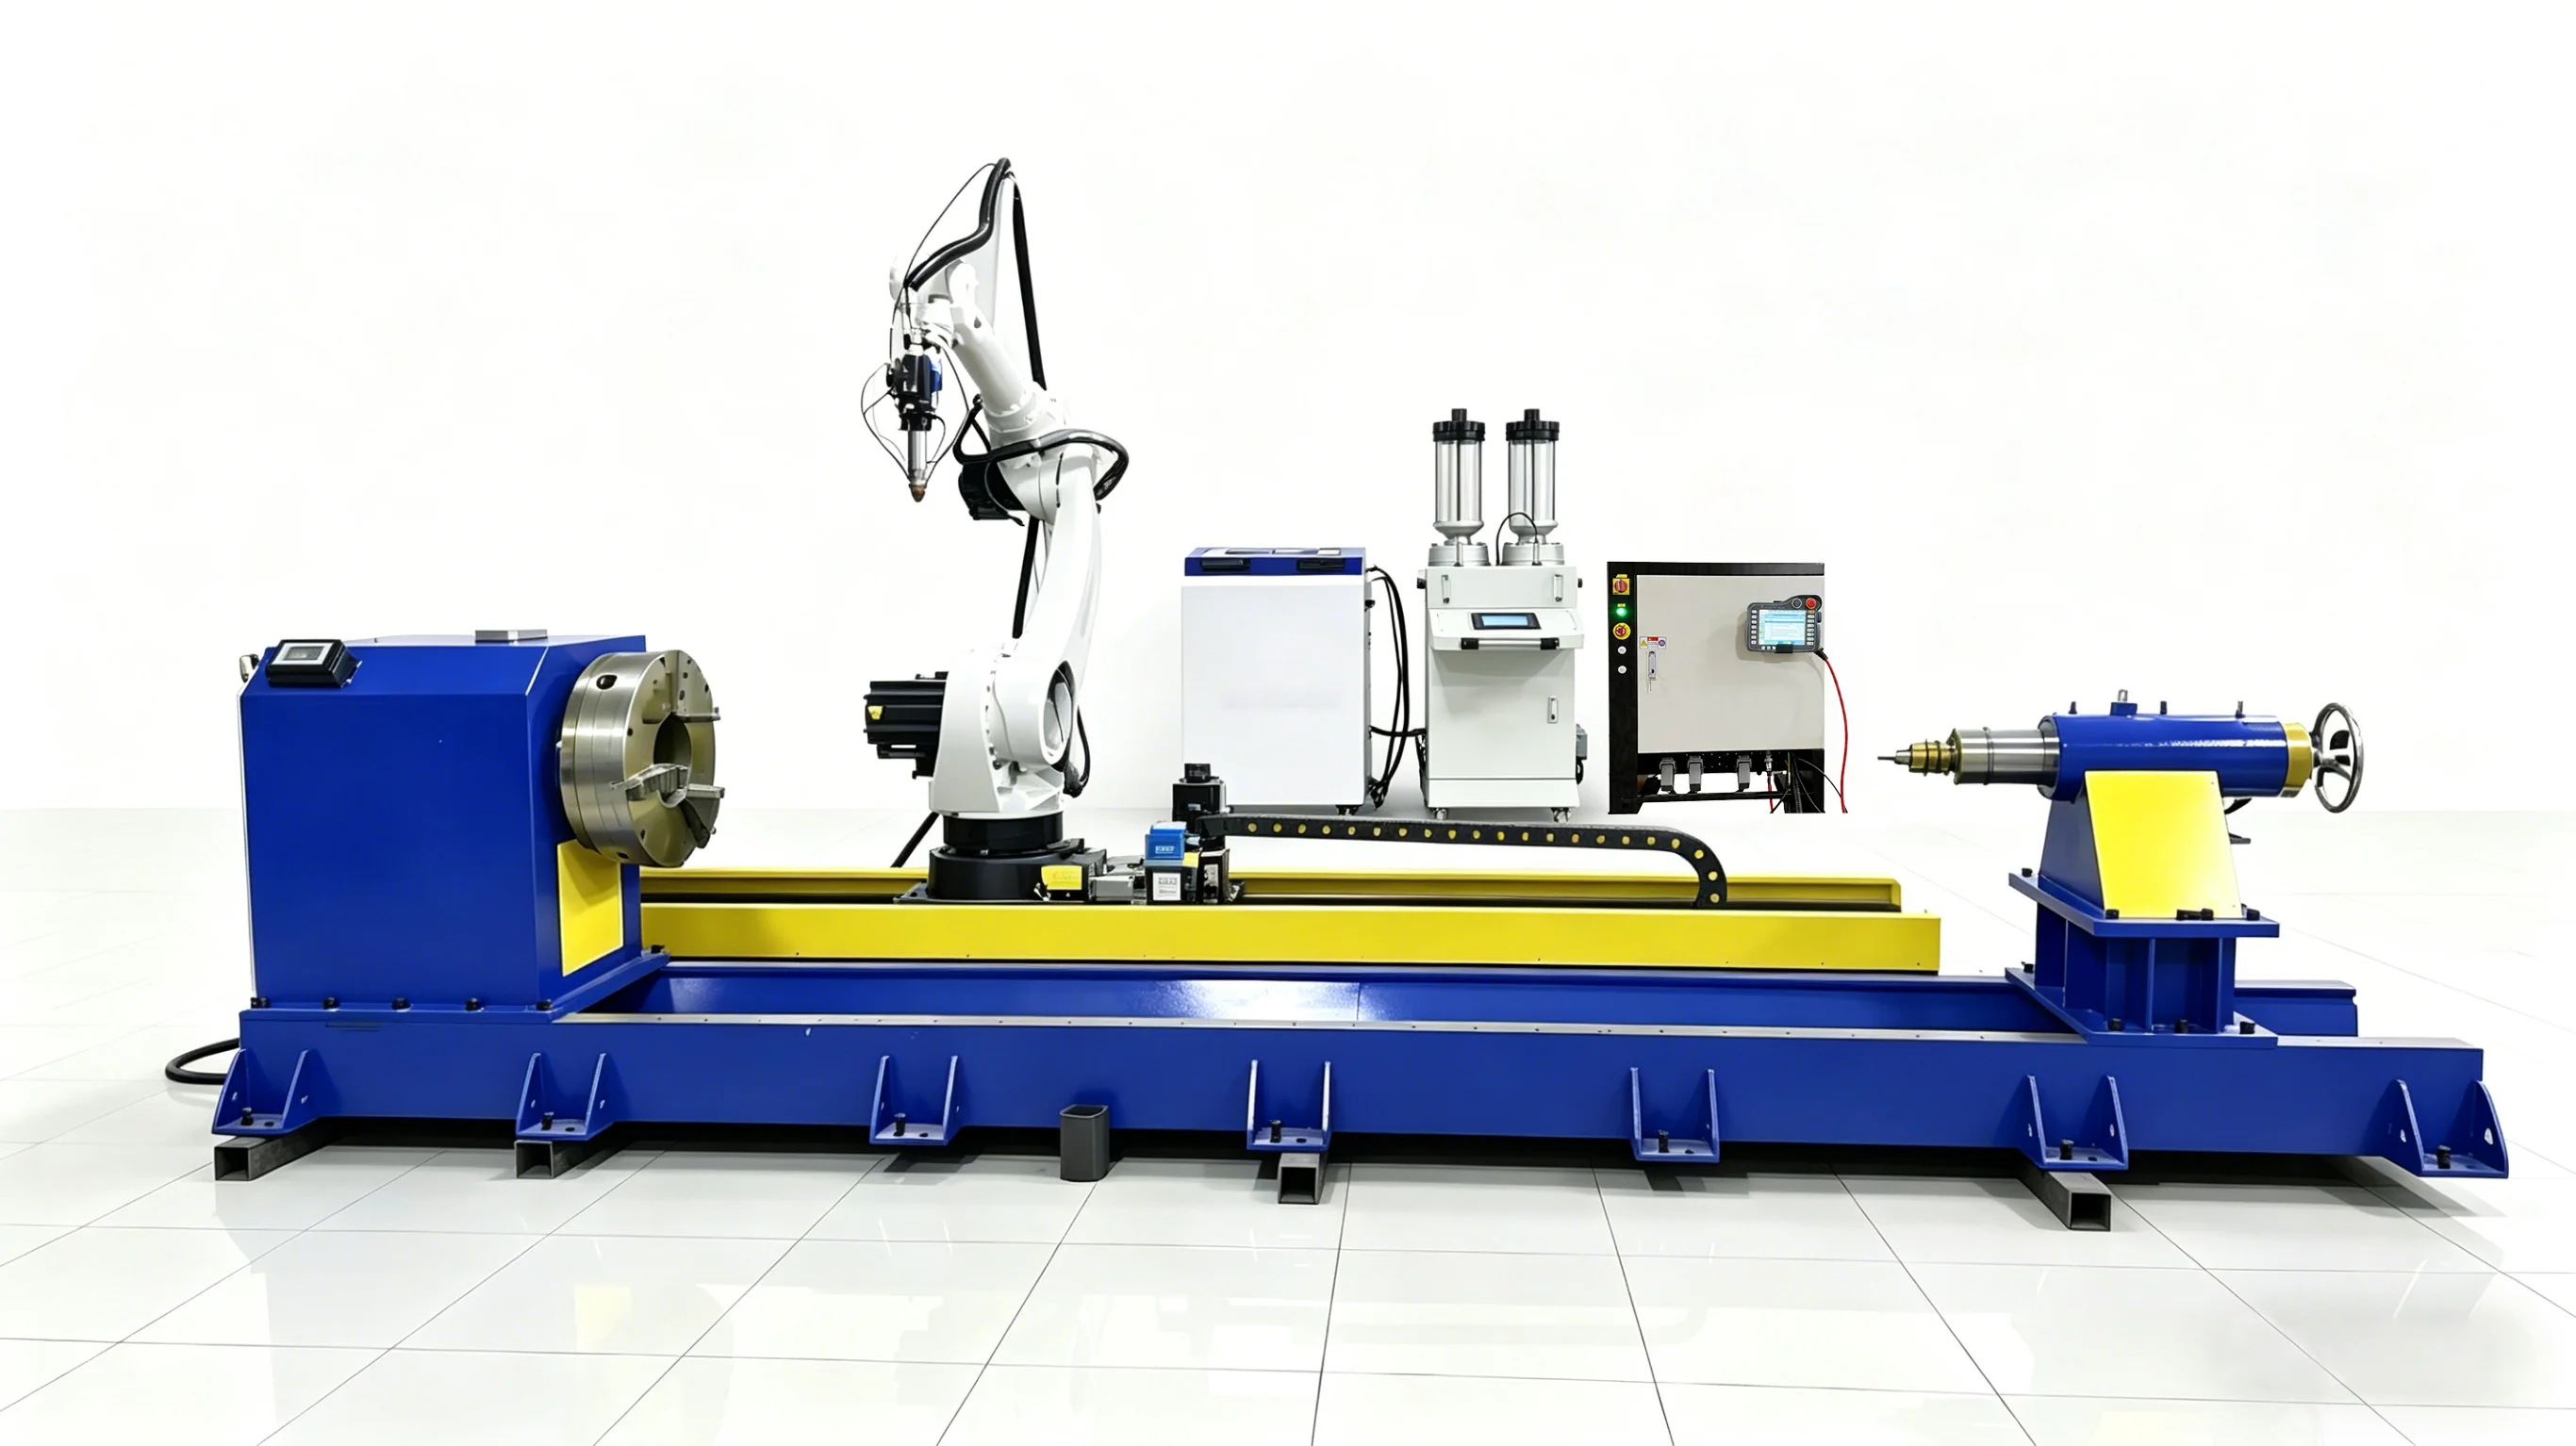
TY-QG5020 Robot Laser Cutting Machine with Positioner

Pair a six-axis laser-cutting robot with a rotary workpiece positioner for multi-sided metal parts. Coordinated reorientation brings additional surfaces into reach and supports cutting, trimming and hole-making around formed components.

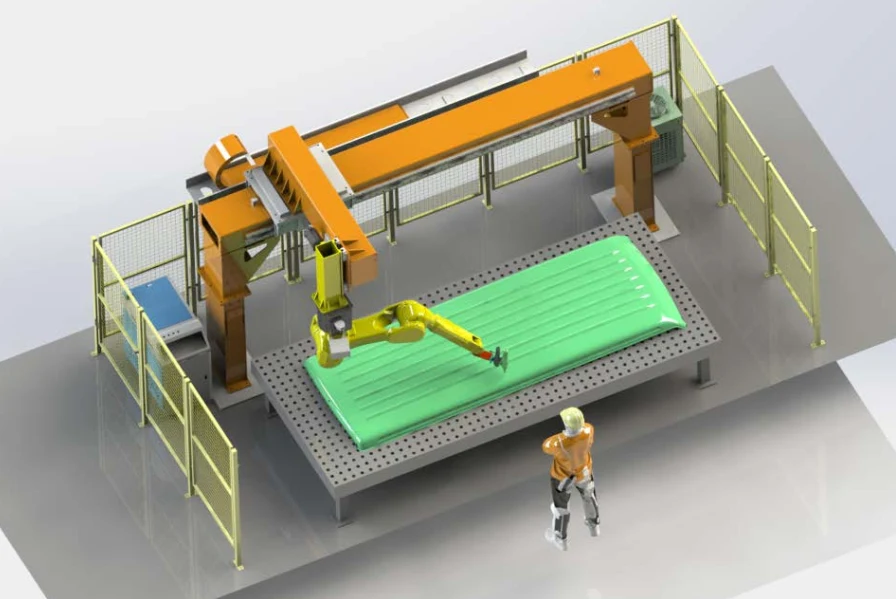
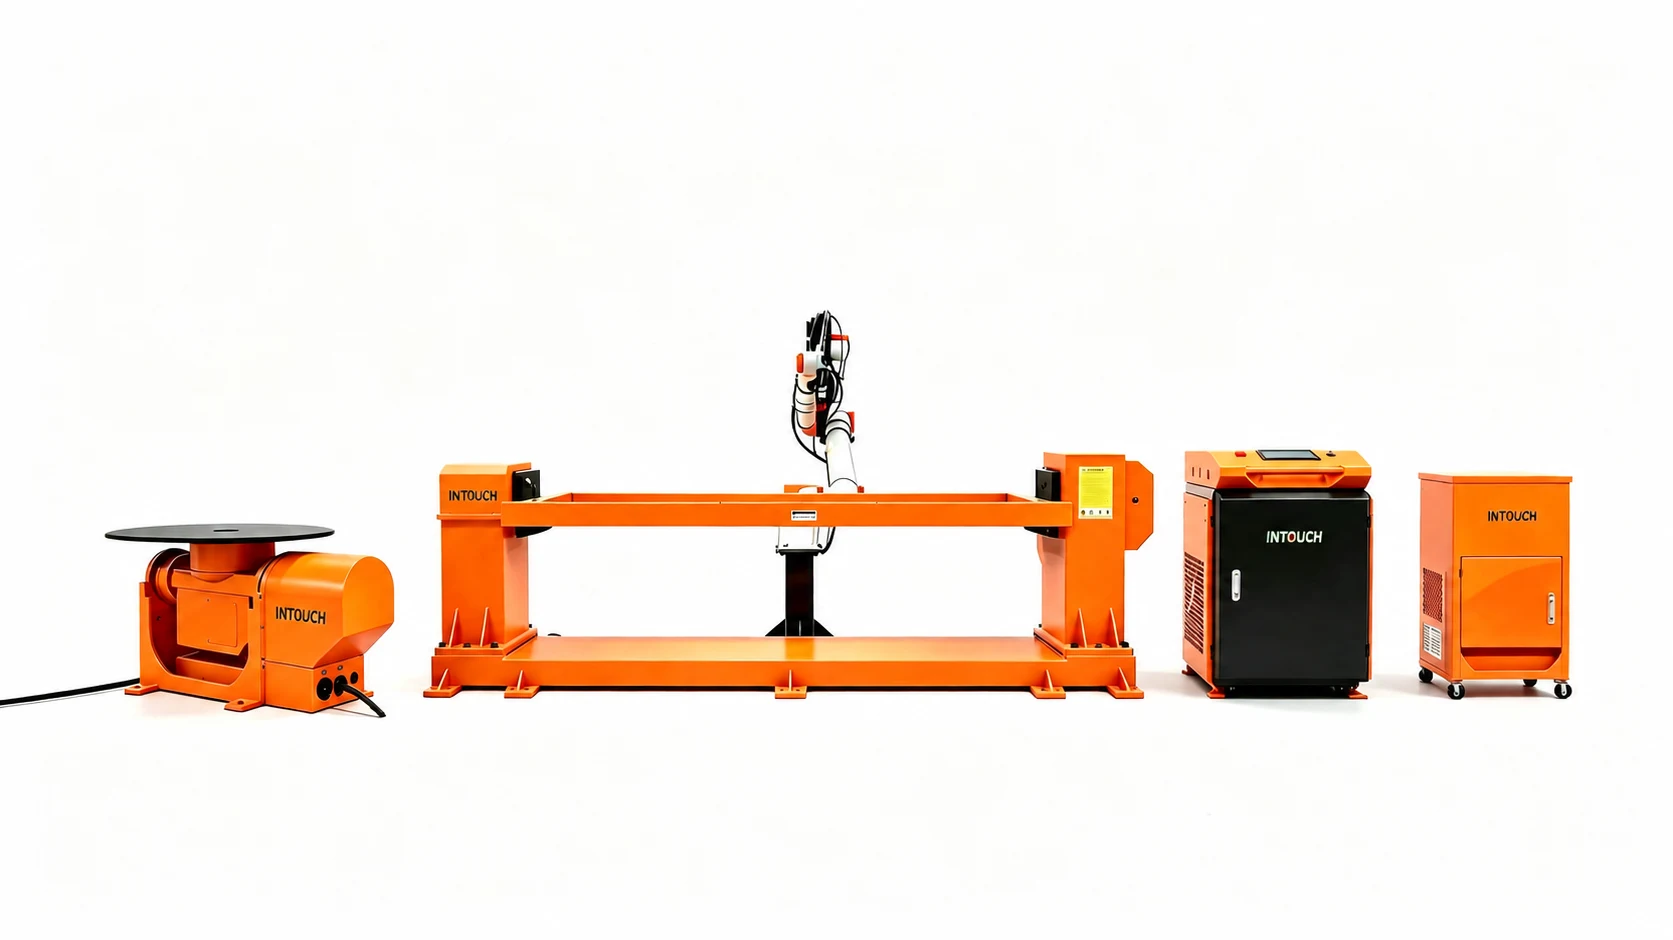
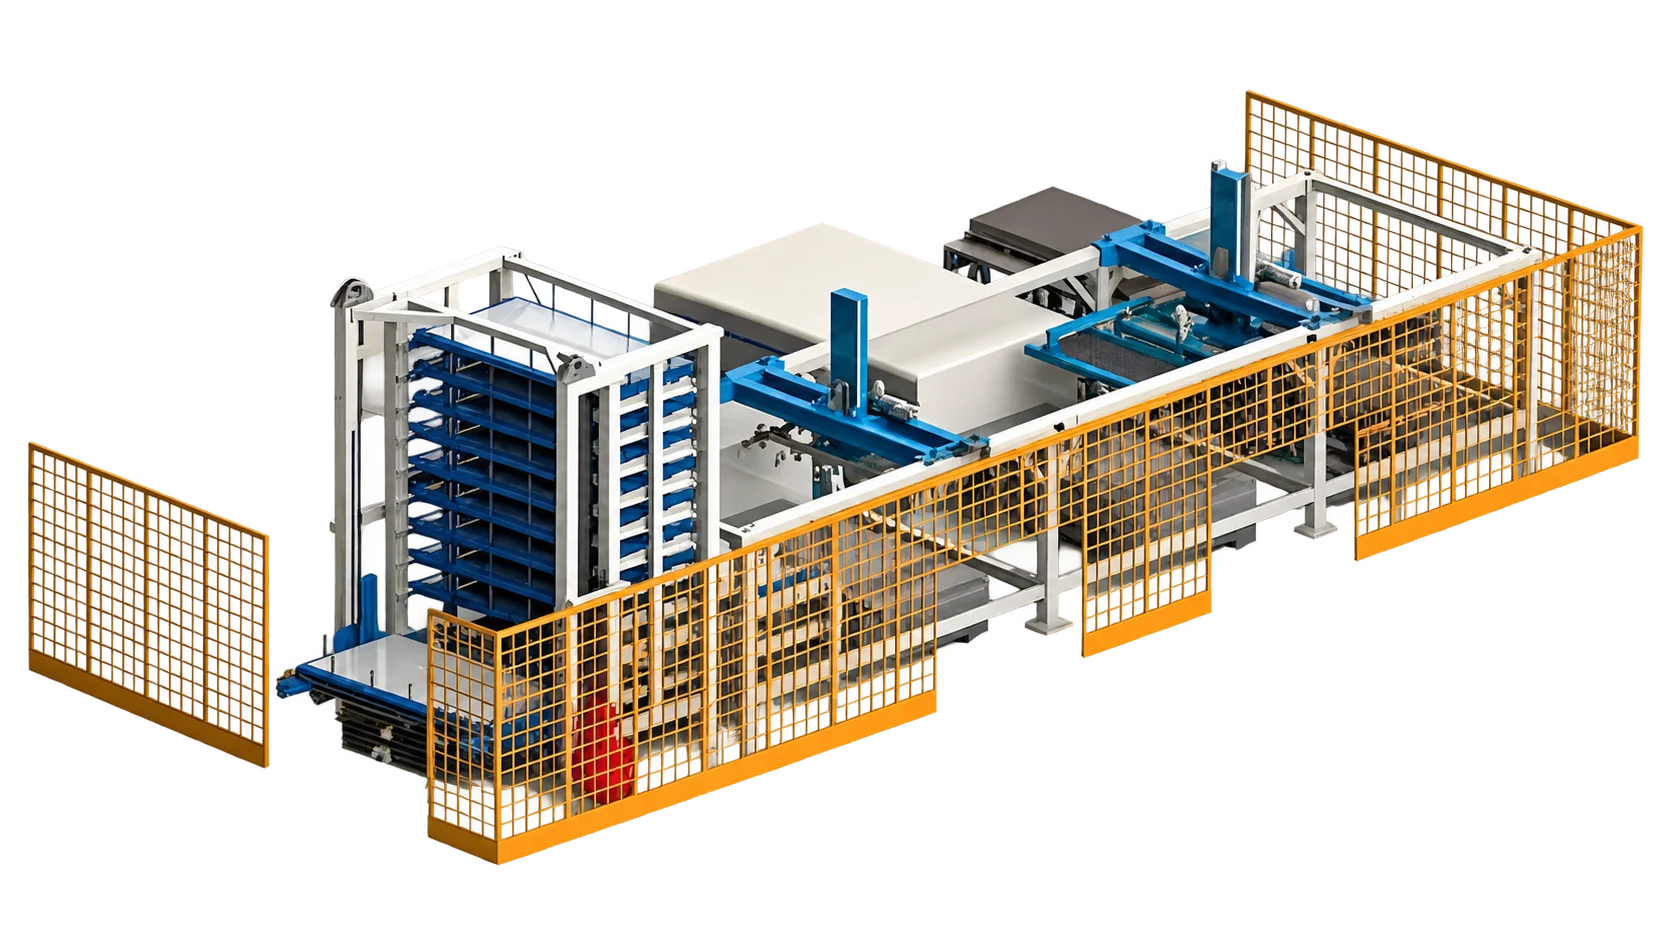
TY-QG5022 Gantry-Rail Robot Laser Cutting Machine

A gantry-mounted travelling robot laser-cutting configuration for large formed parts and extended work envelopes. The overhead rail arrangement moves the robot across the work area while fixtures locate the component below.

Prepare your selection brief

  • Specify whether the robot will cut, weld or handle the workpiece.
  • Provide workpiece dimensions, mass and the required tool or gripper arrangement.
  • Describe the surrounding machines, transfer sequence and available cell space.

Robot configuration questions

How should I compare the systems?

Start with the required process, material, geometry and loading workflow. Then compare the complete robot, tooling, fixture and connected equipment.

What is needed for a project quote?

Provide part drawings, dimensions, material, production targets, loading method and available floor space. Identify interfaces to existing equipment.

Are robot repeatability and finished-part tolerance the same?

No. Robot repeatability describes the robot motion. The resulting cut, weld or placement also depends on tooling, fixtures, workpiece variation and process settings.

Is H-AGV a mobile AGV or AMR vehicle?

This H-AGV offering is a fixed-base or rail-mounted handling robot. Its configuration is defined by the robot, end effector, station spacing and connected equipment.

Request a quote

Tell us the part. We will tell you the machine.

Share your part drawing, material and production requirements. The quotation will identify the selected equipment, tooling, handling options and integration scope for your project.